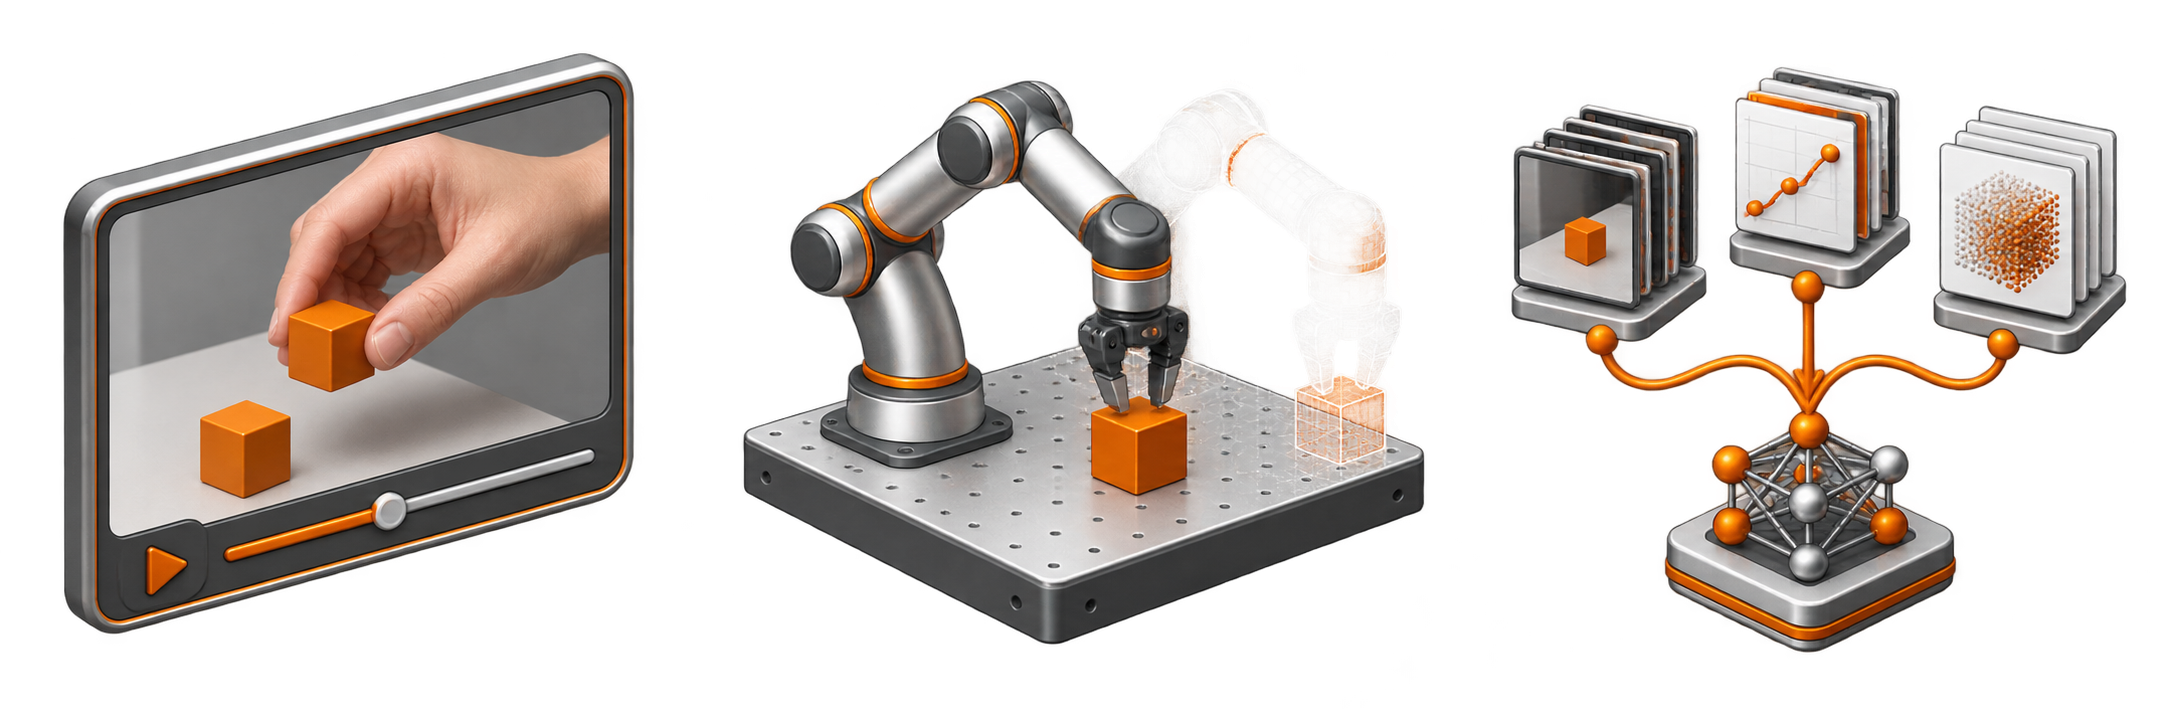
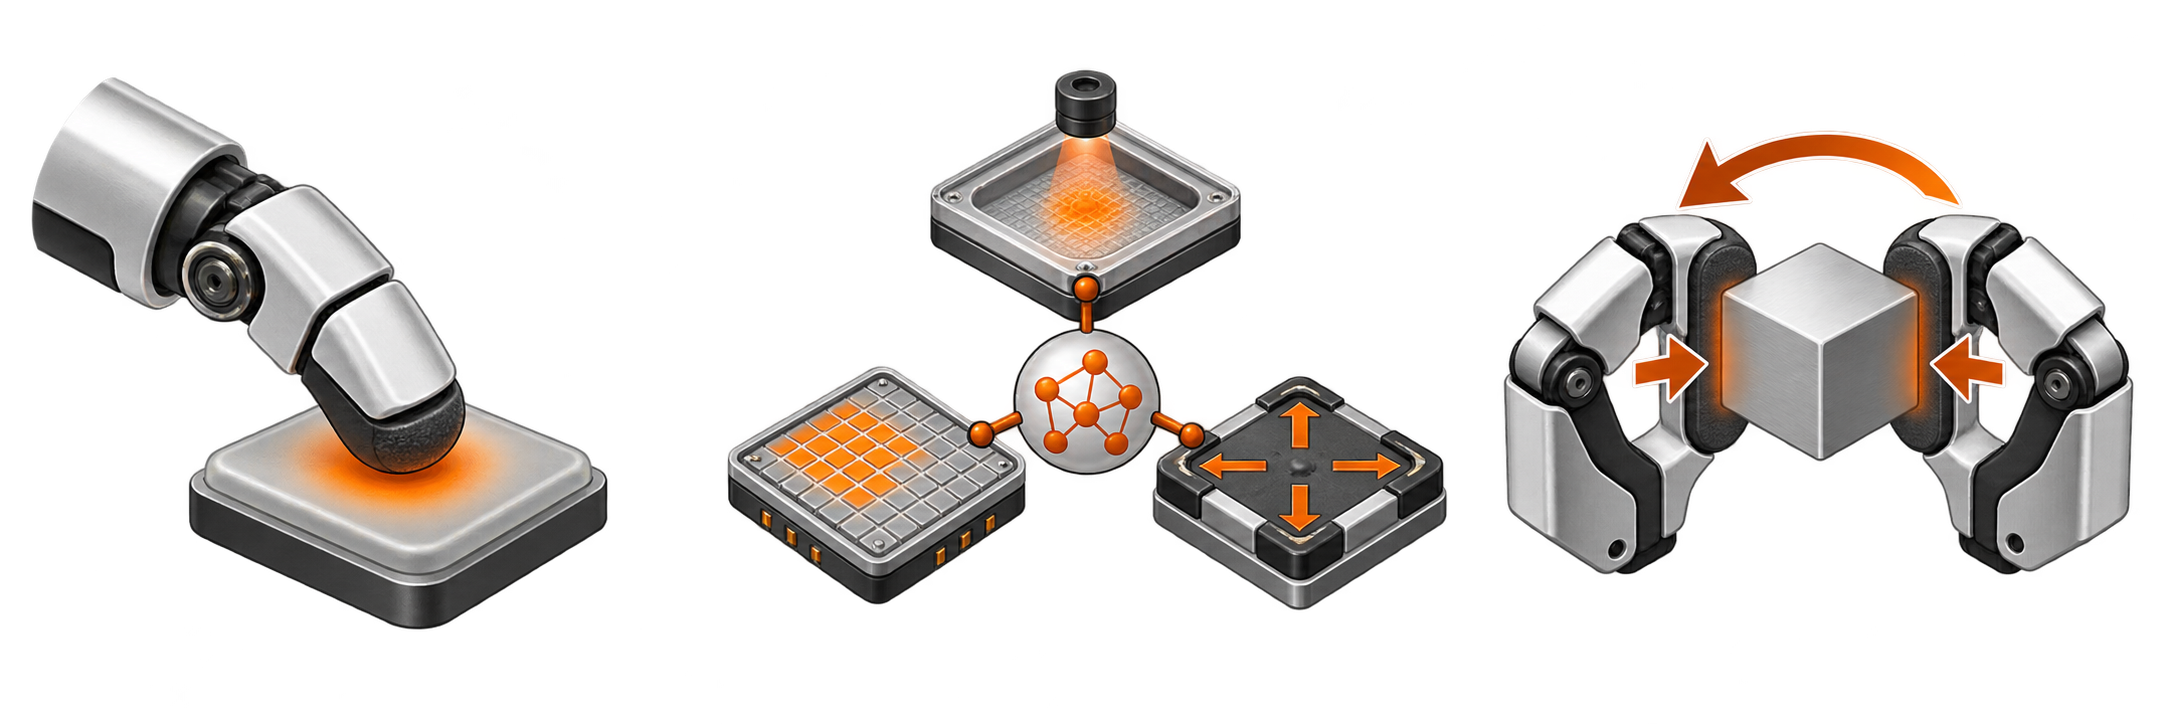
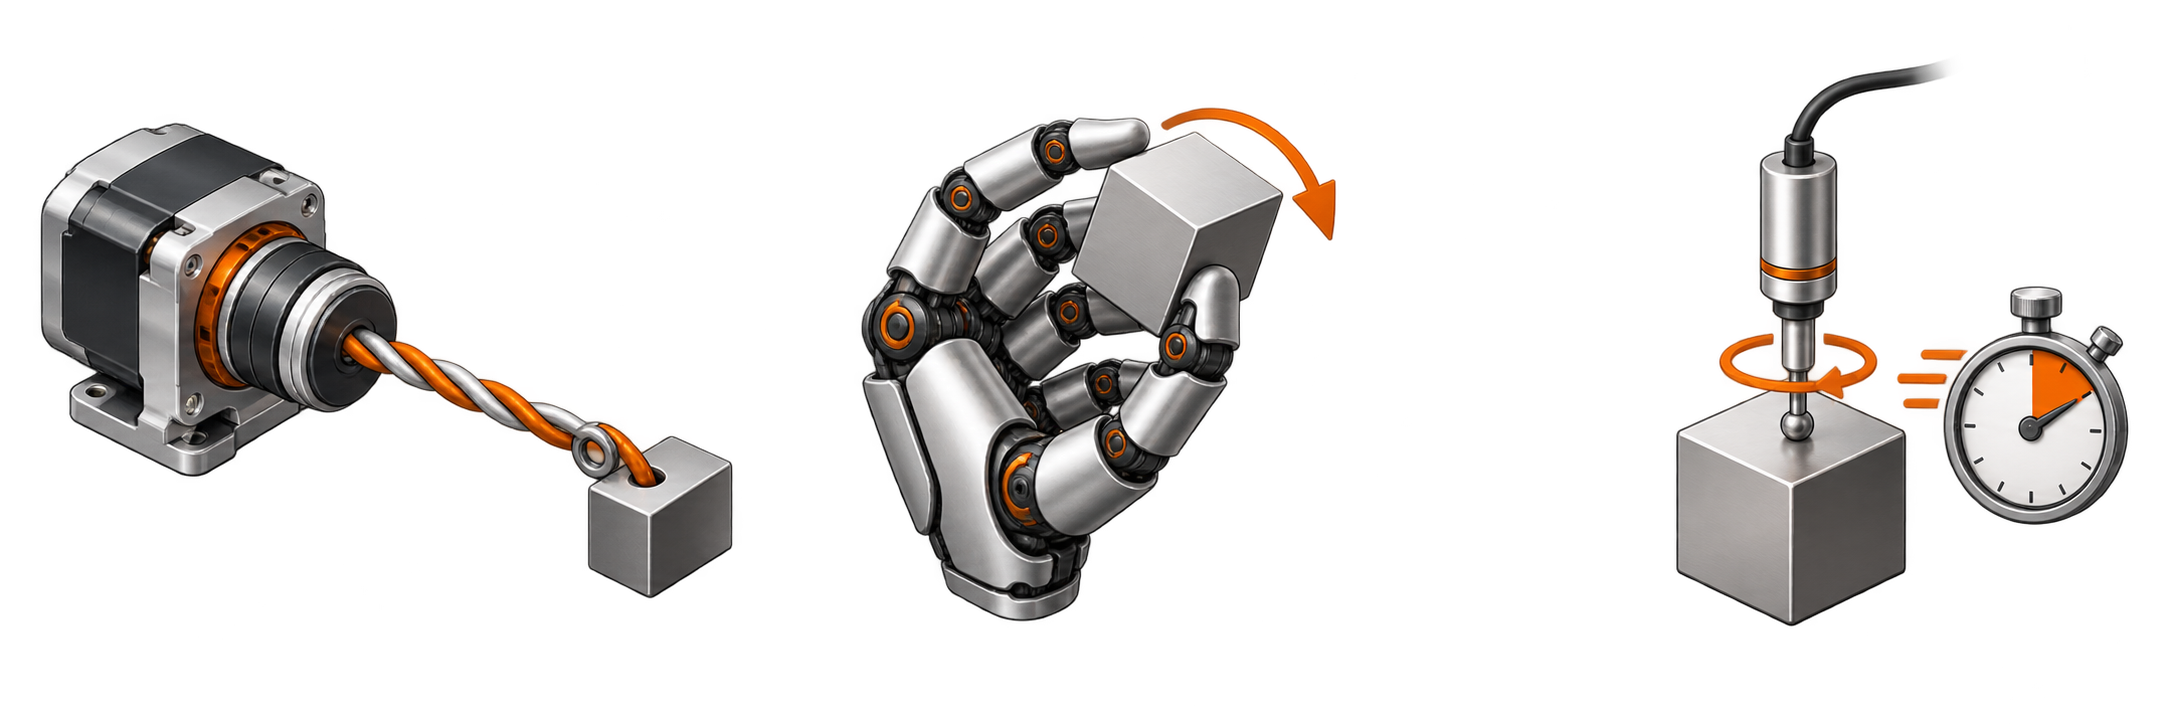
We study robot manipulation through data-efficient learning, tactile interaction control, and actuation design. Our emerging program connects simulation and physical experiments to develop robots that learn efficiently and interact reliably.
Digital twins and mixed real and simulated data support efficient adaptation to new tasks.
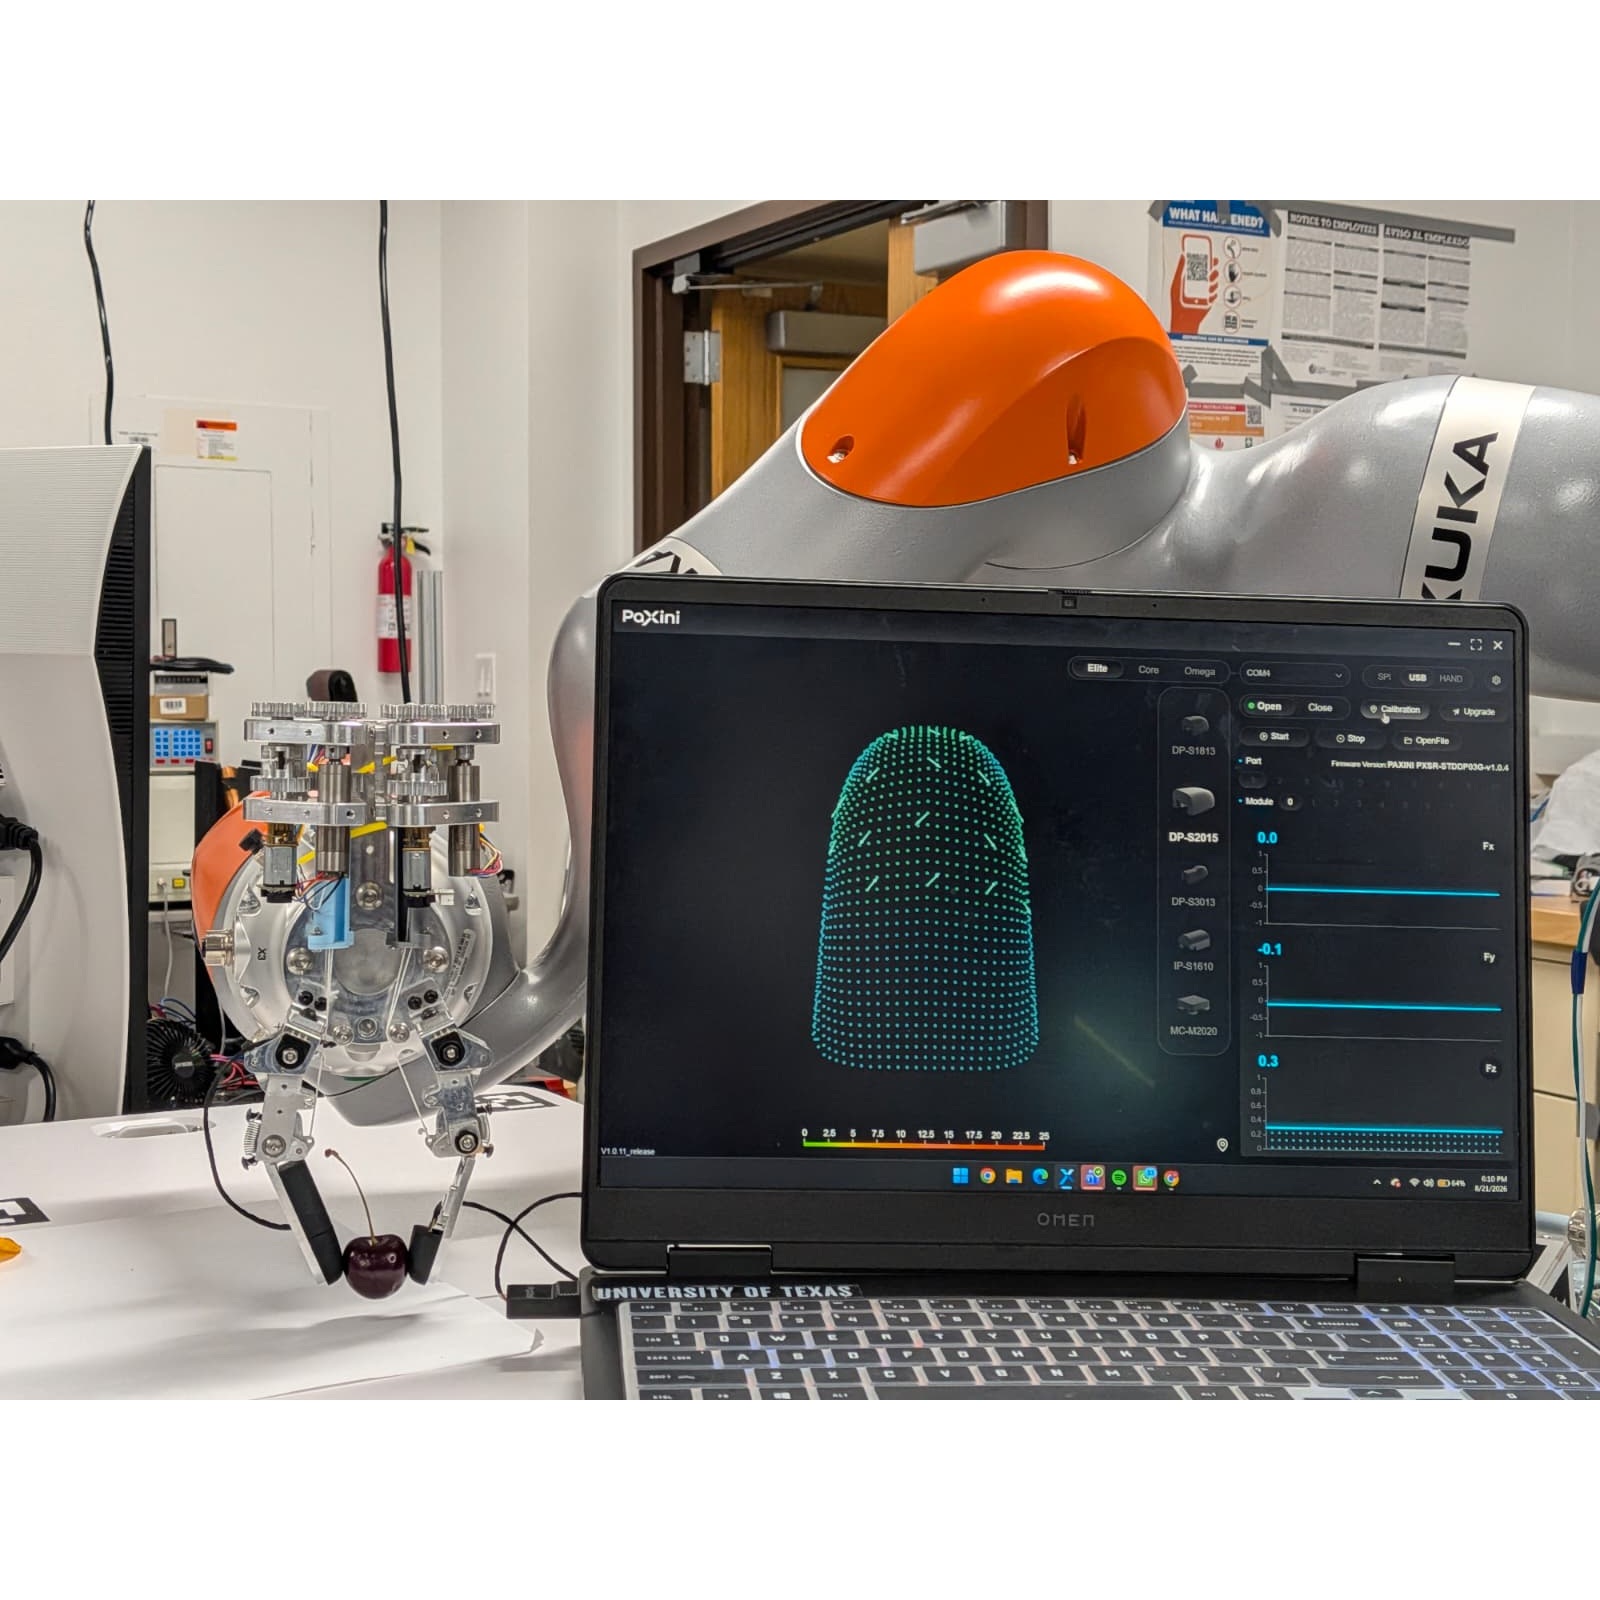
Tactile sensing and force feedback guide stable contact during robotic manipulation.
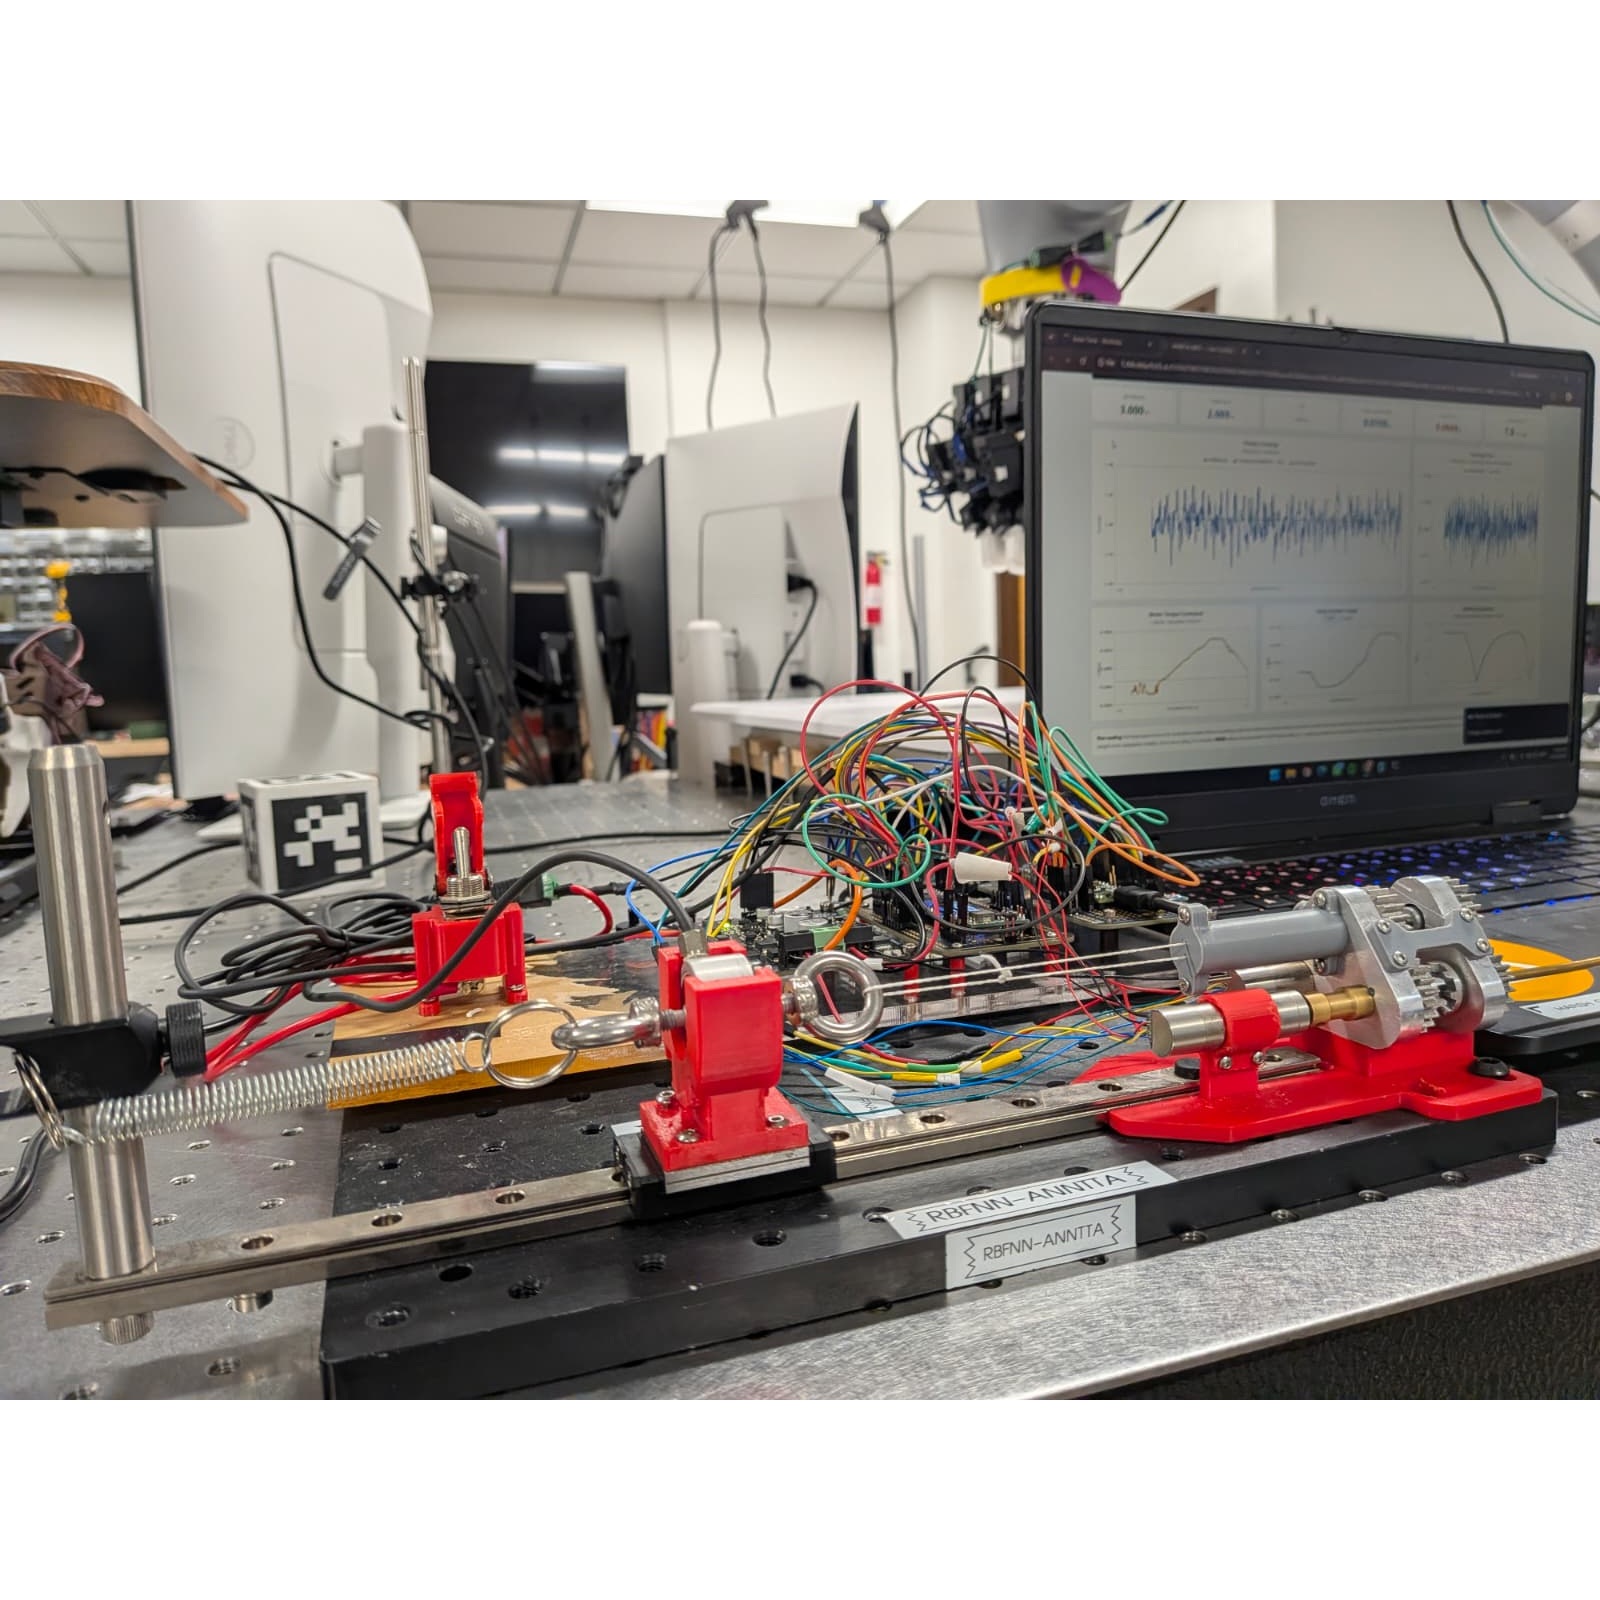
Actuator design and dynamics studies support controlled motion during robotic manipulation.
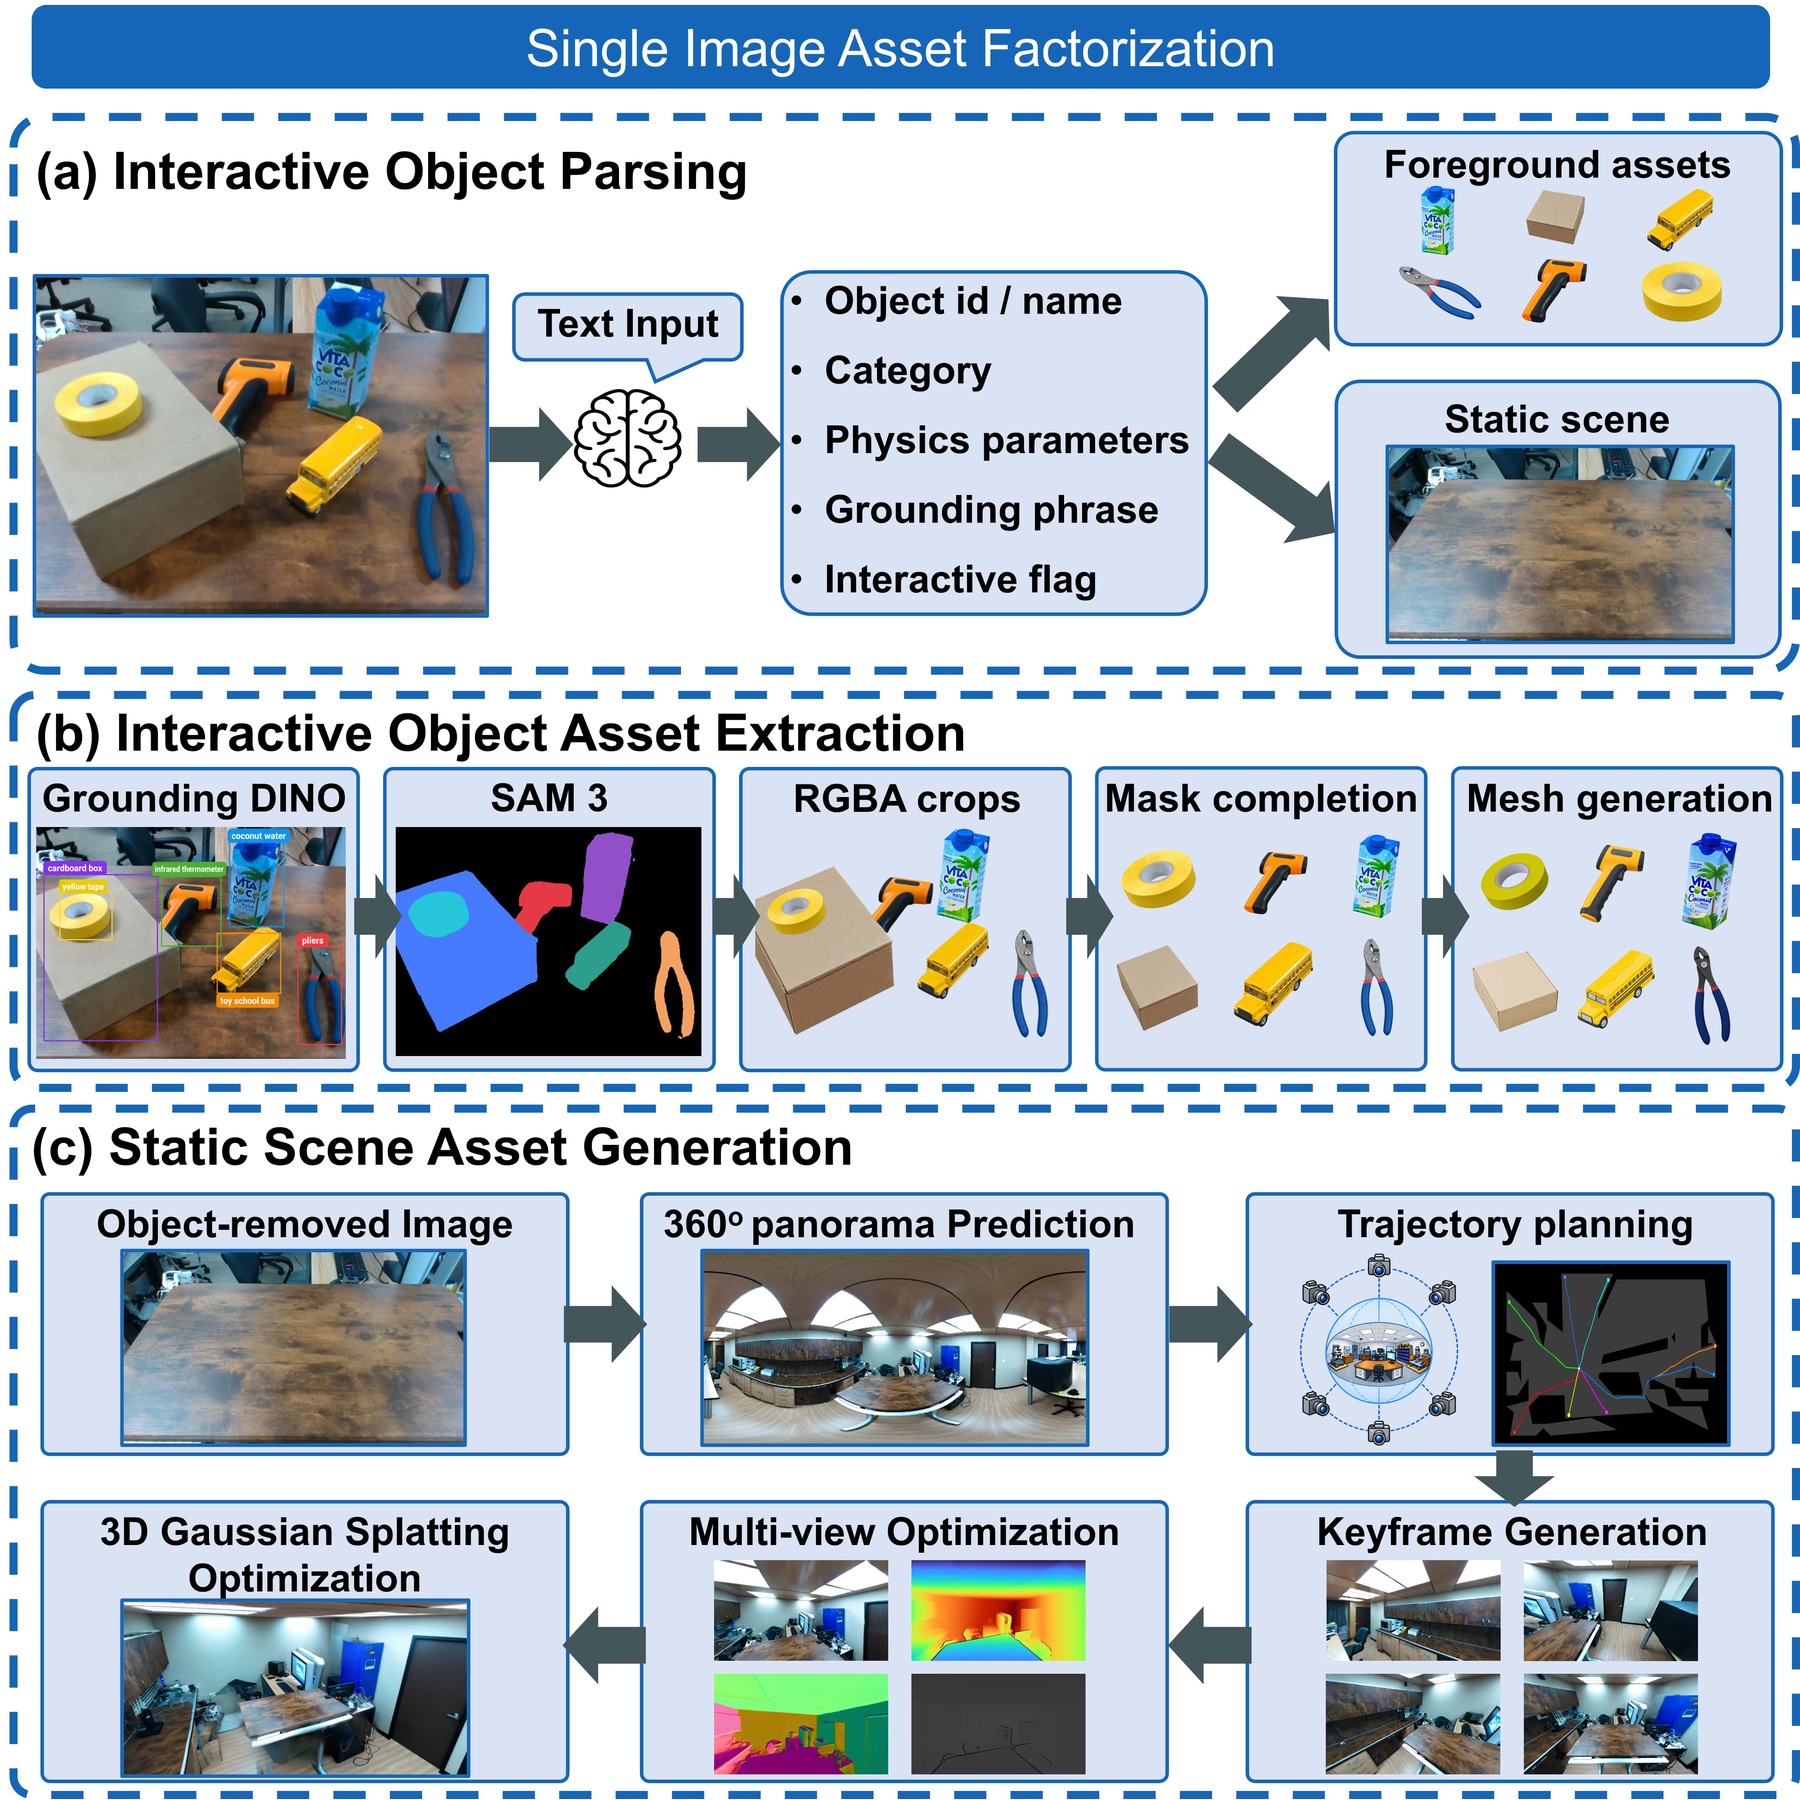
Objects are parsed from a single scene image and reconstructed alongside the static scene.
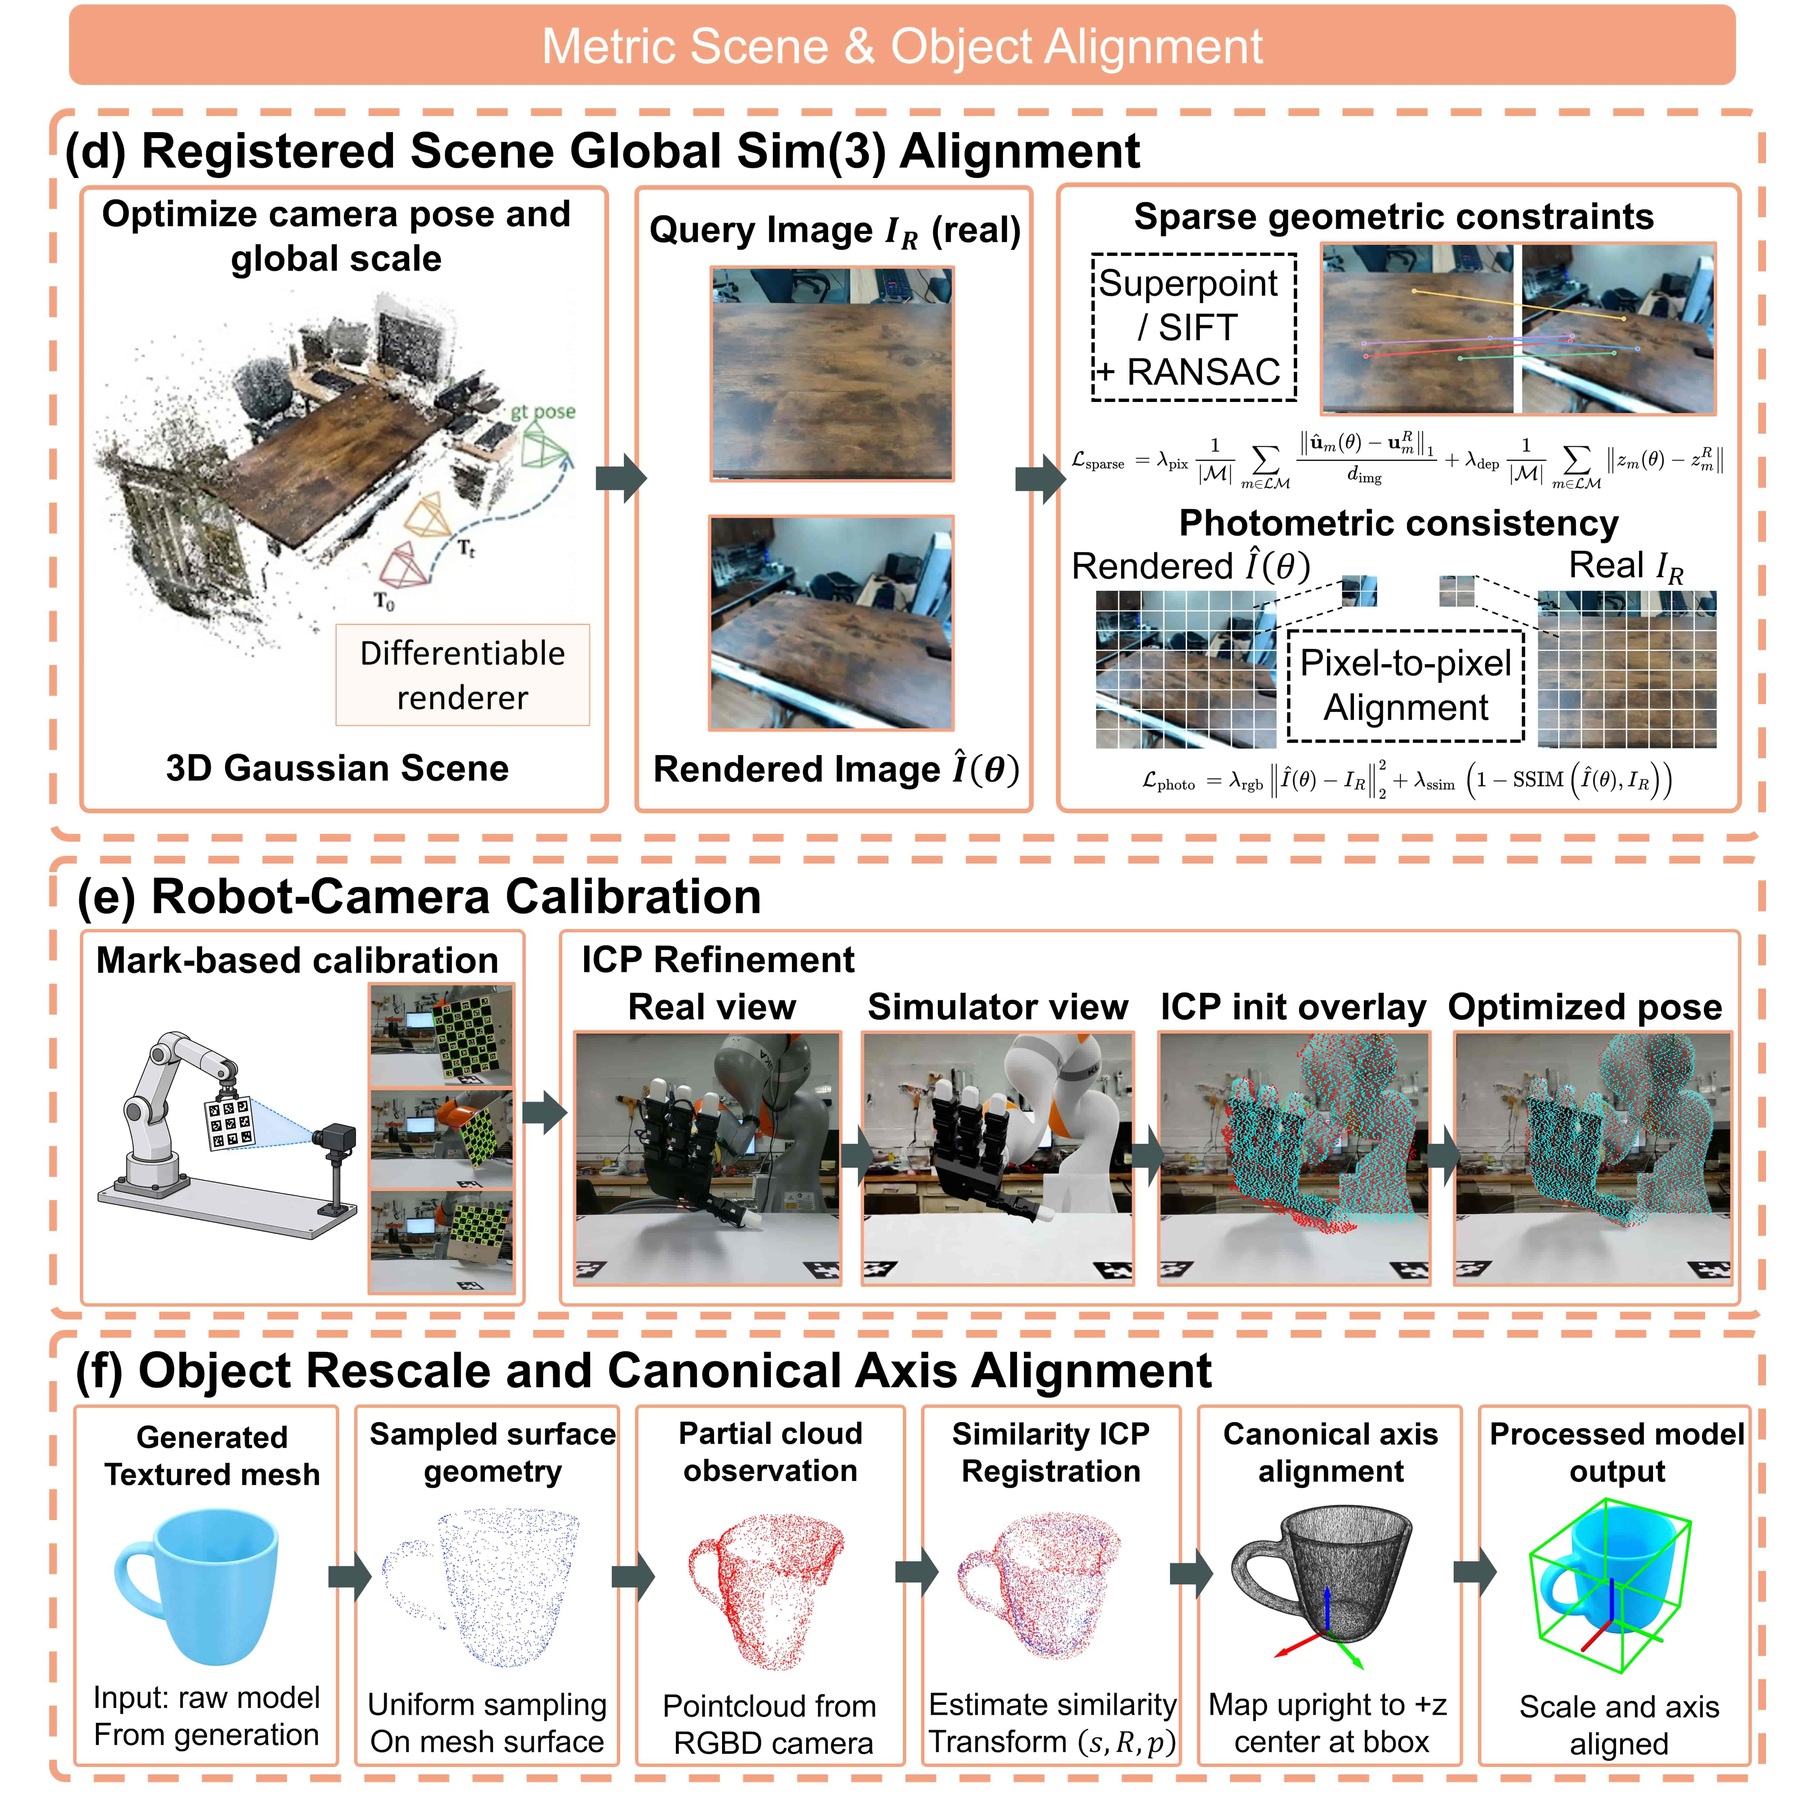
Robot and scene calibration aligns object scale and pose for physical deployment.
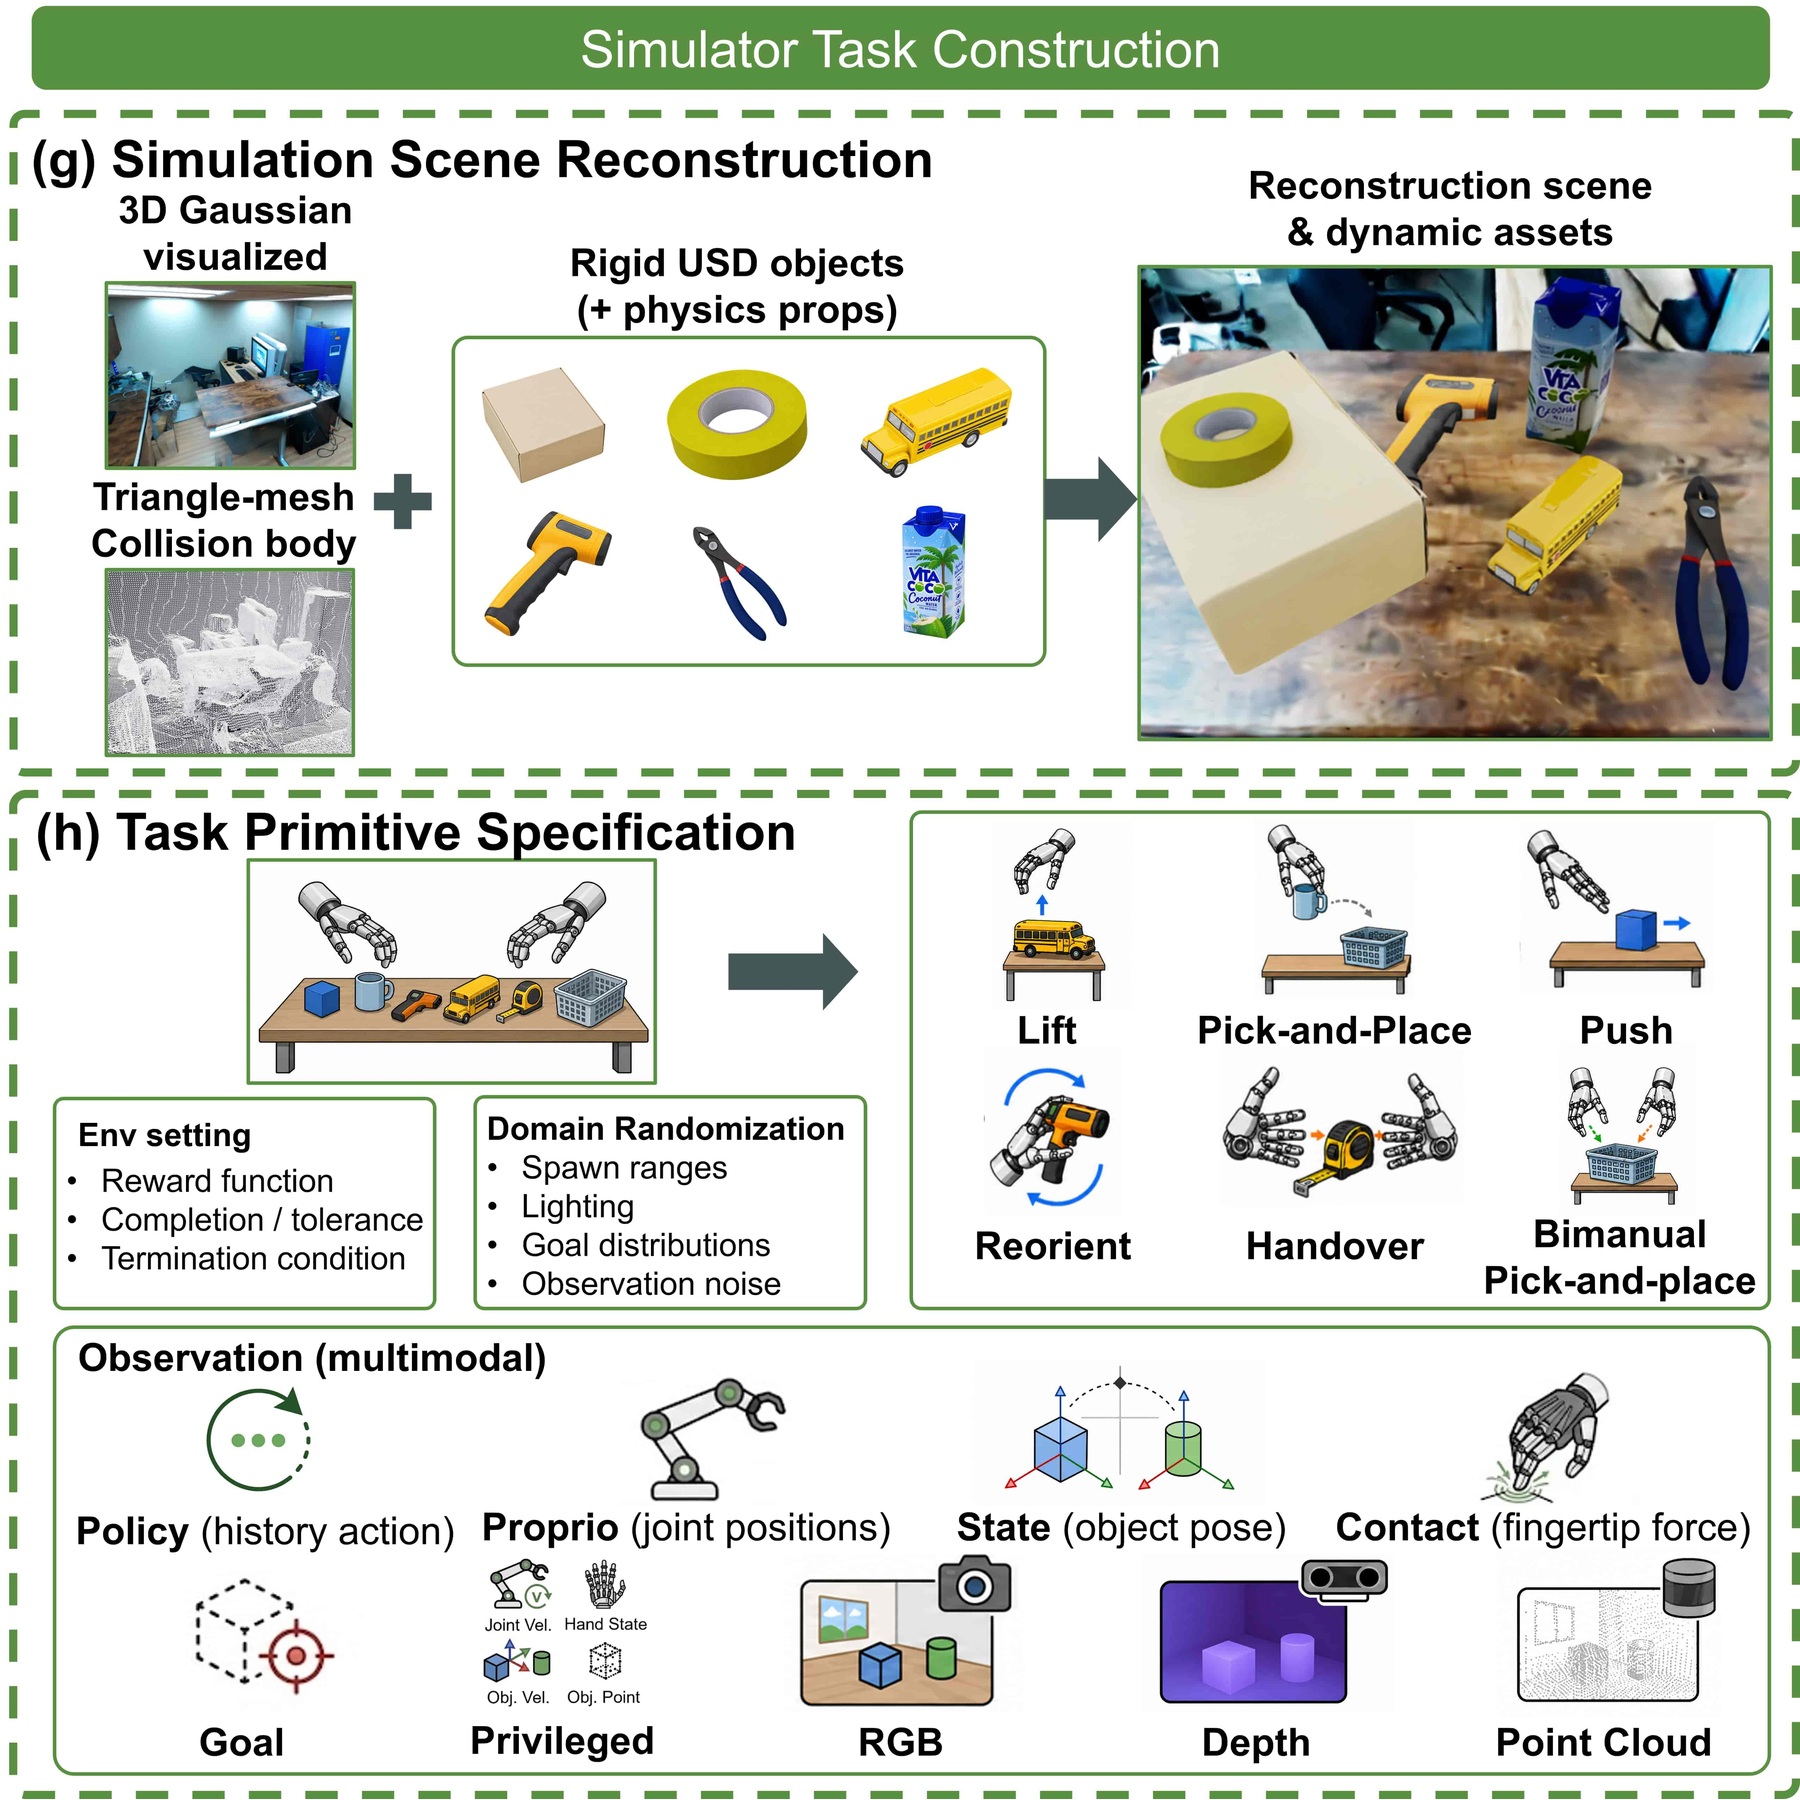
Reusable simulation tasks and multimodal observations support policy learning.
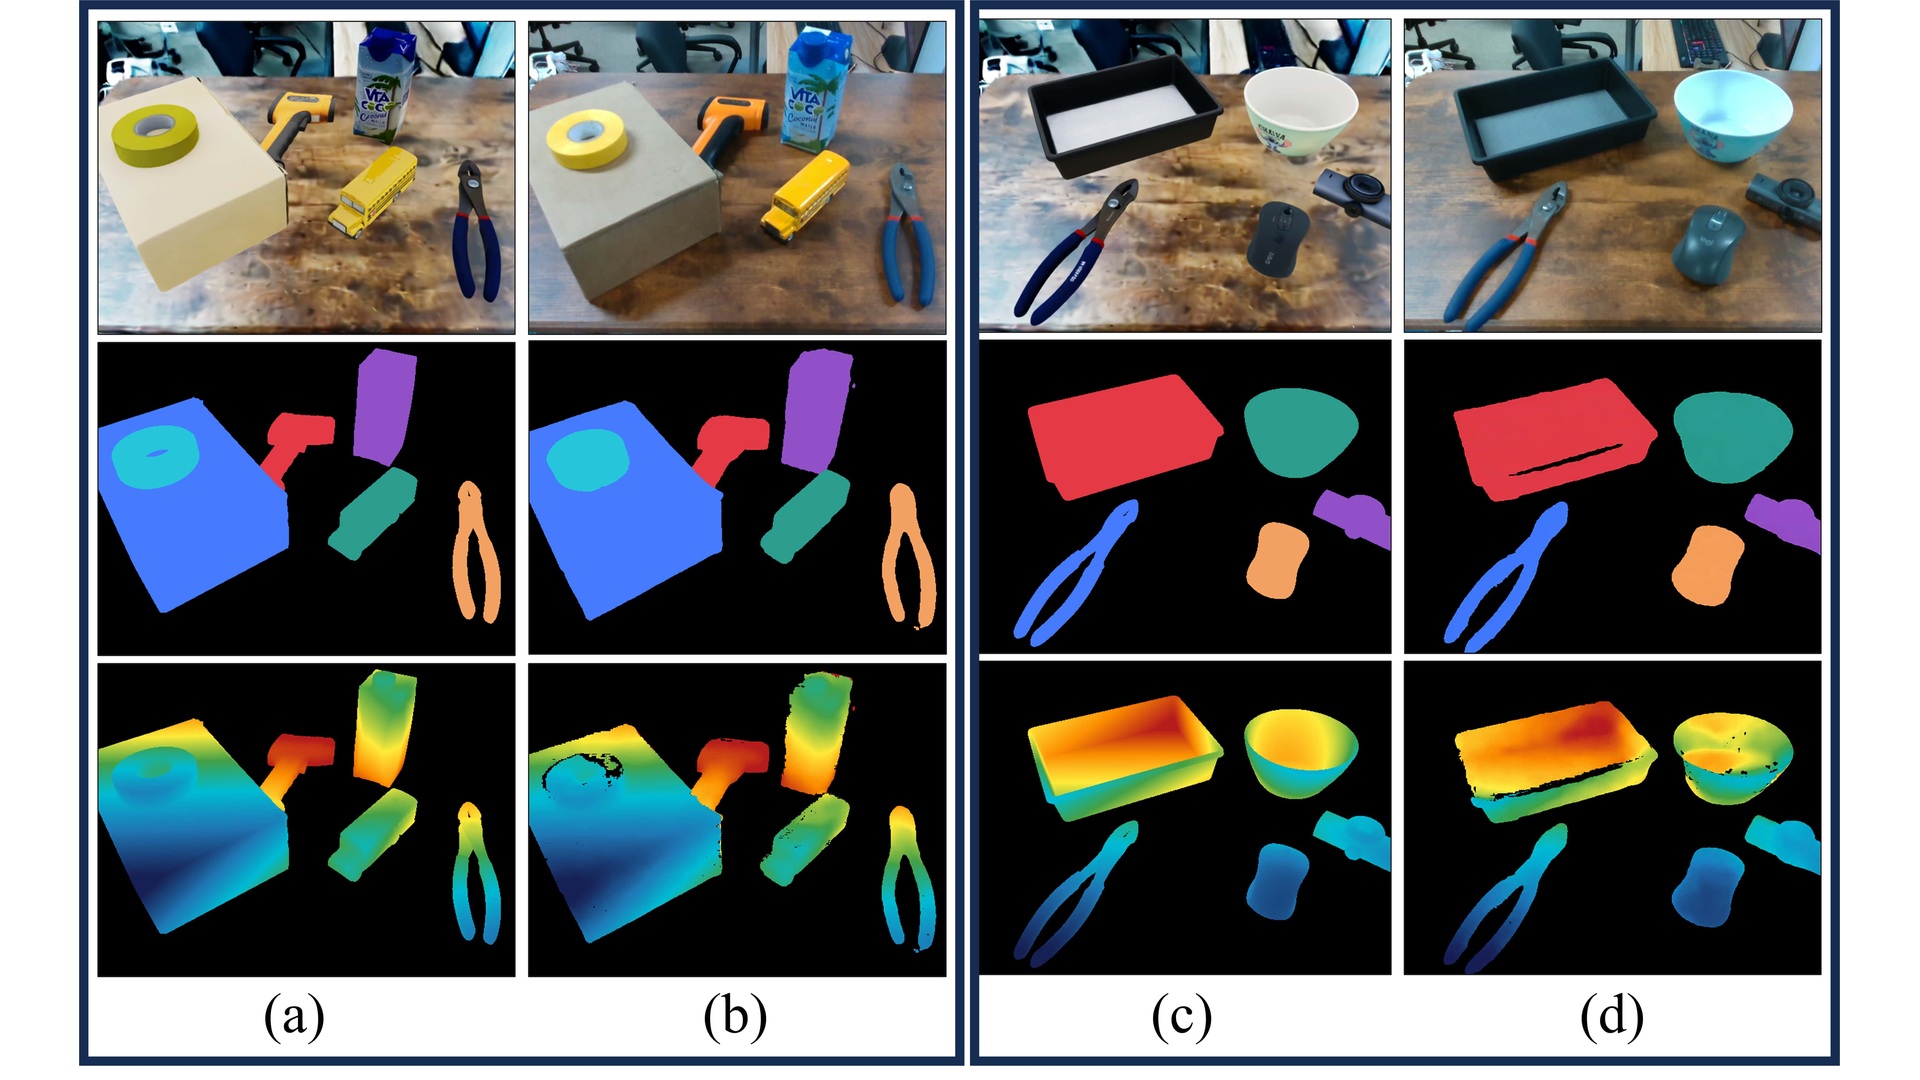
Simulated and real workspaces are compared through RGB images, instance masks, and depth.
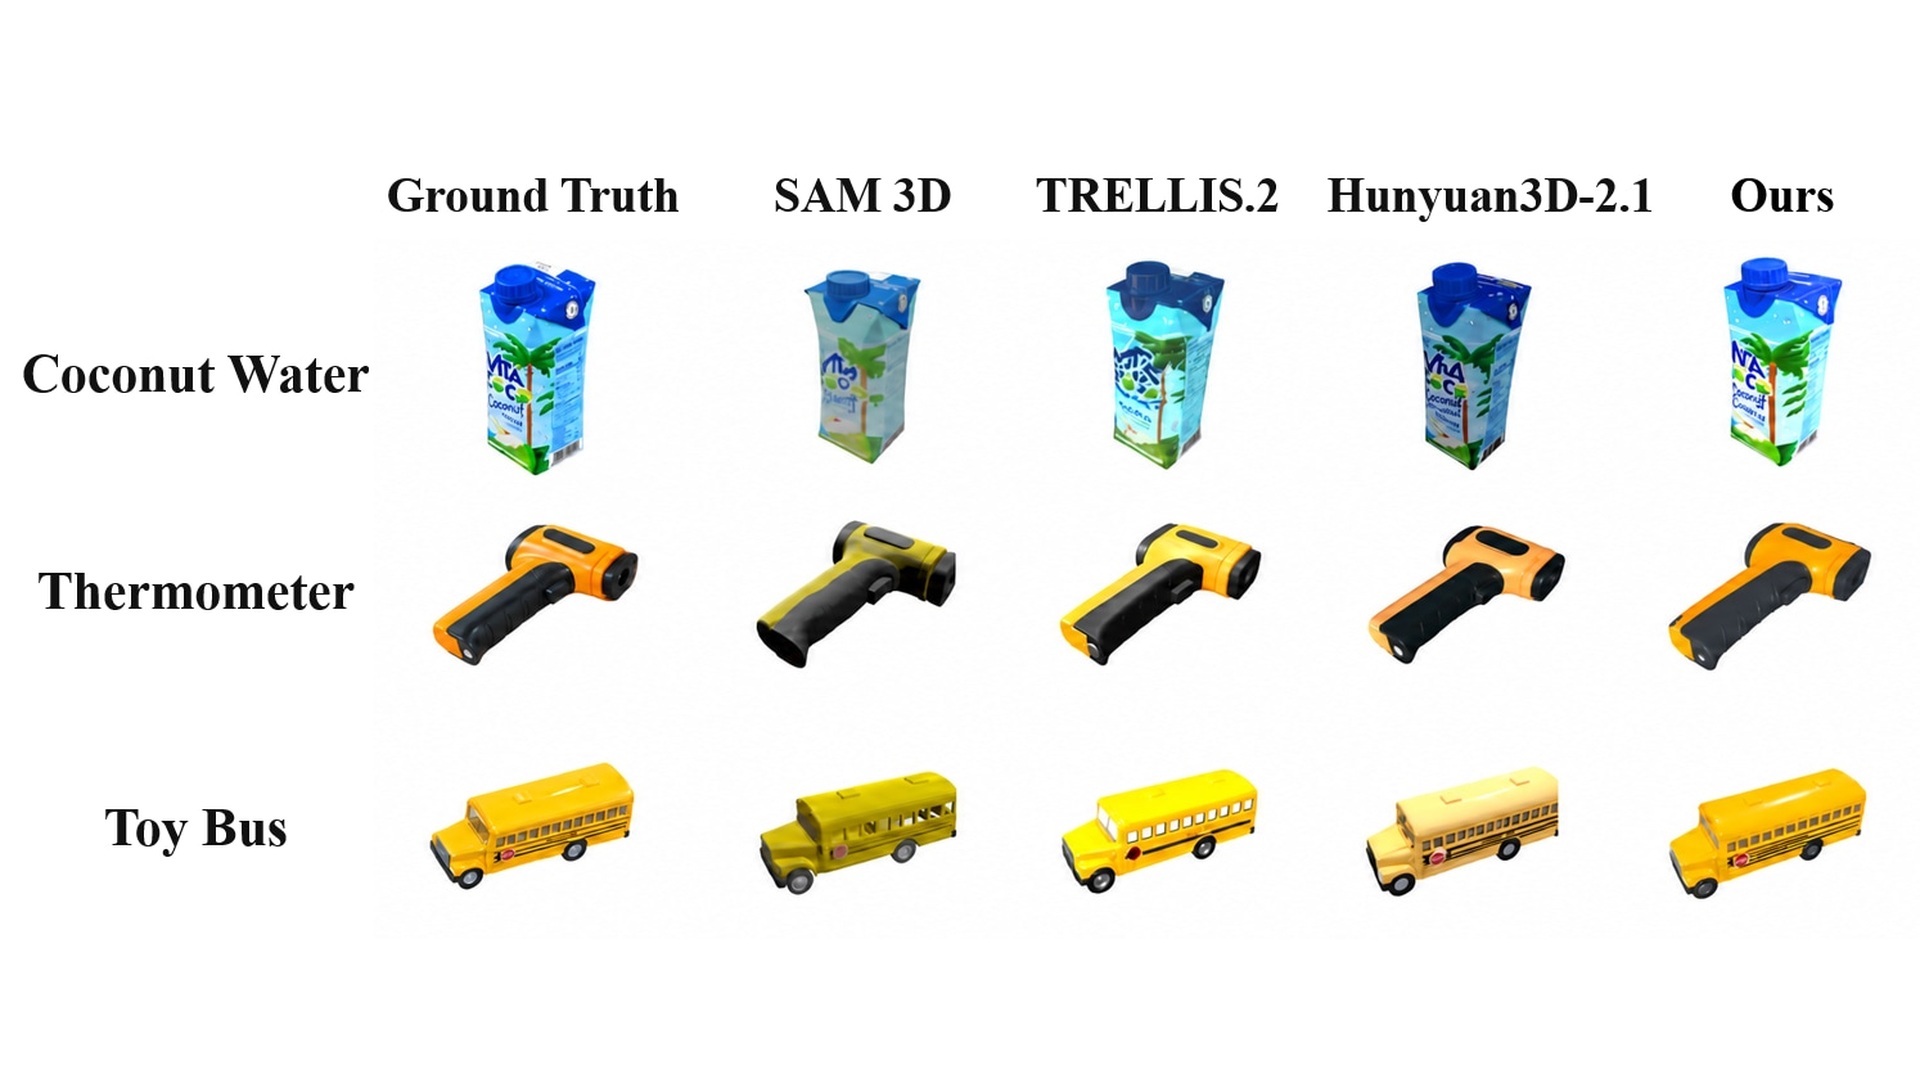
Reconstruction methods are compared using the shape and appearance of three objects.
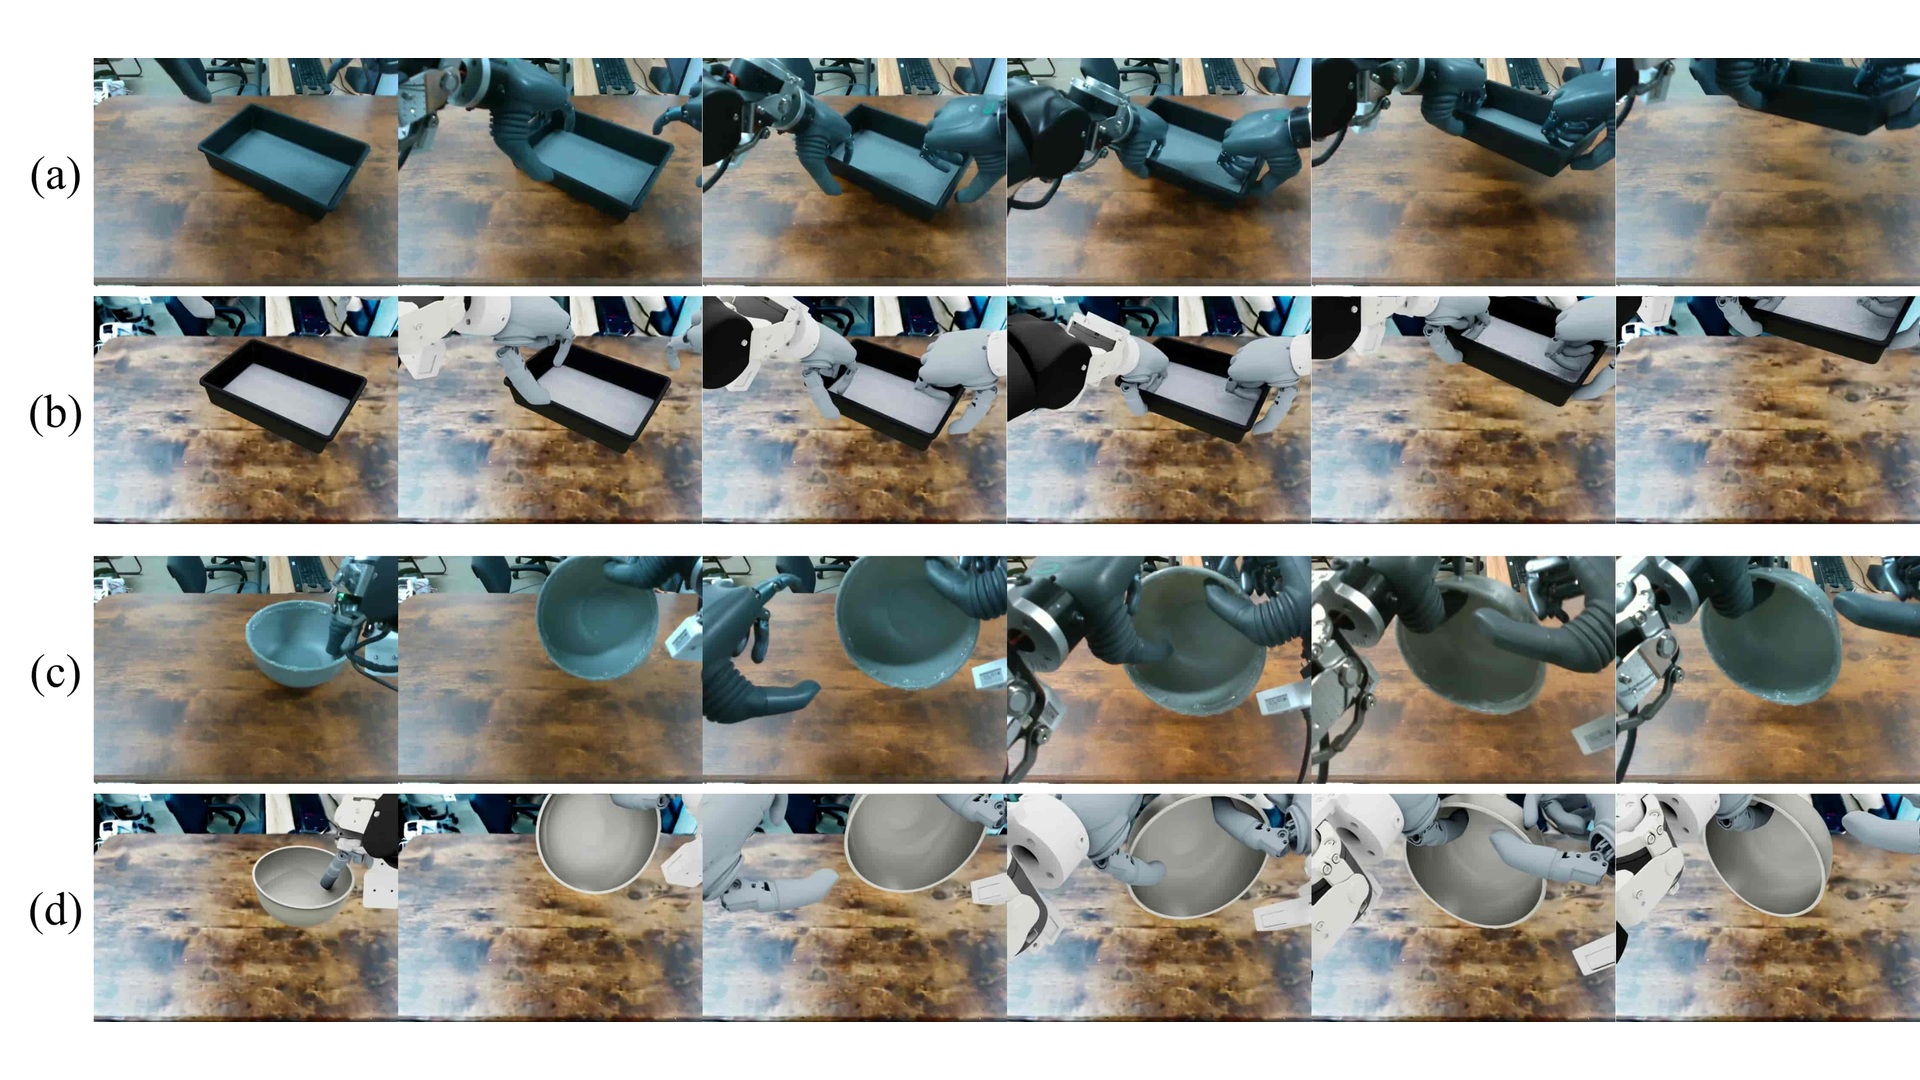
Simulated and real sequences show basket lifting and bowl handover across interaction stages.
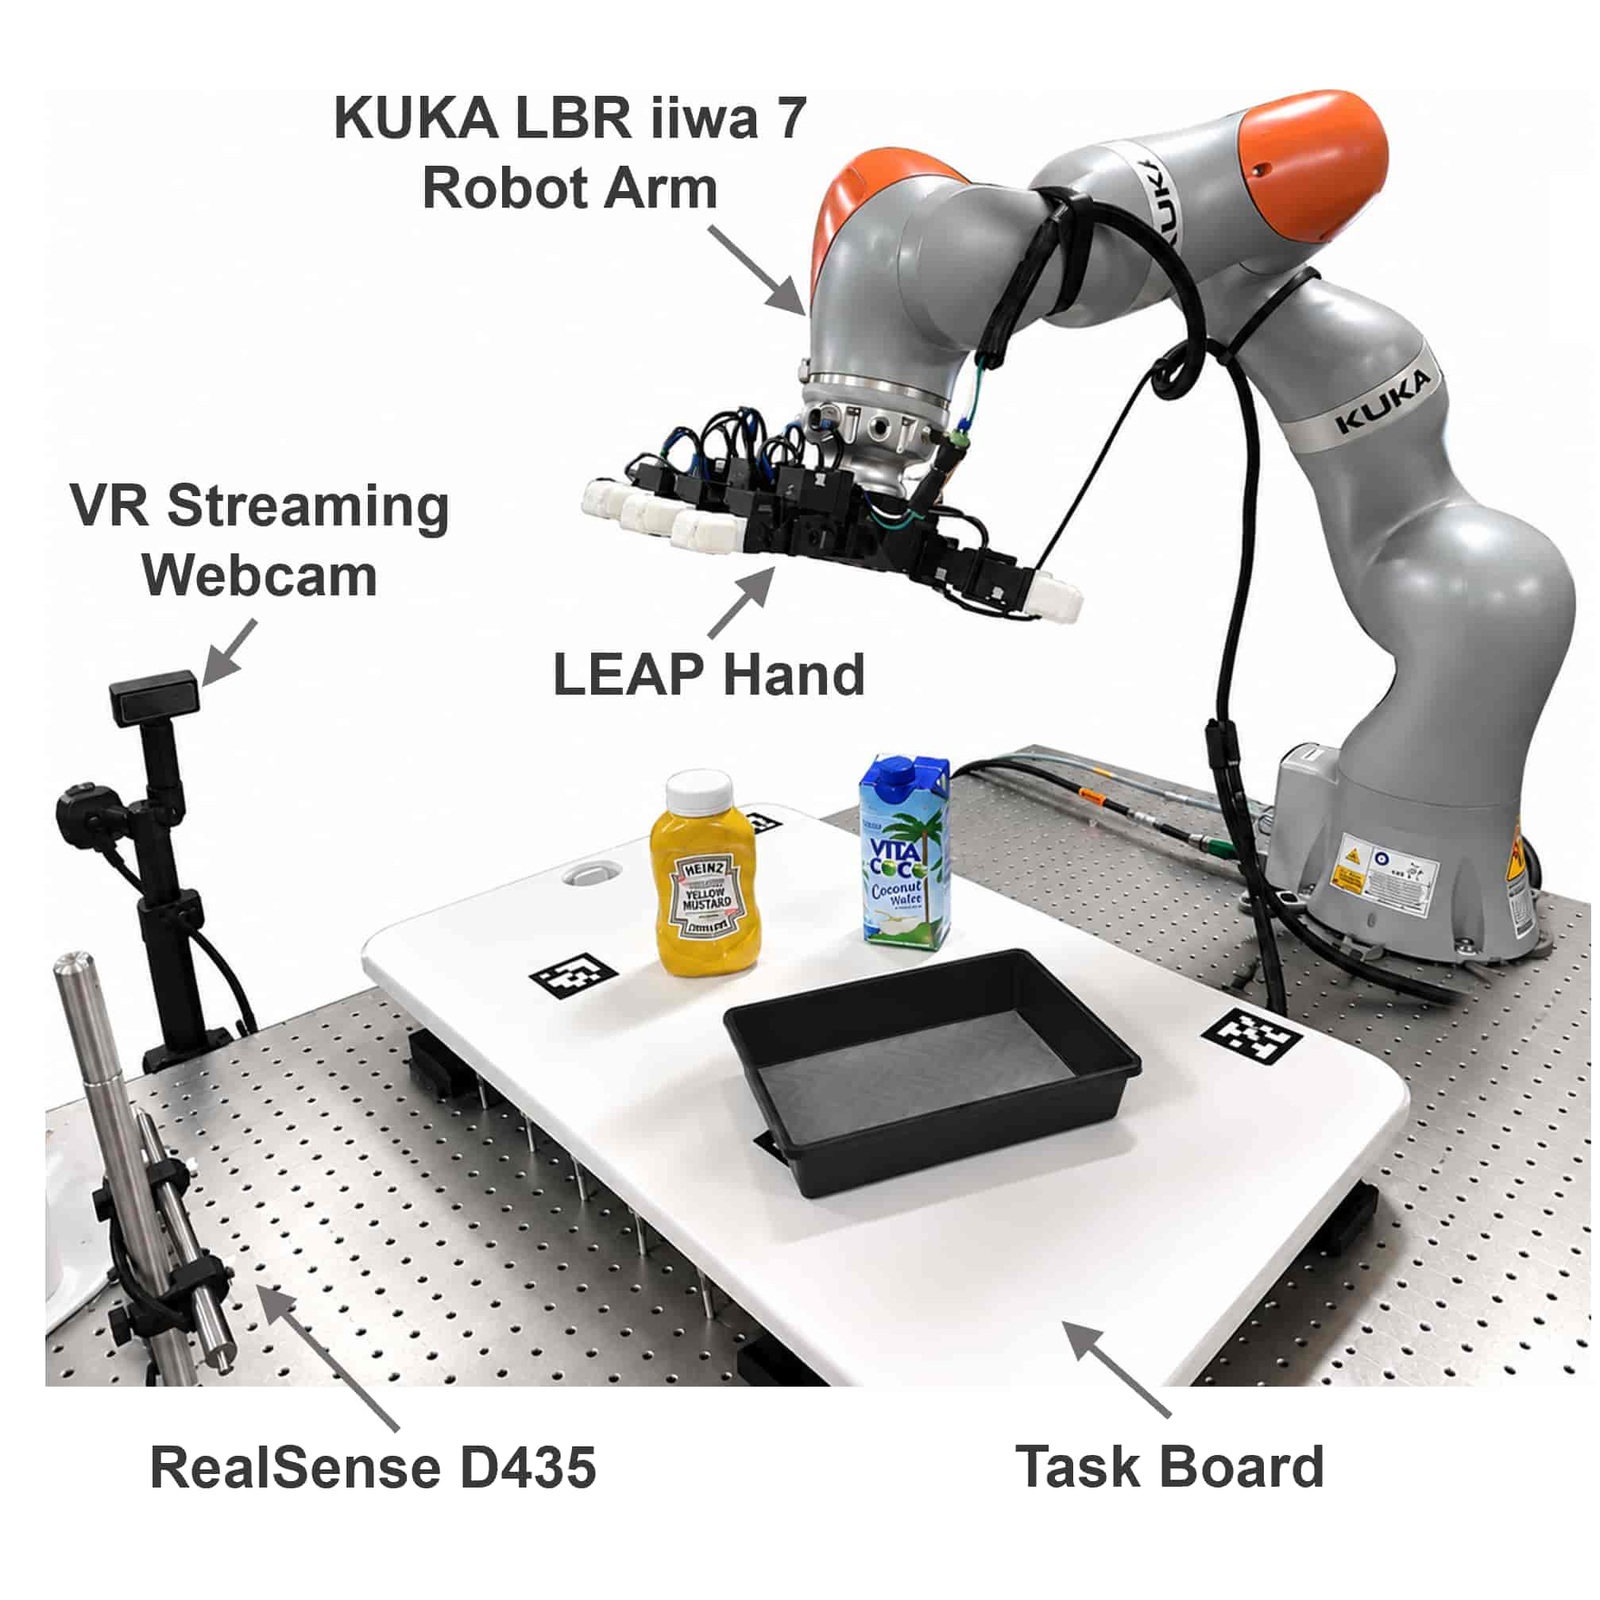
A KUKA LBR iiwa 7 with a LEAP Hand uses cameras and a task board for dexterous manipulation.
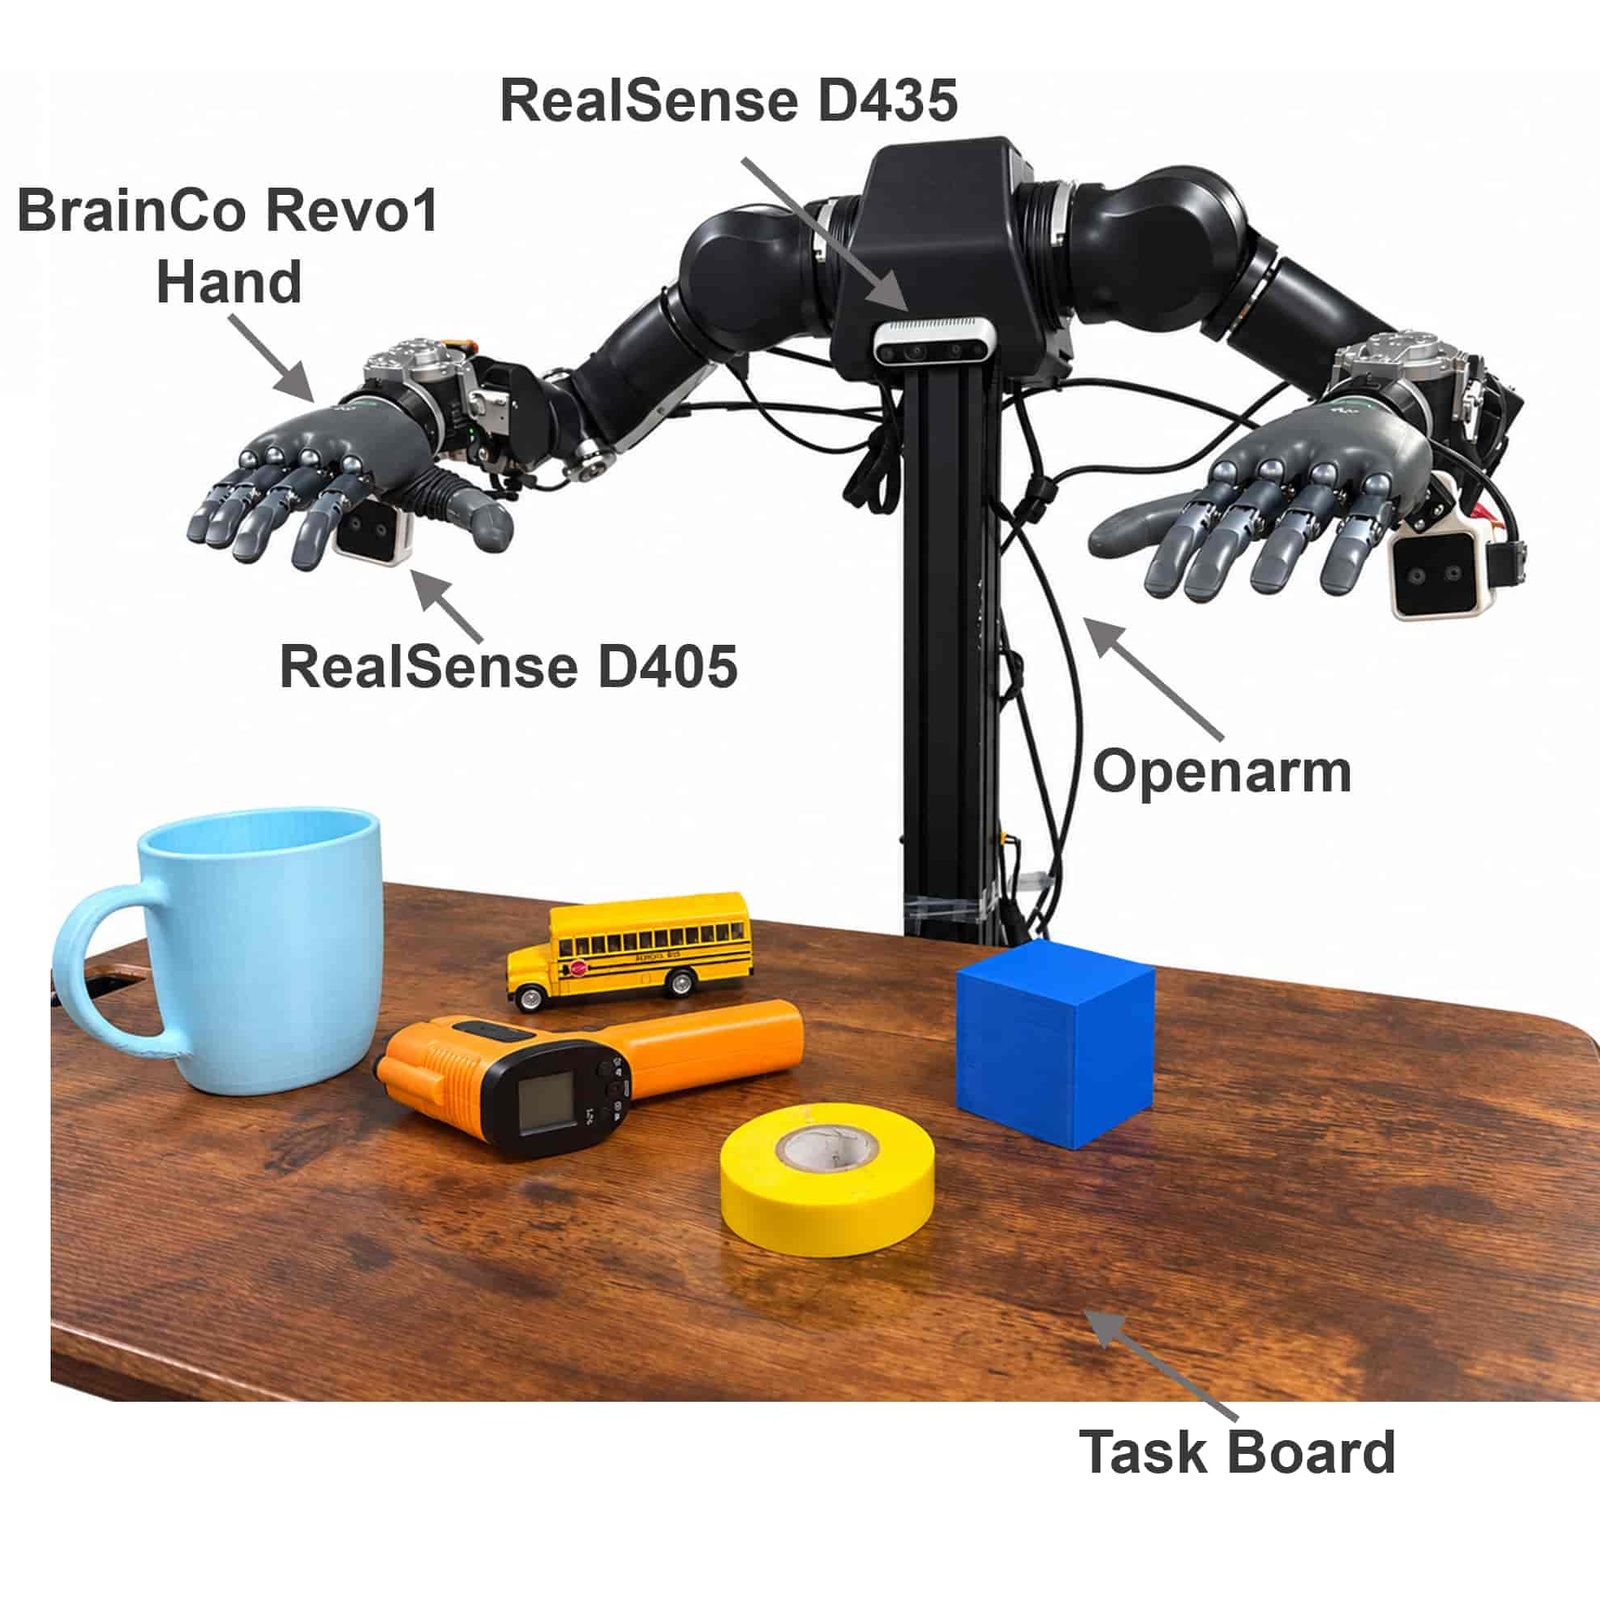
OpenArm combines two arms and BrainCo Revo1 hands for coordinated bimanual manipulation.
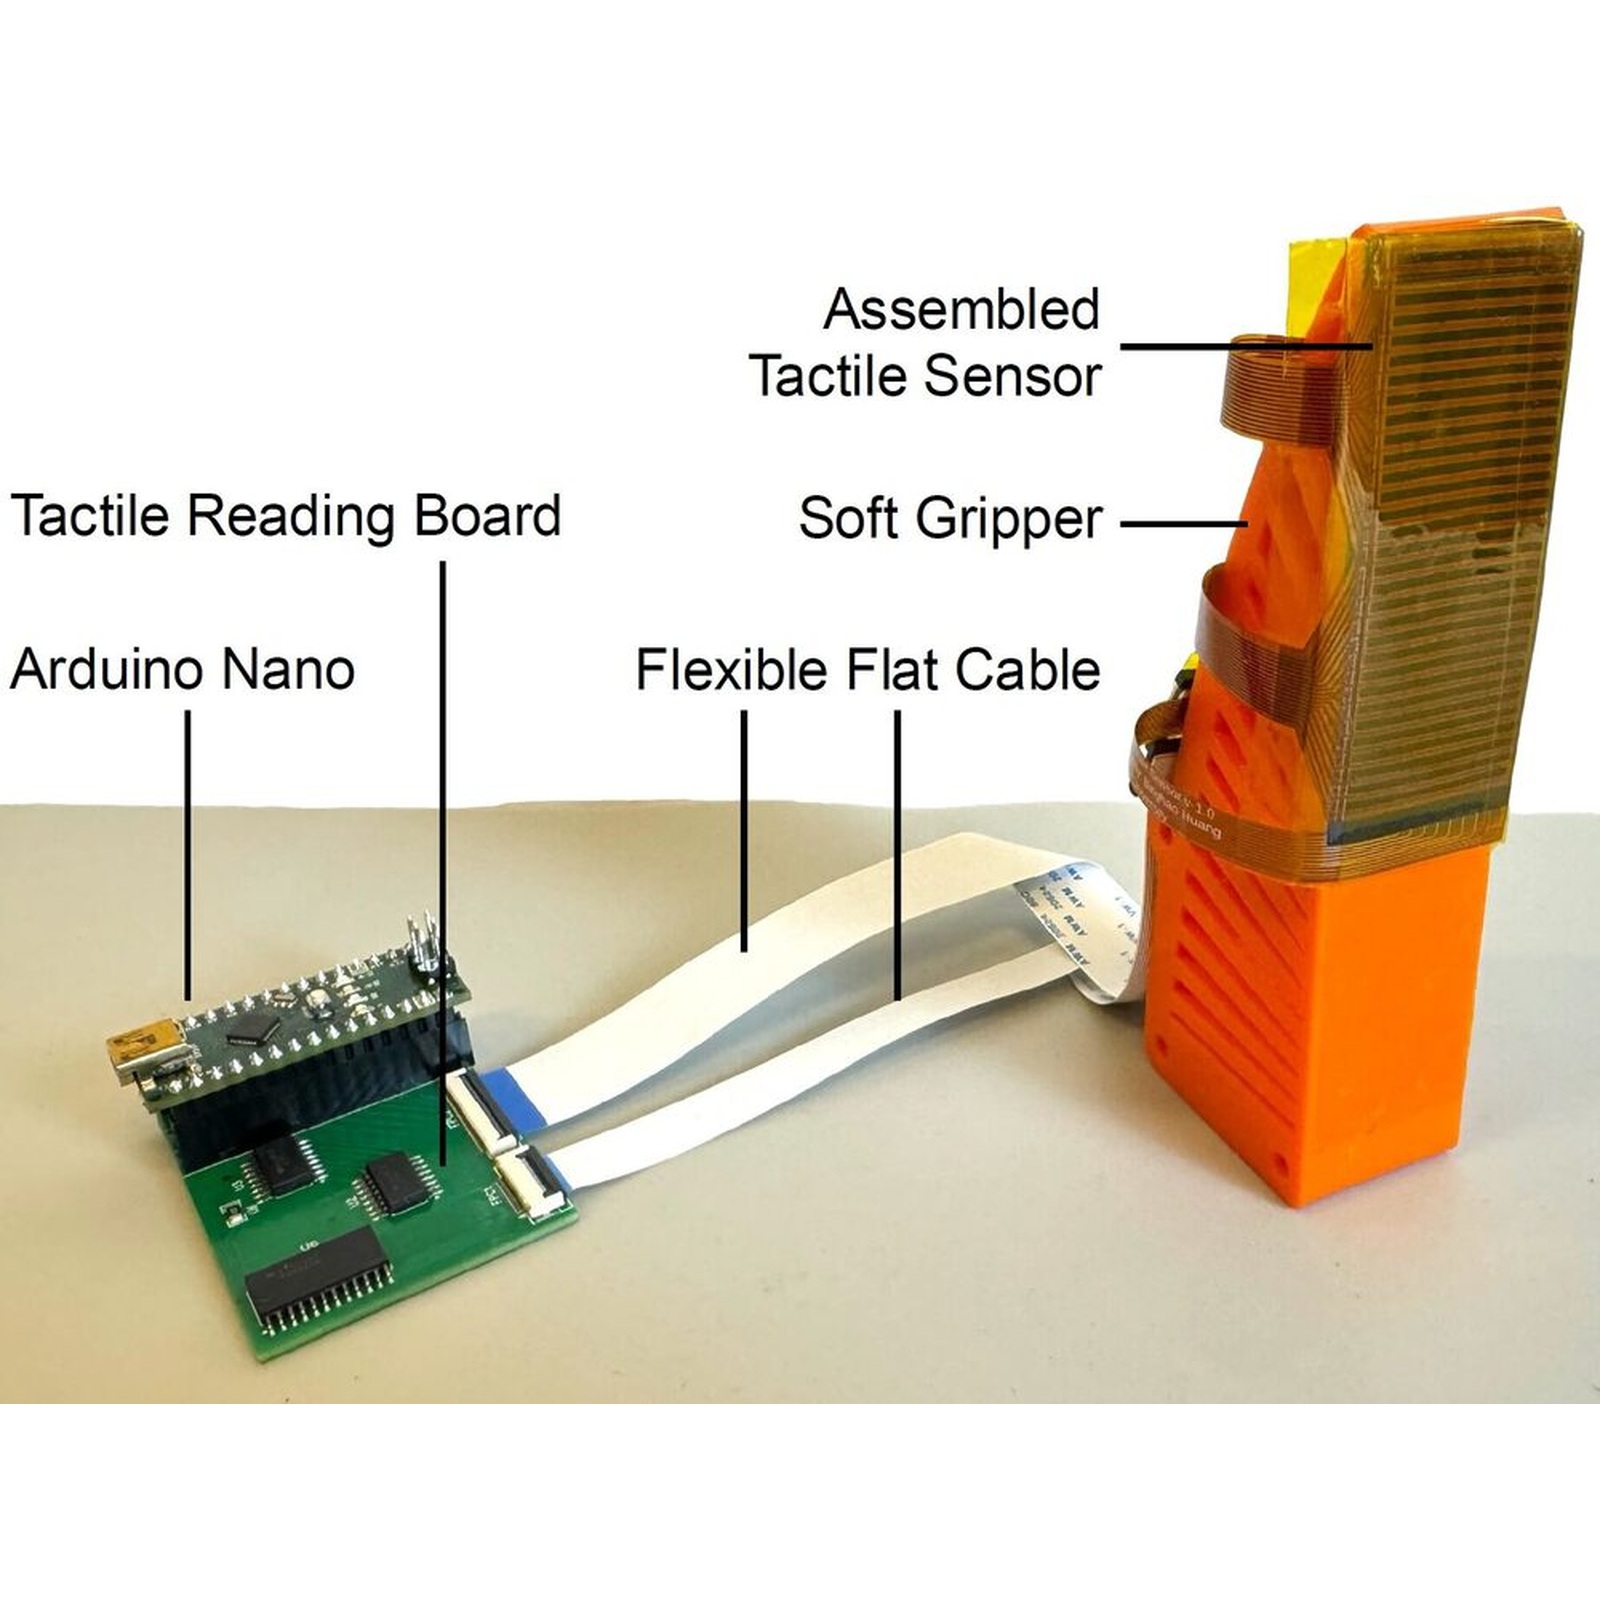
A soft gripper integrates a flexible tactile array and Arduino Nano electronics for readout.
A robot-mounted gripper performs contact experiments and displays live tactile measurements.
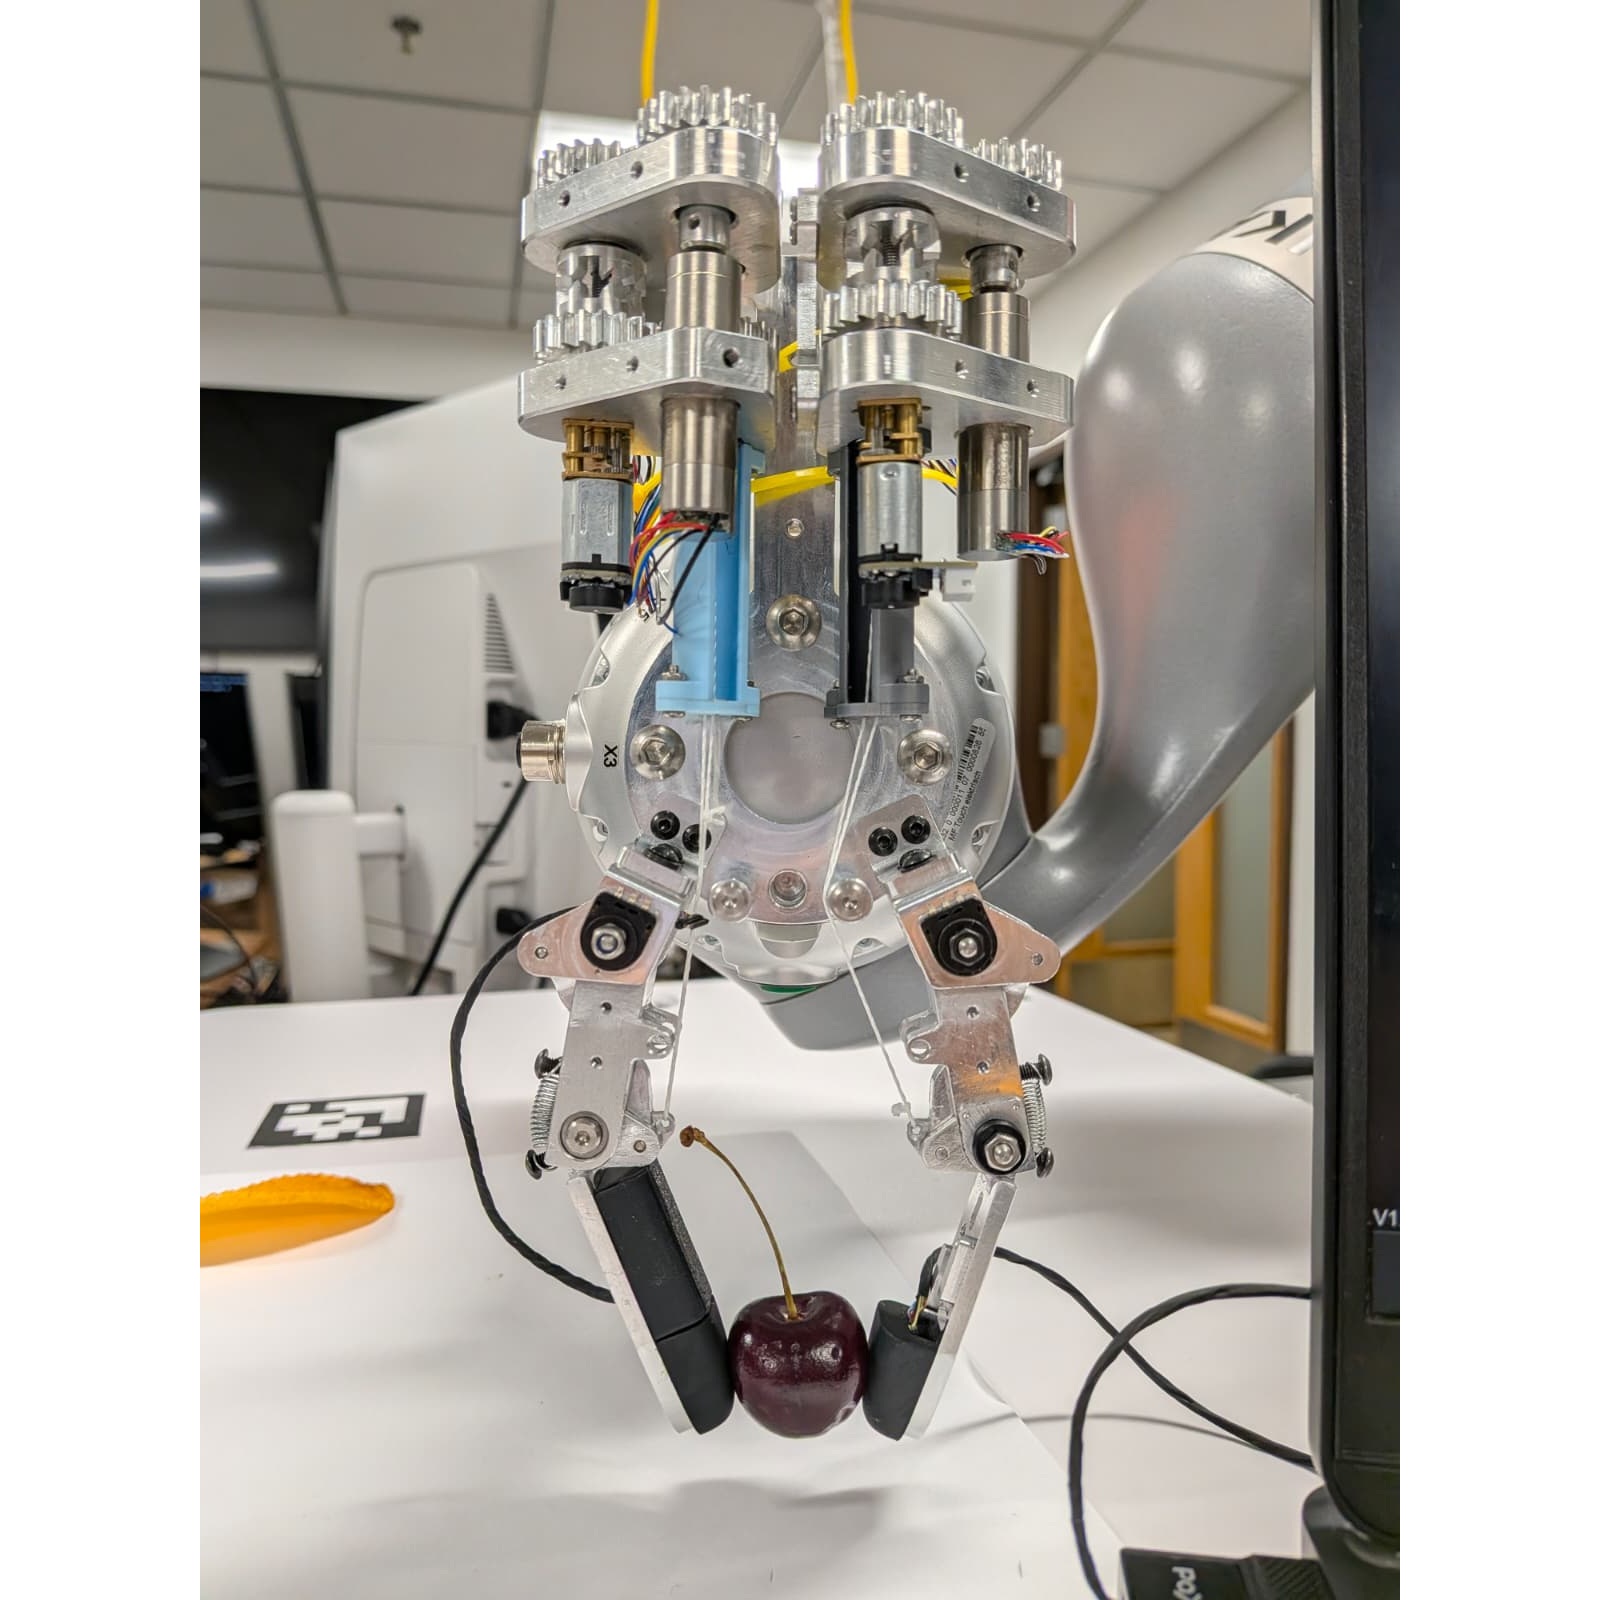
Twisted-tendon fingers grasp an object and provide a test platform for tactile manipulation.
A benchtop setup combines twisted-tendon actuation and electronics for actuator characterization.
Explore the interactive demonstrations and full project details below, or open the DEXTERA project website.
© MINIMAX Lab, Walker Department of Mechanical Engineering, The University of Texas at Austin. All rights reserved.