MINIMAX Lab
MINIMAX Research
MINIMAX develops intelligent mechatronic systems for precision instrumentation, medical devices, and robotic automation. Our research connects atomic force microscopy, magnetic capsule robots, and dexterous manipulation through a shared focus on sensing, modeling, and controlling physical interaction.
Current research directions
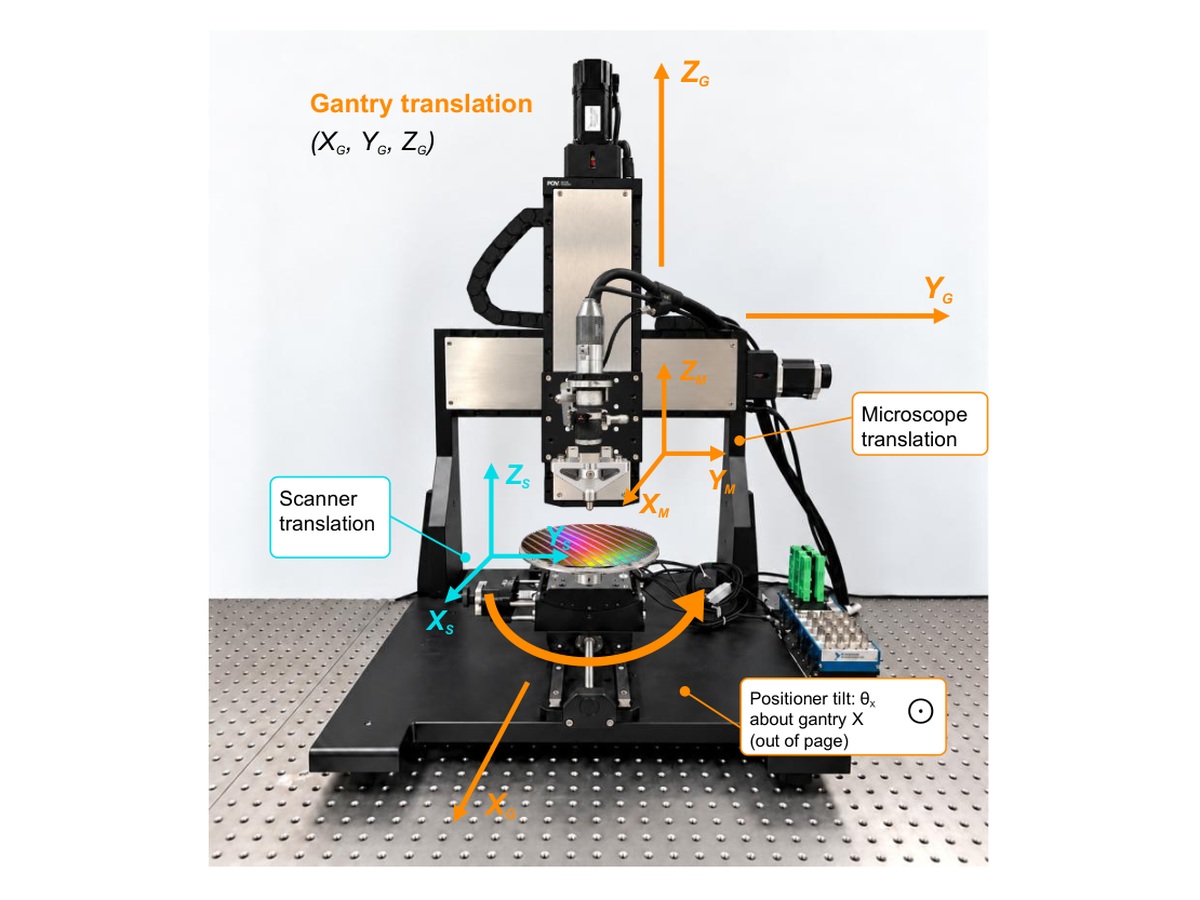
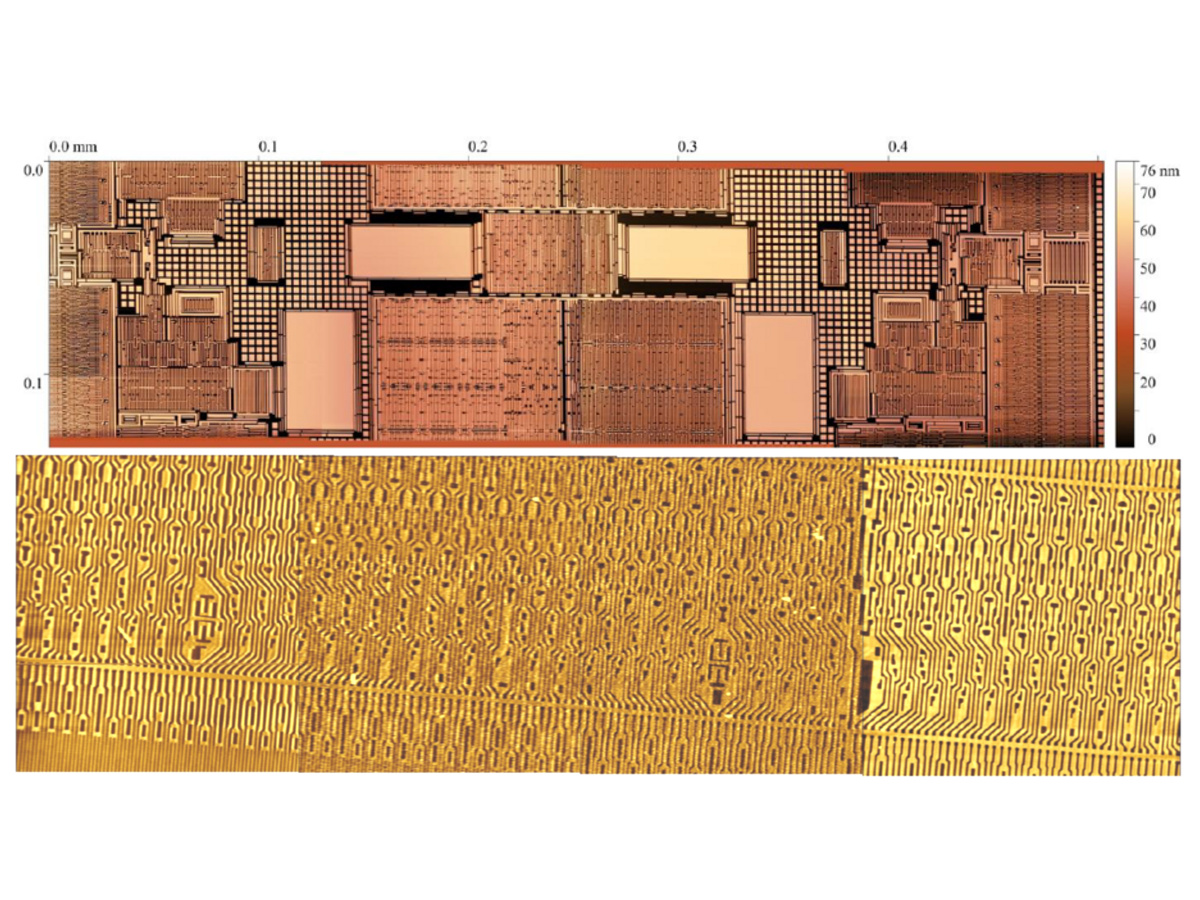
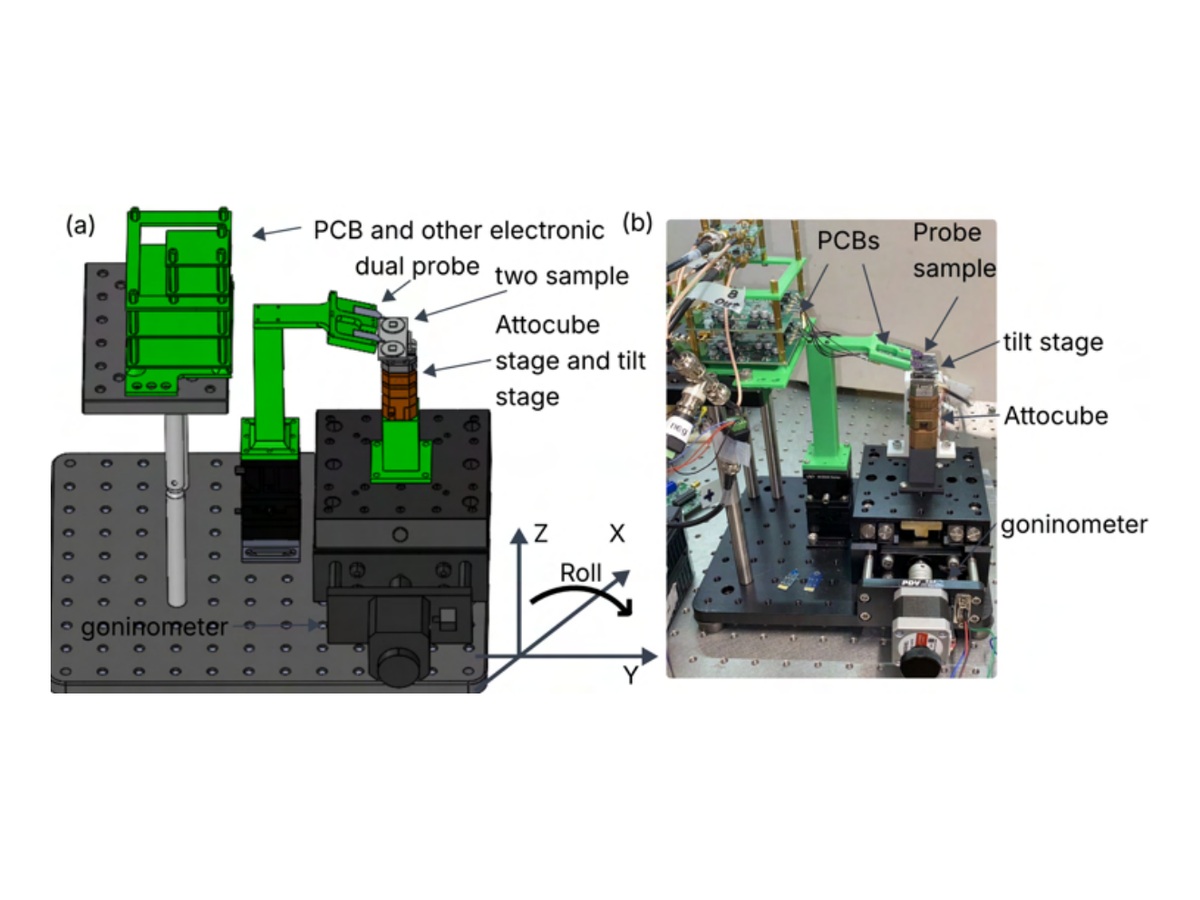
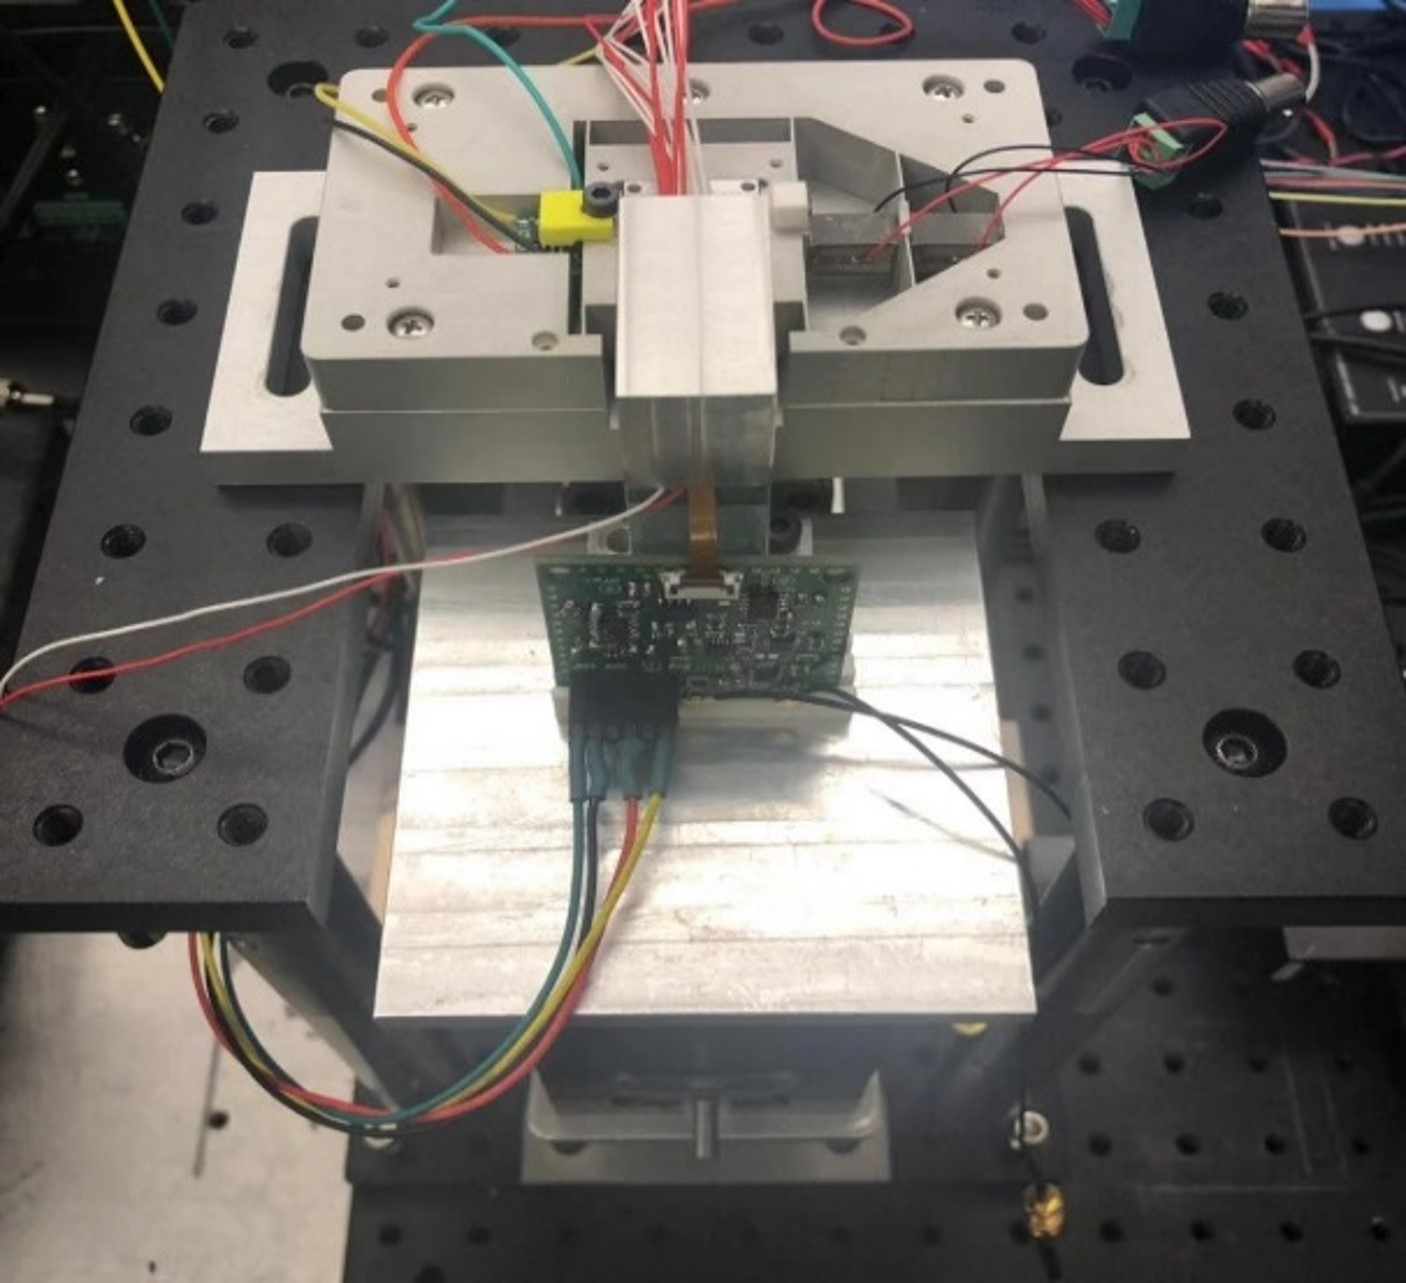
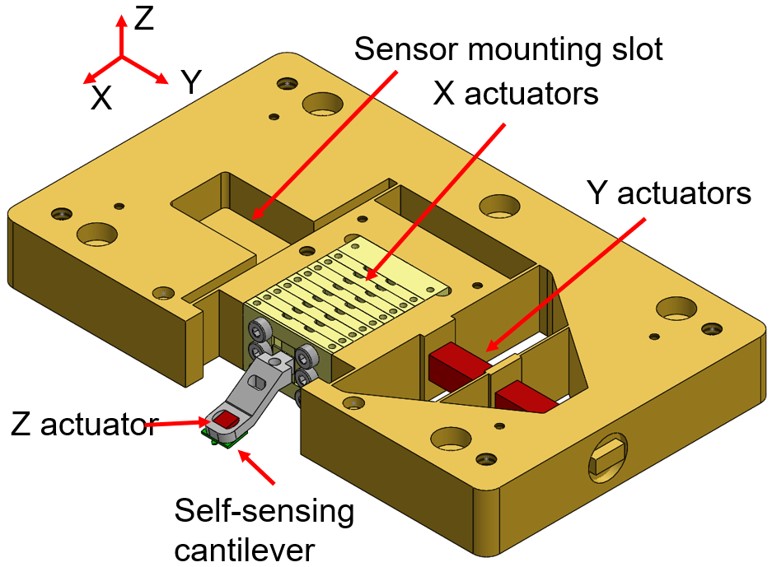
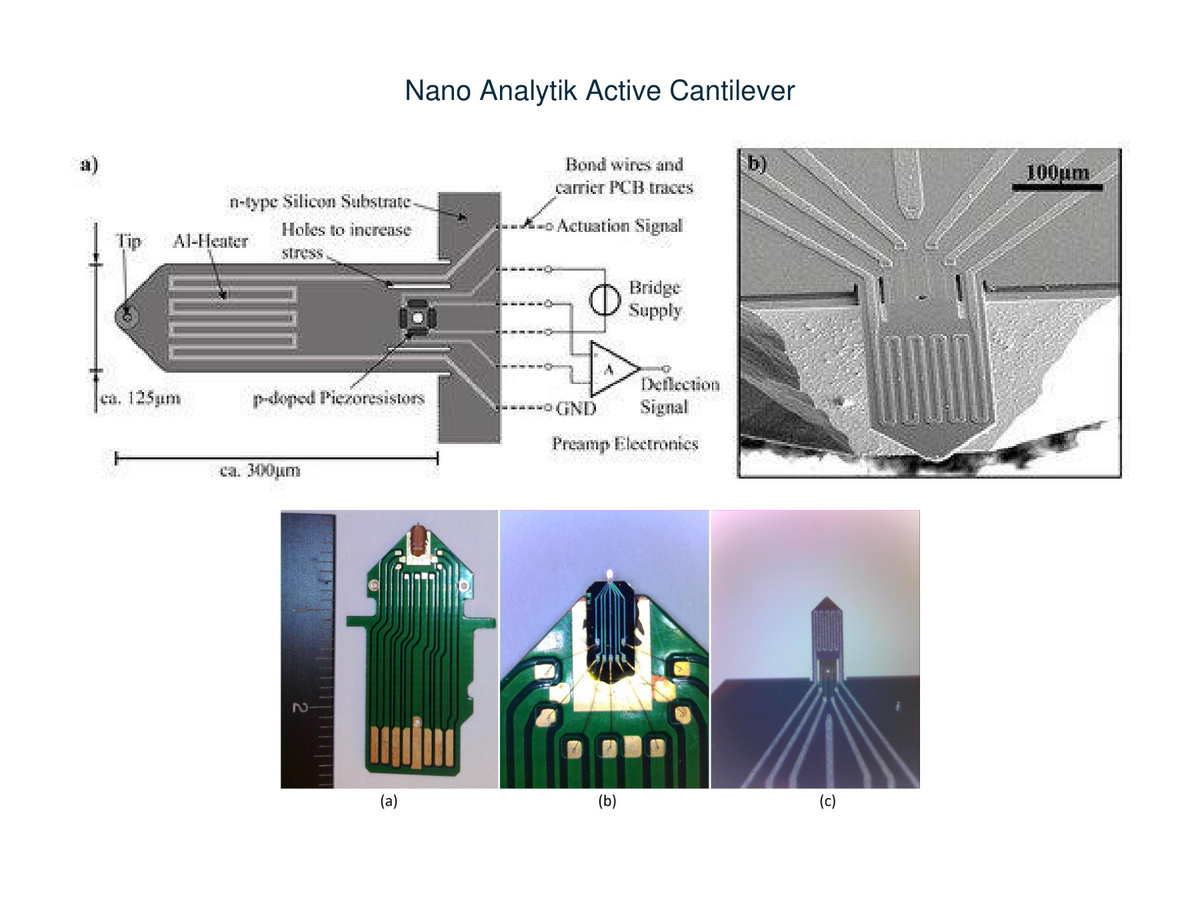
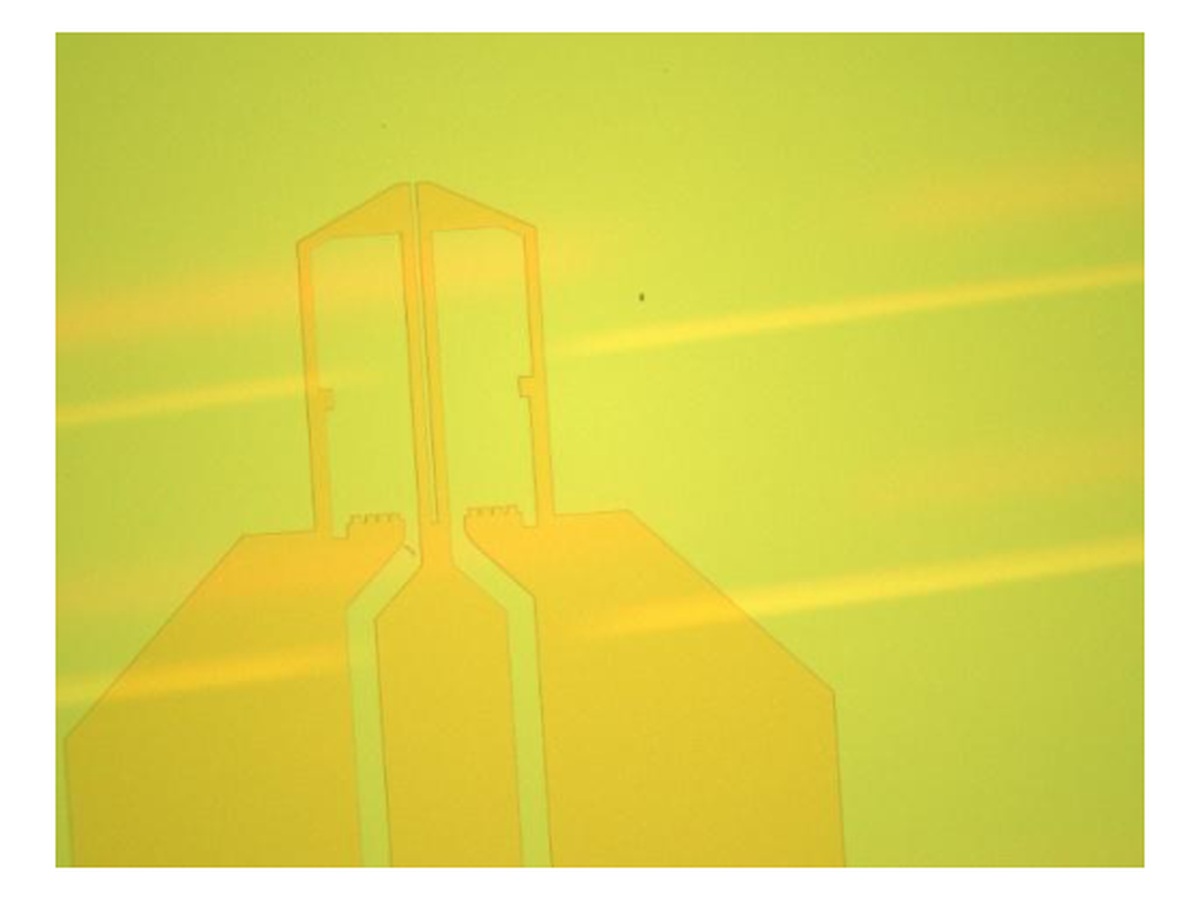
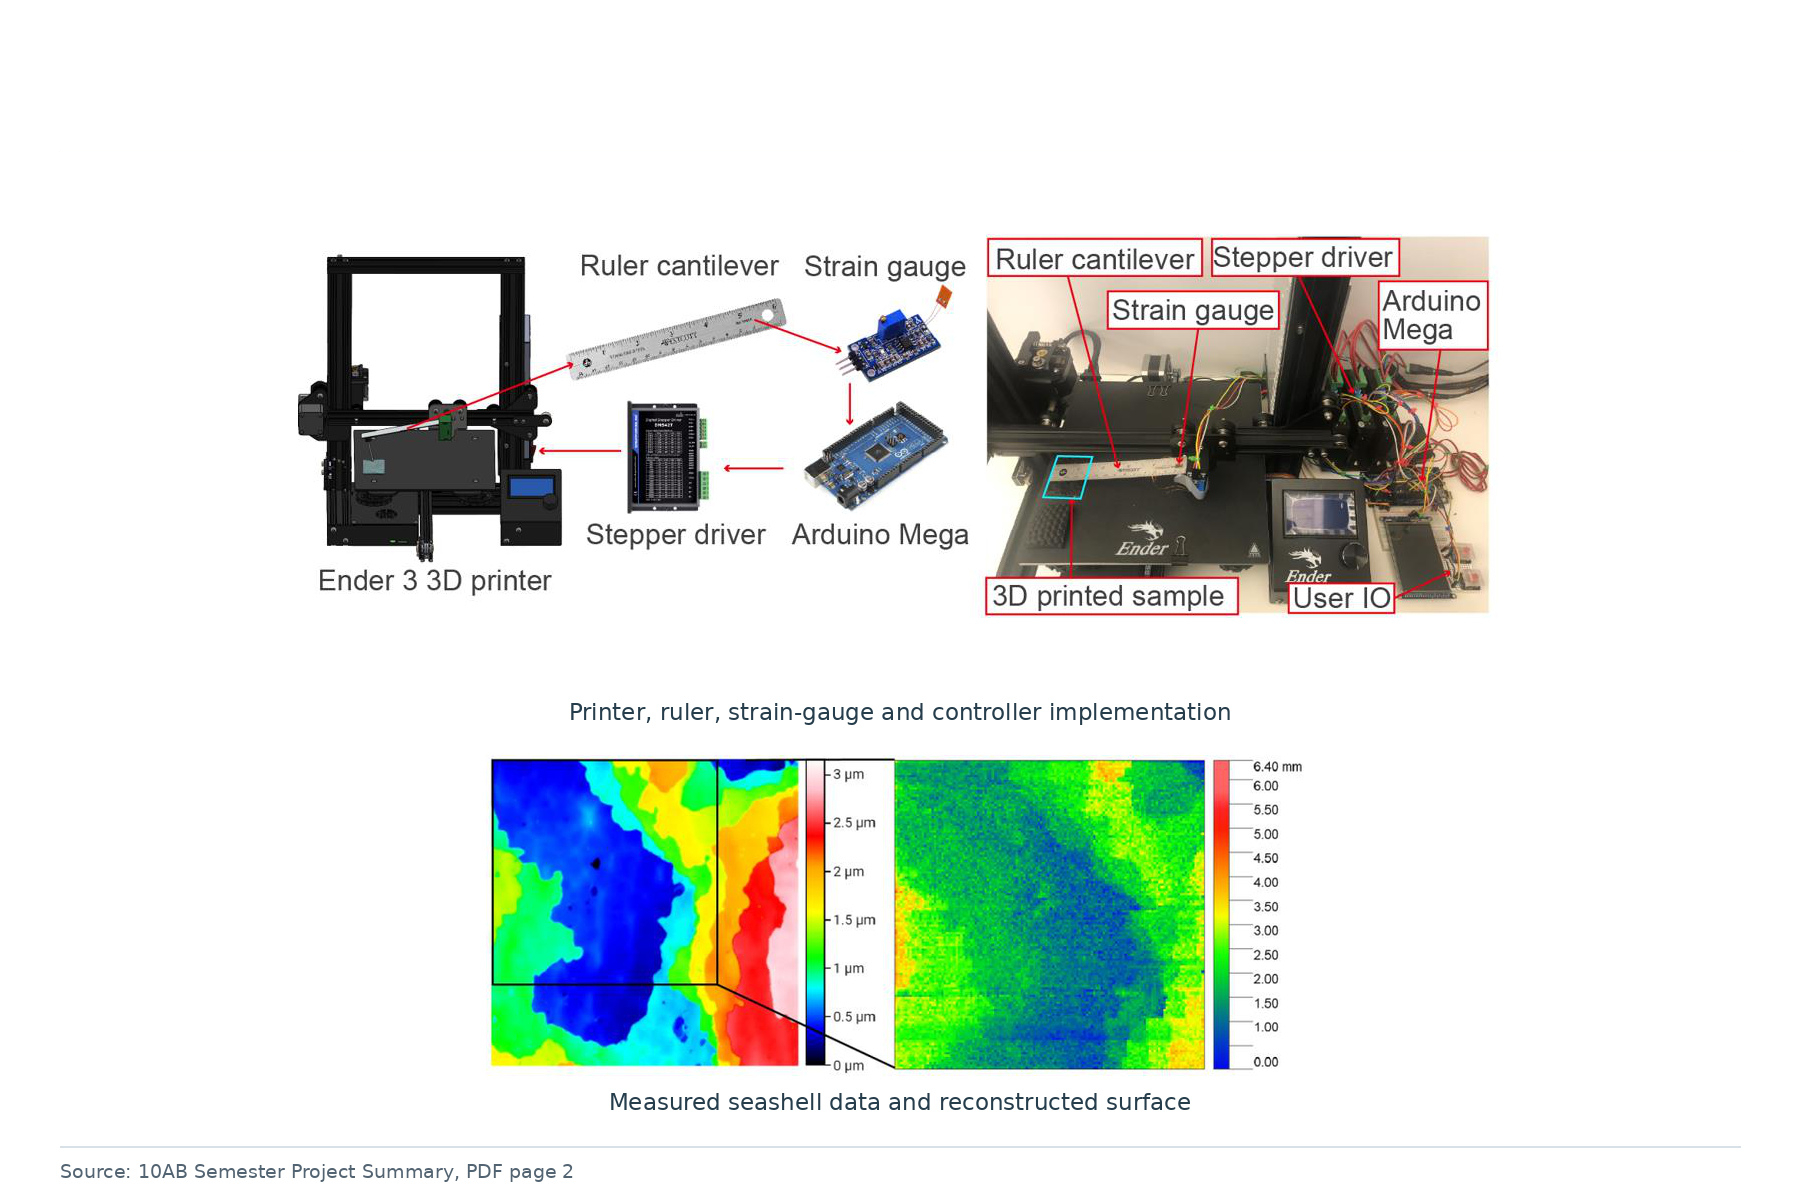
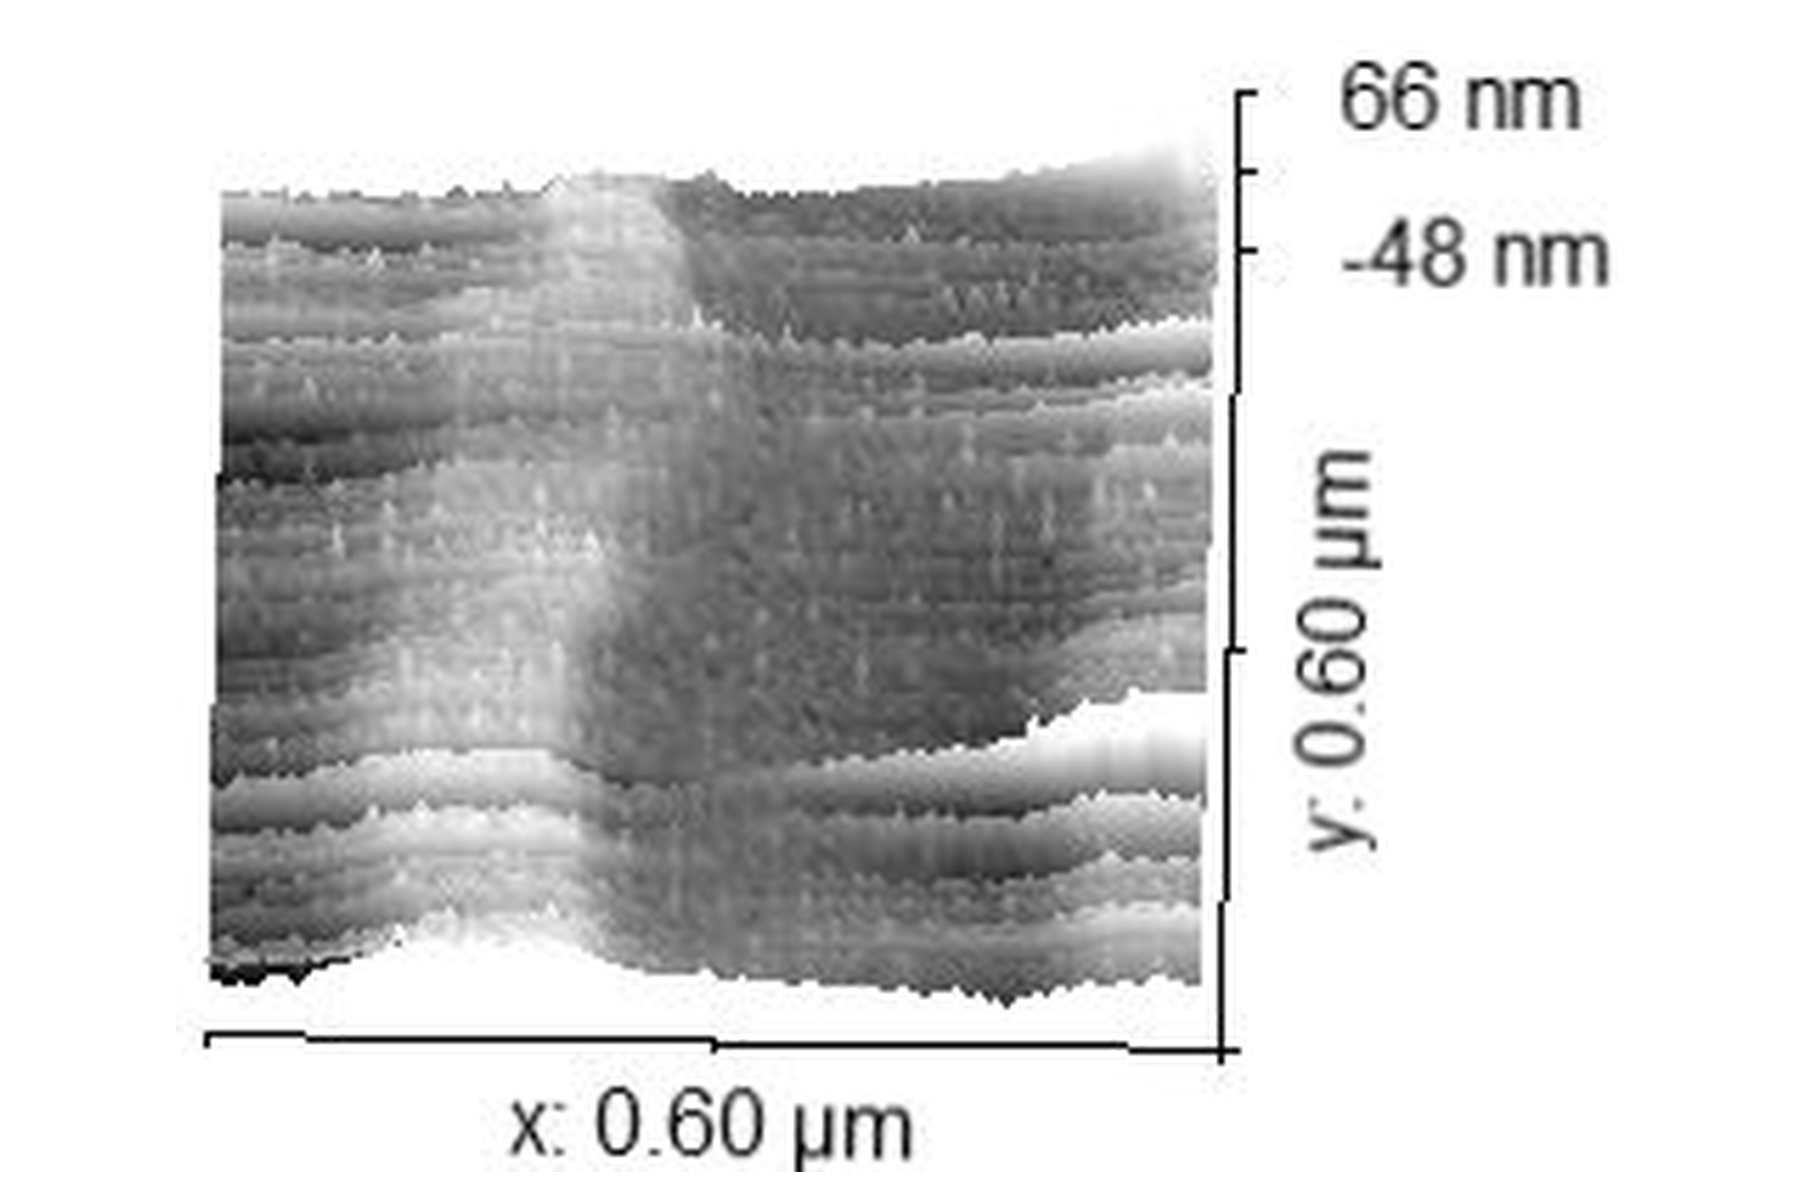
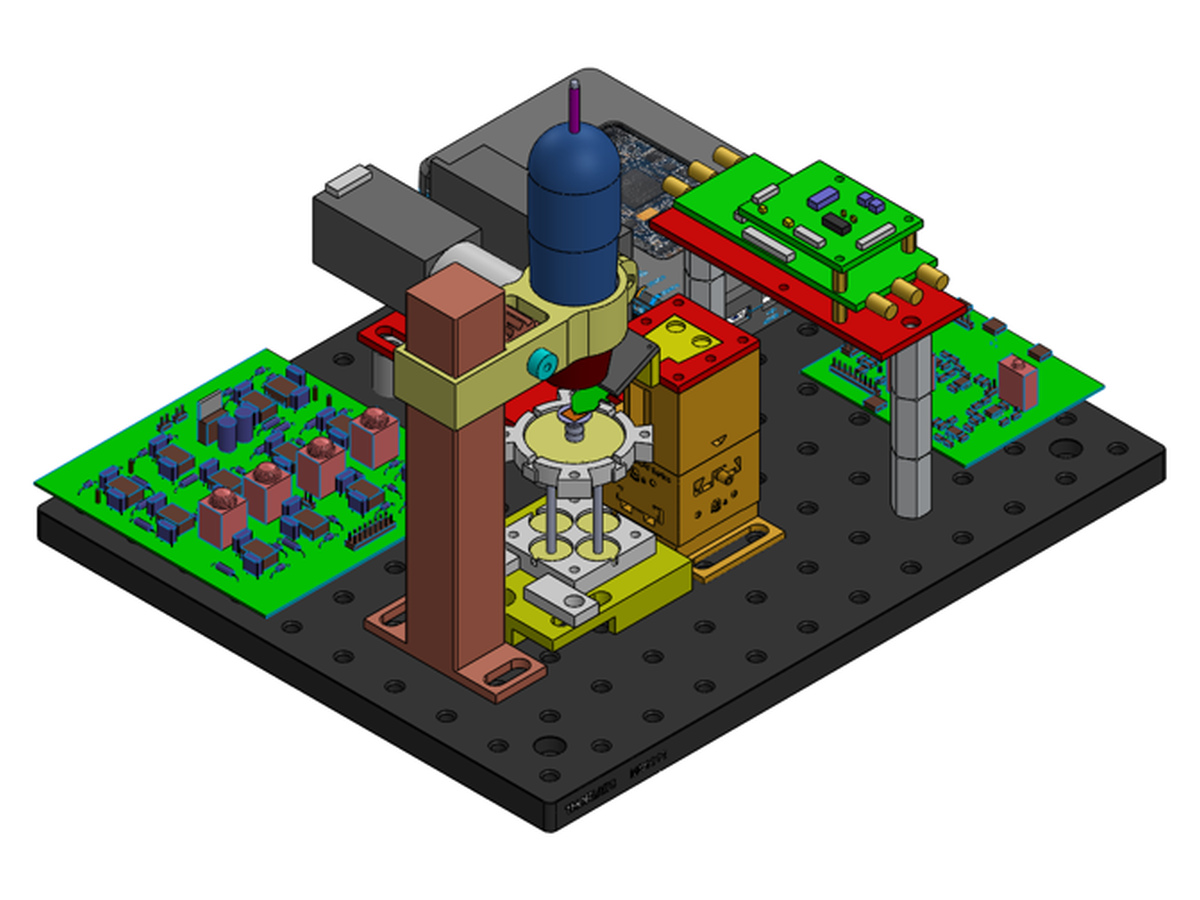
- Precision Mechatronics: Active-probe AFM for large-area inspection, fast imaging, and material characterization.
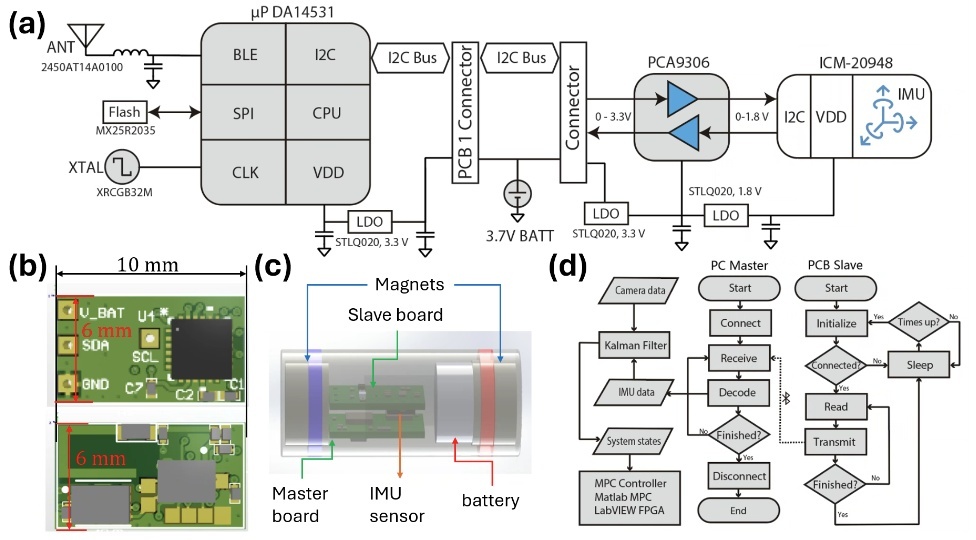
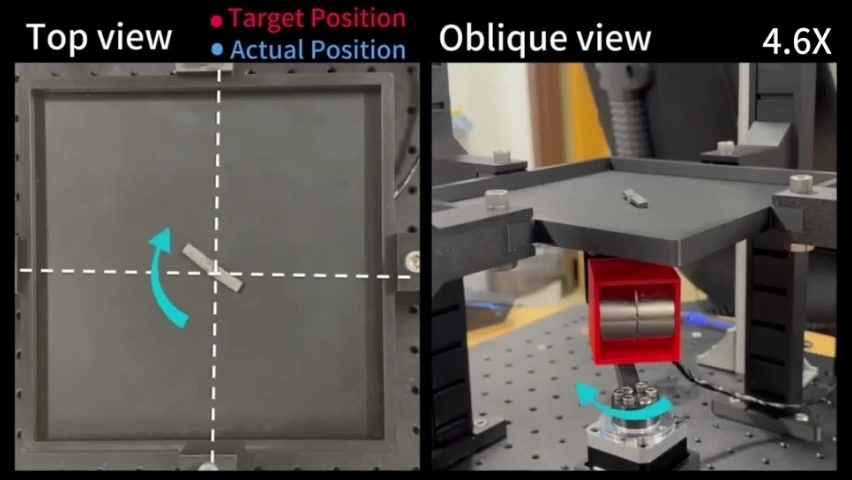
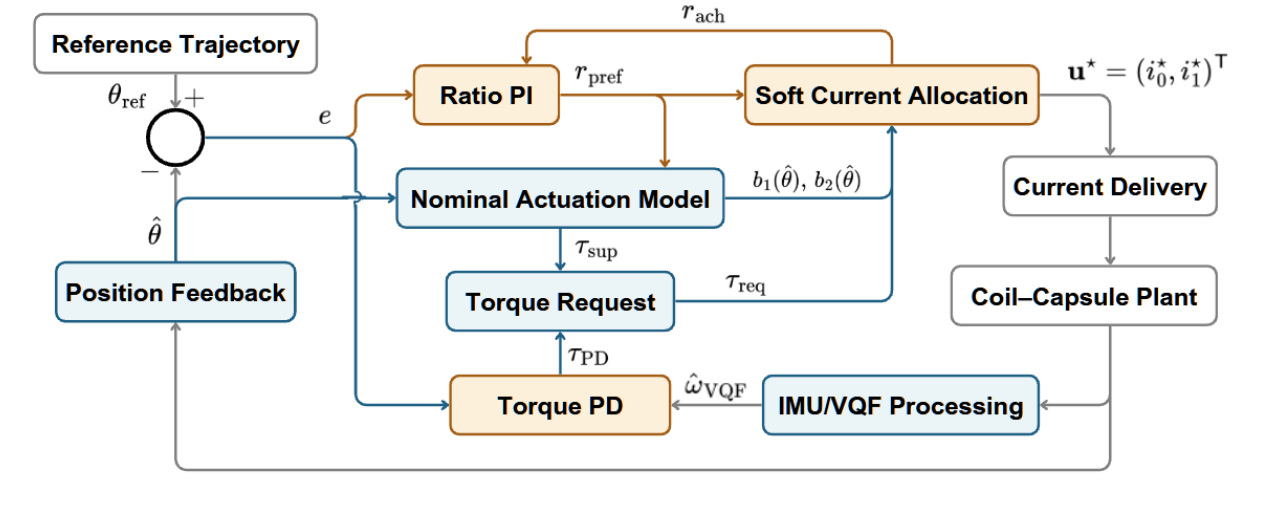
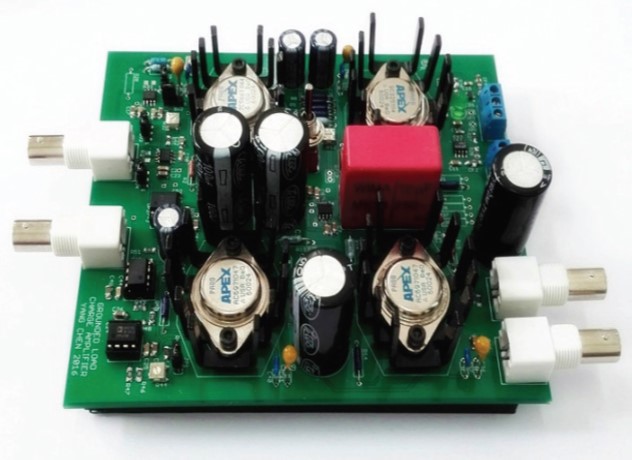
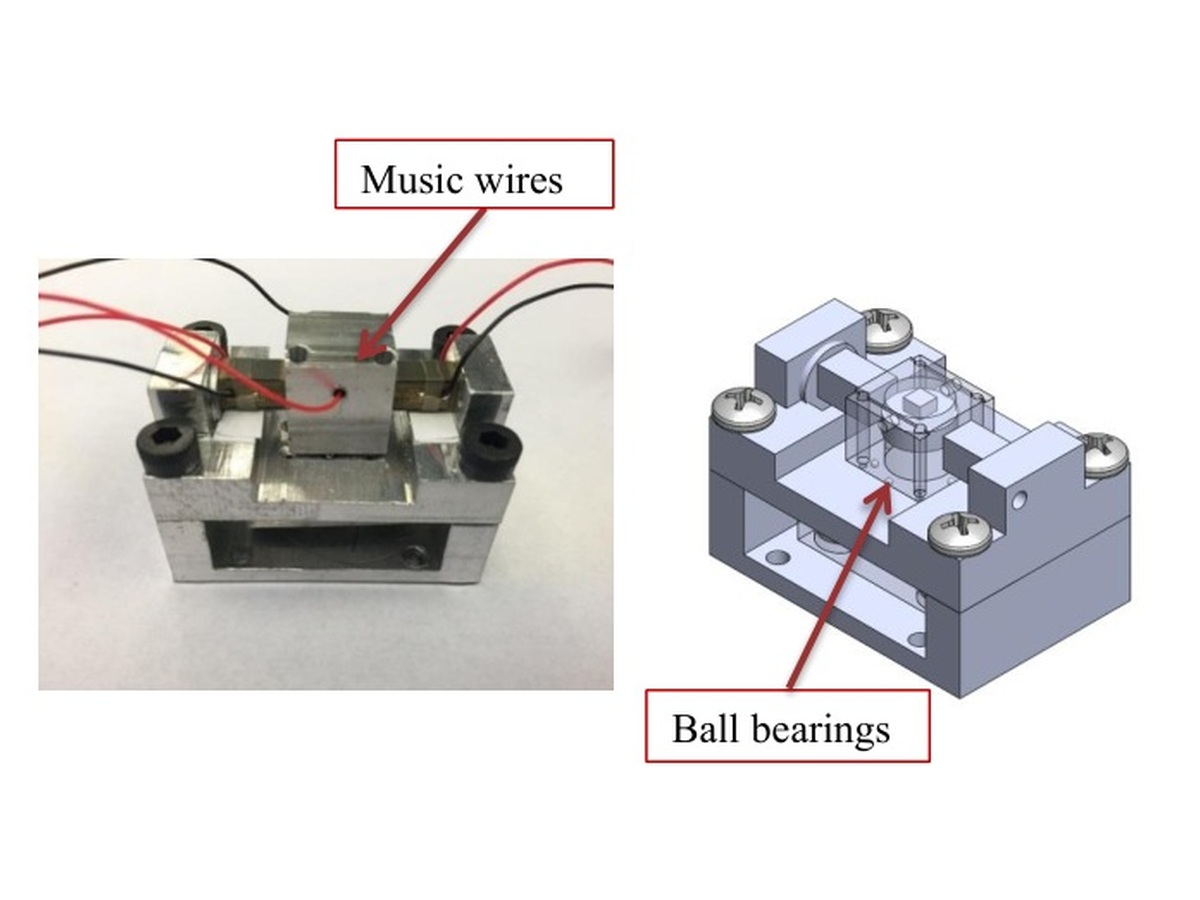
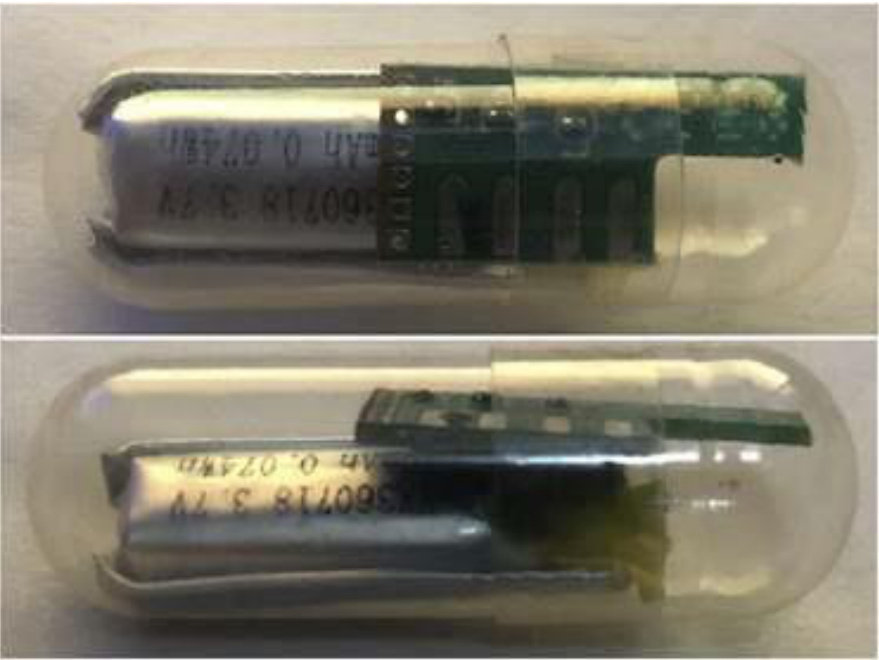
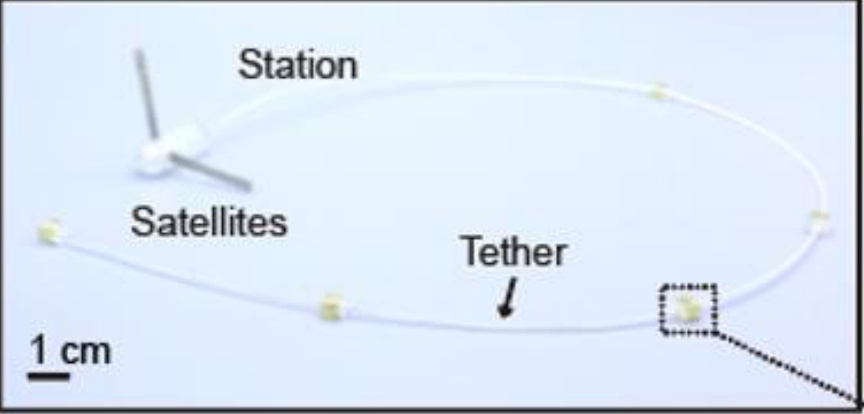
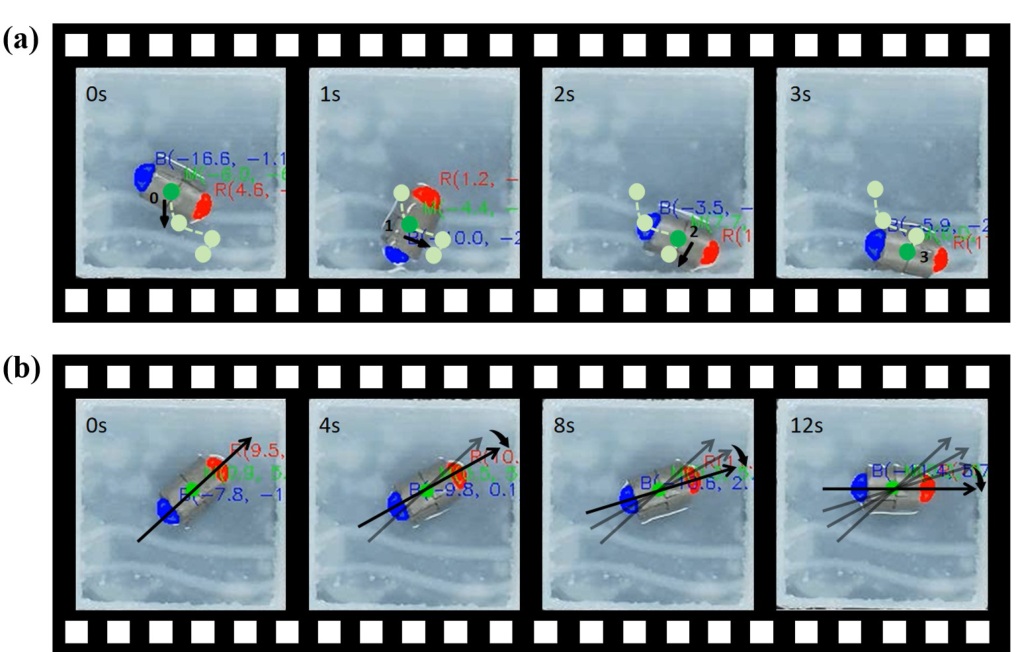
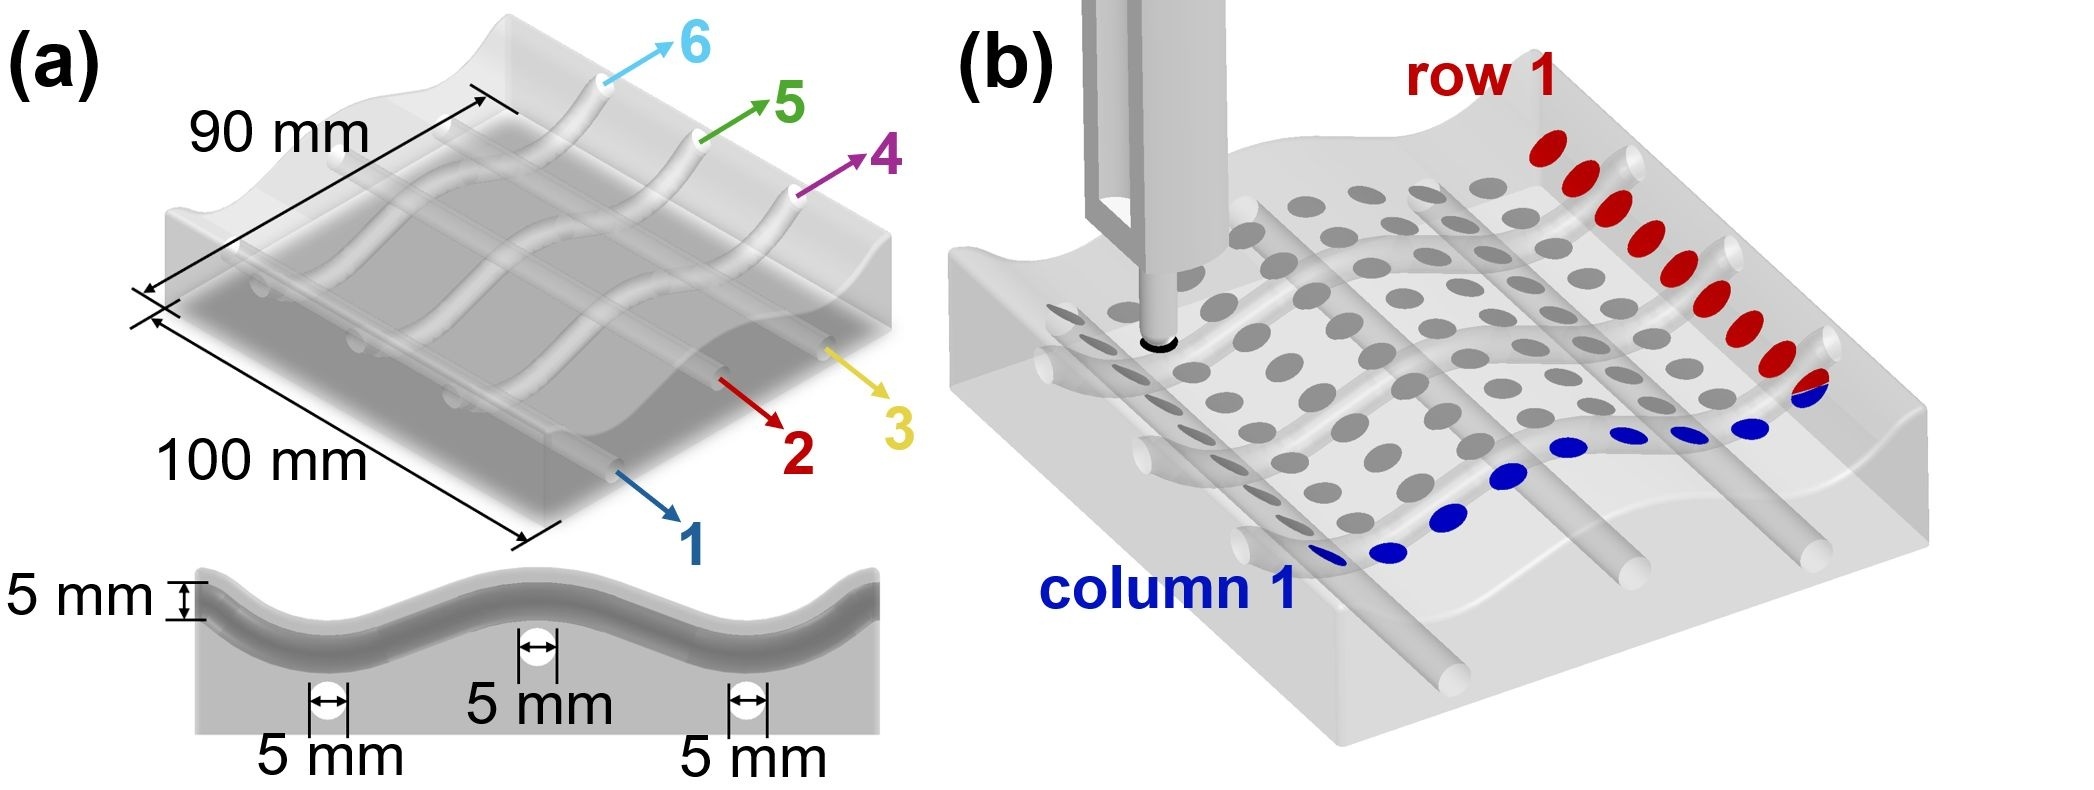
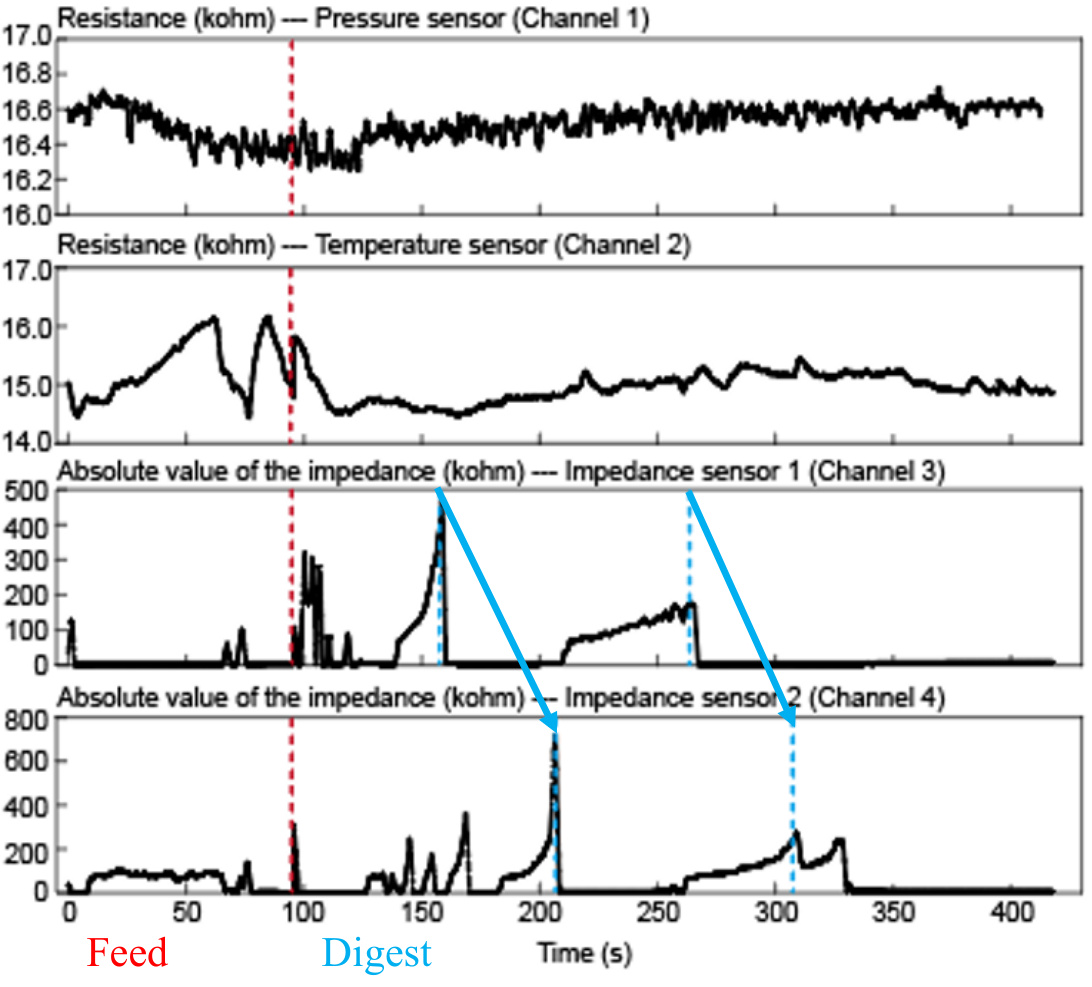
- Biomechatronics: Magnetic actuation, miniature sensors, and compact models for capsule navigation and tissue interaction.
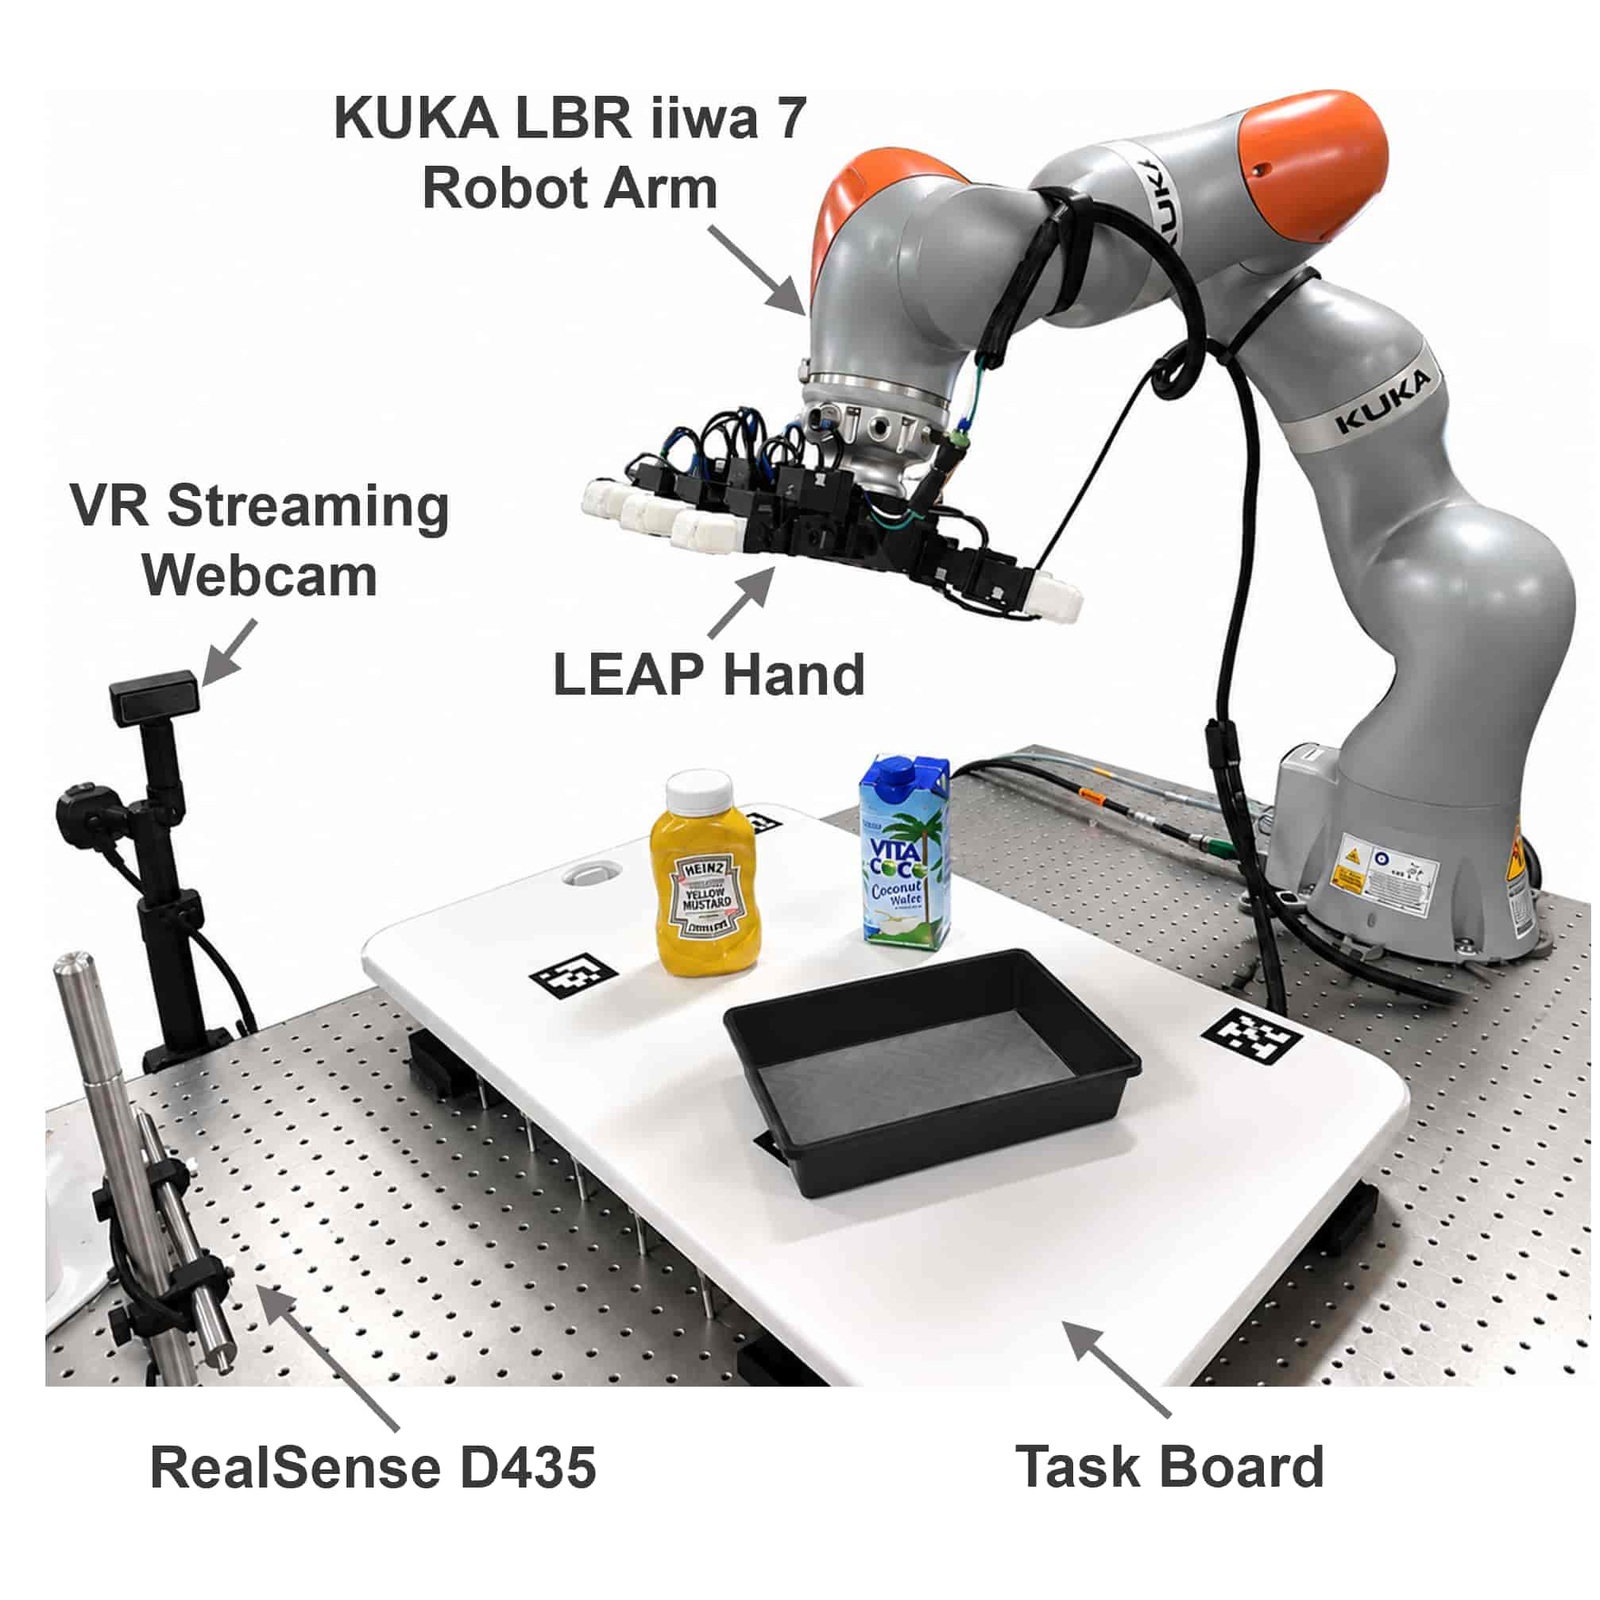
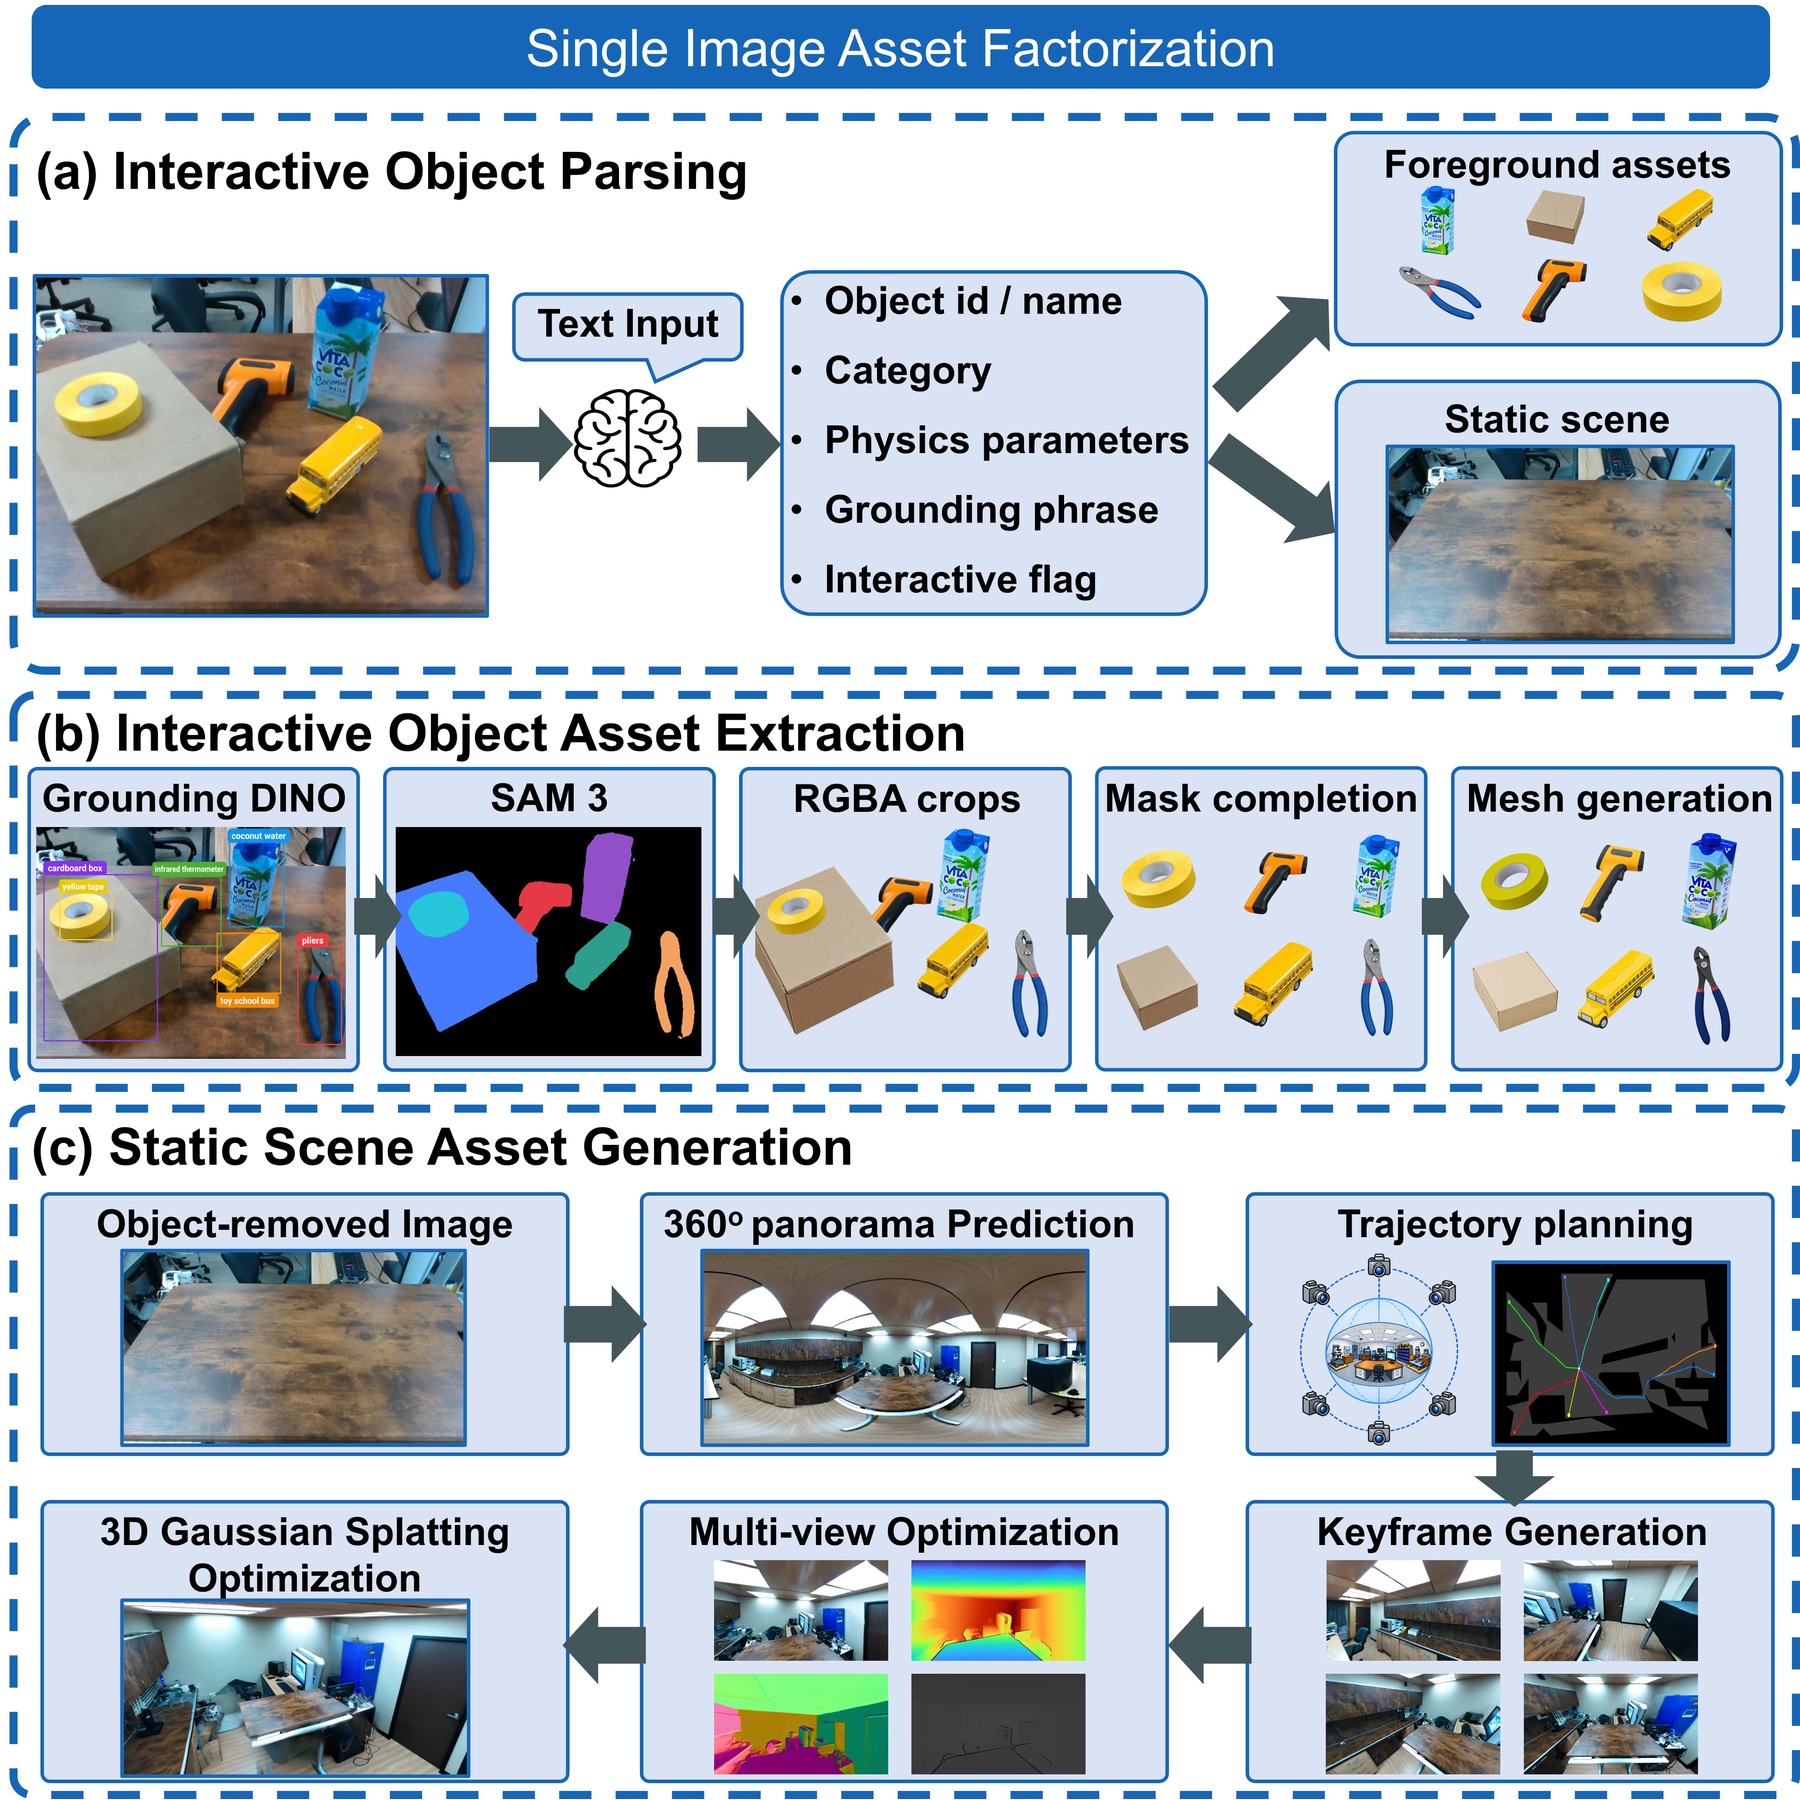
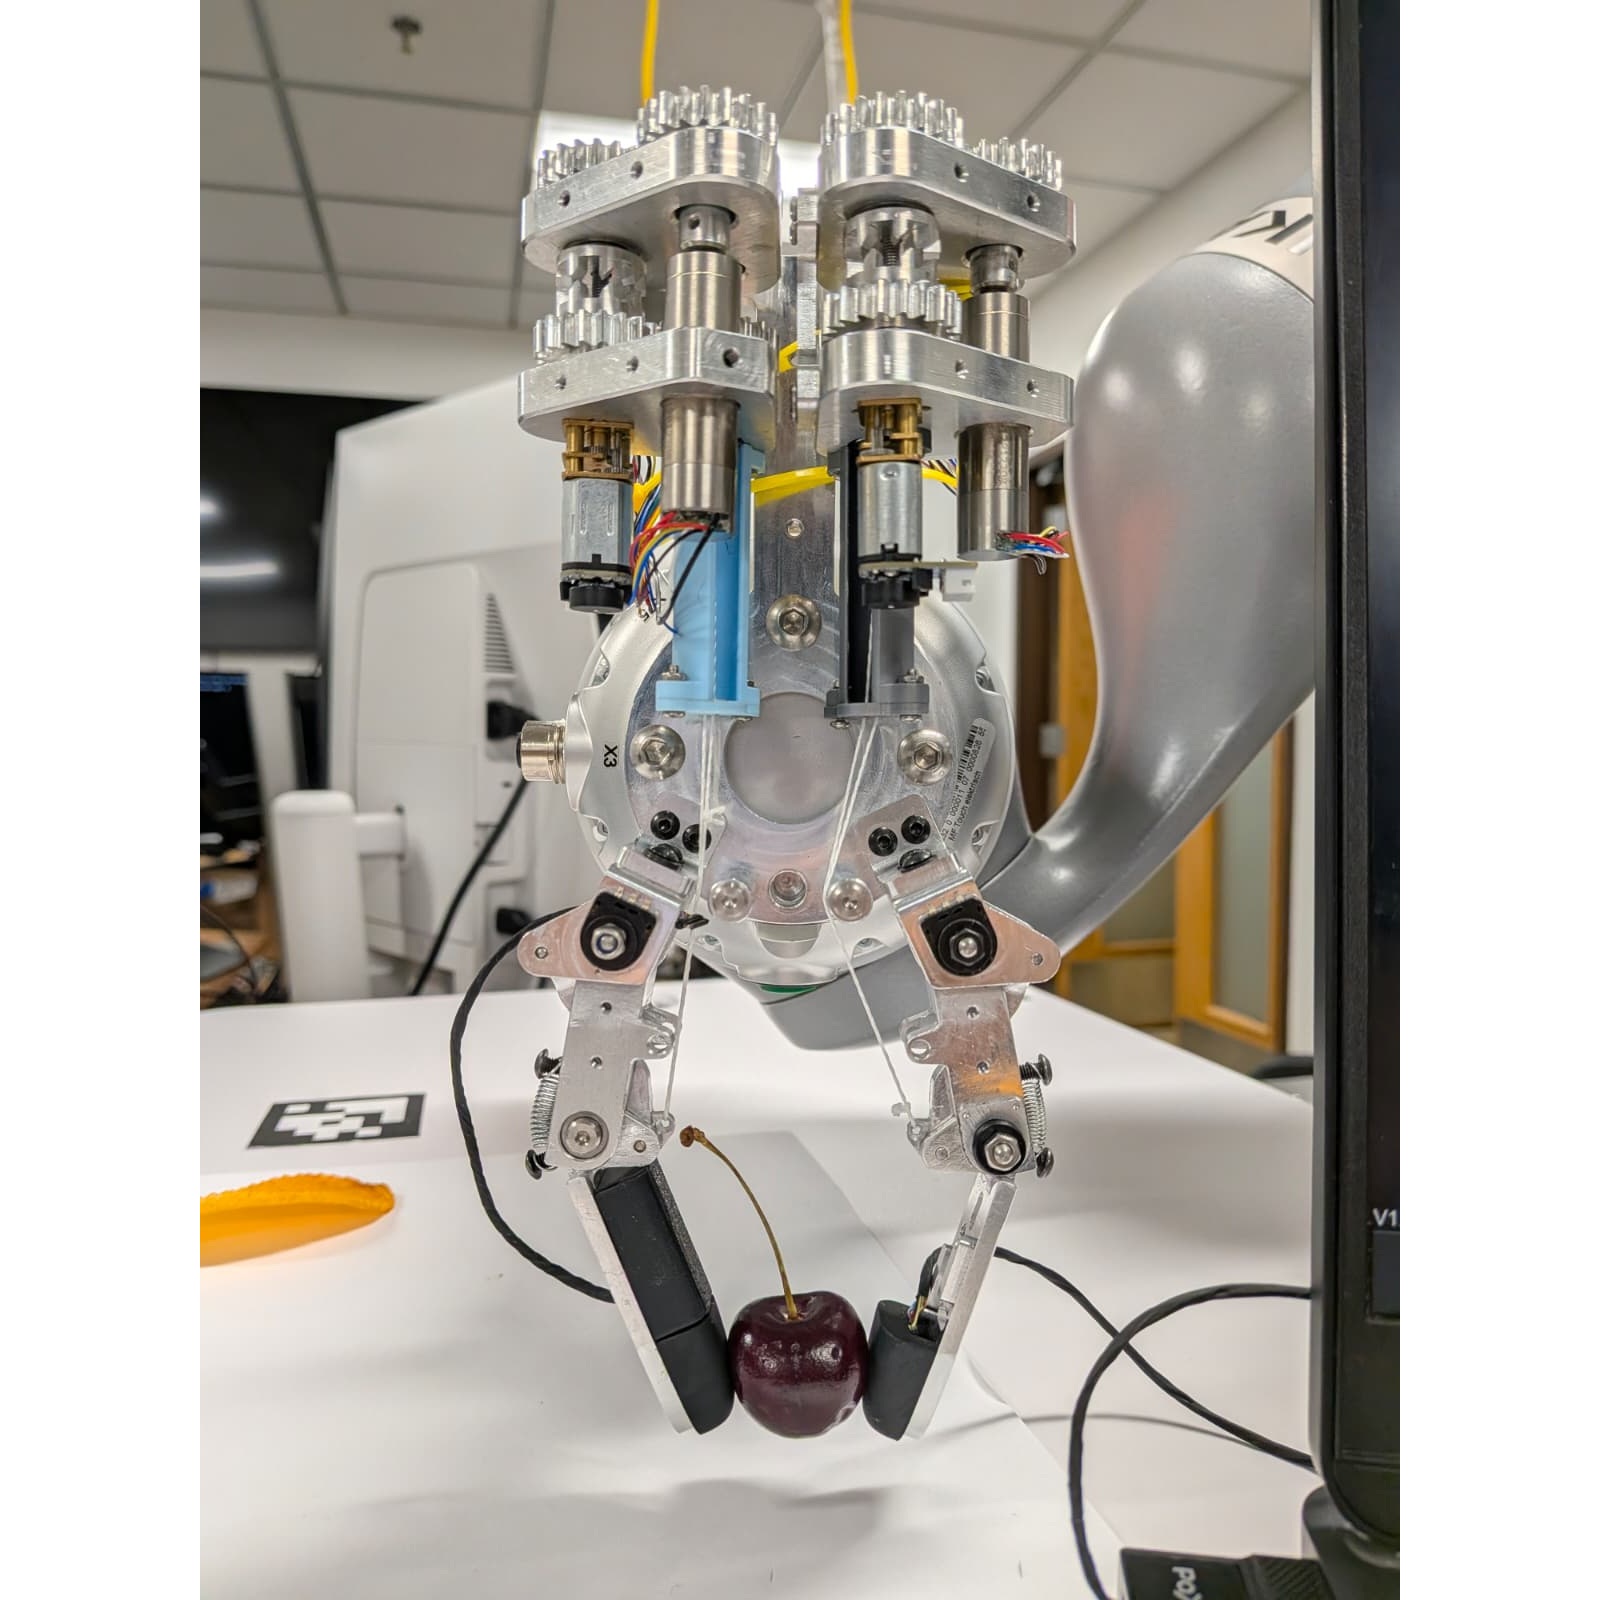
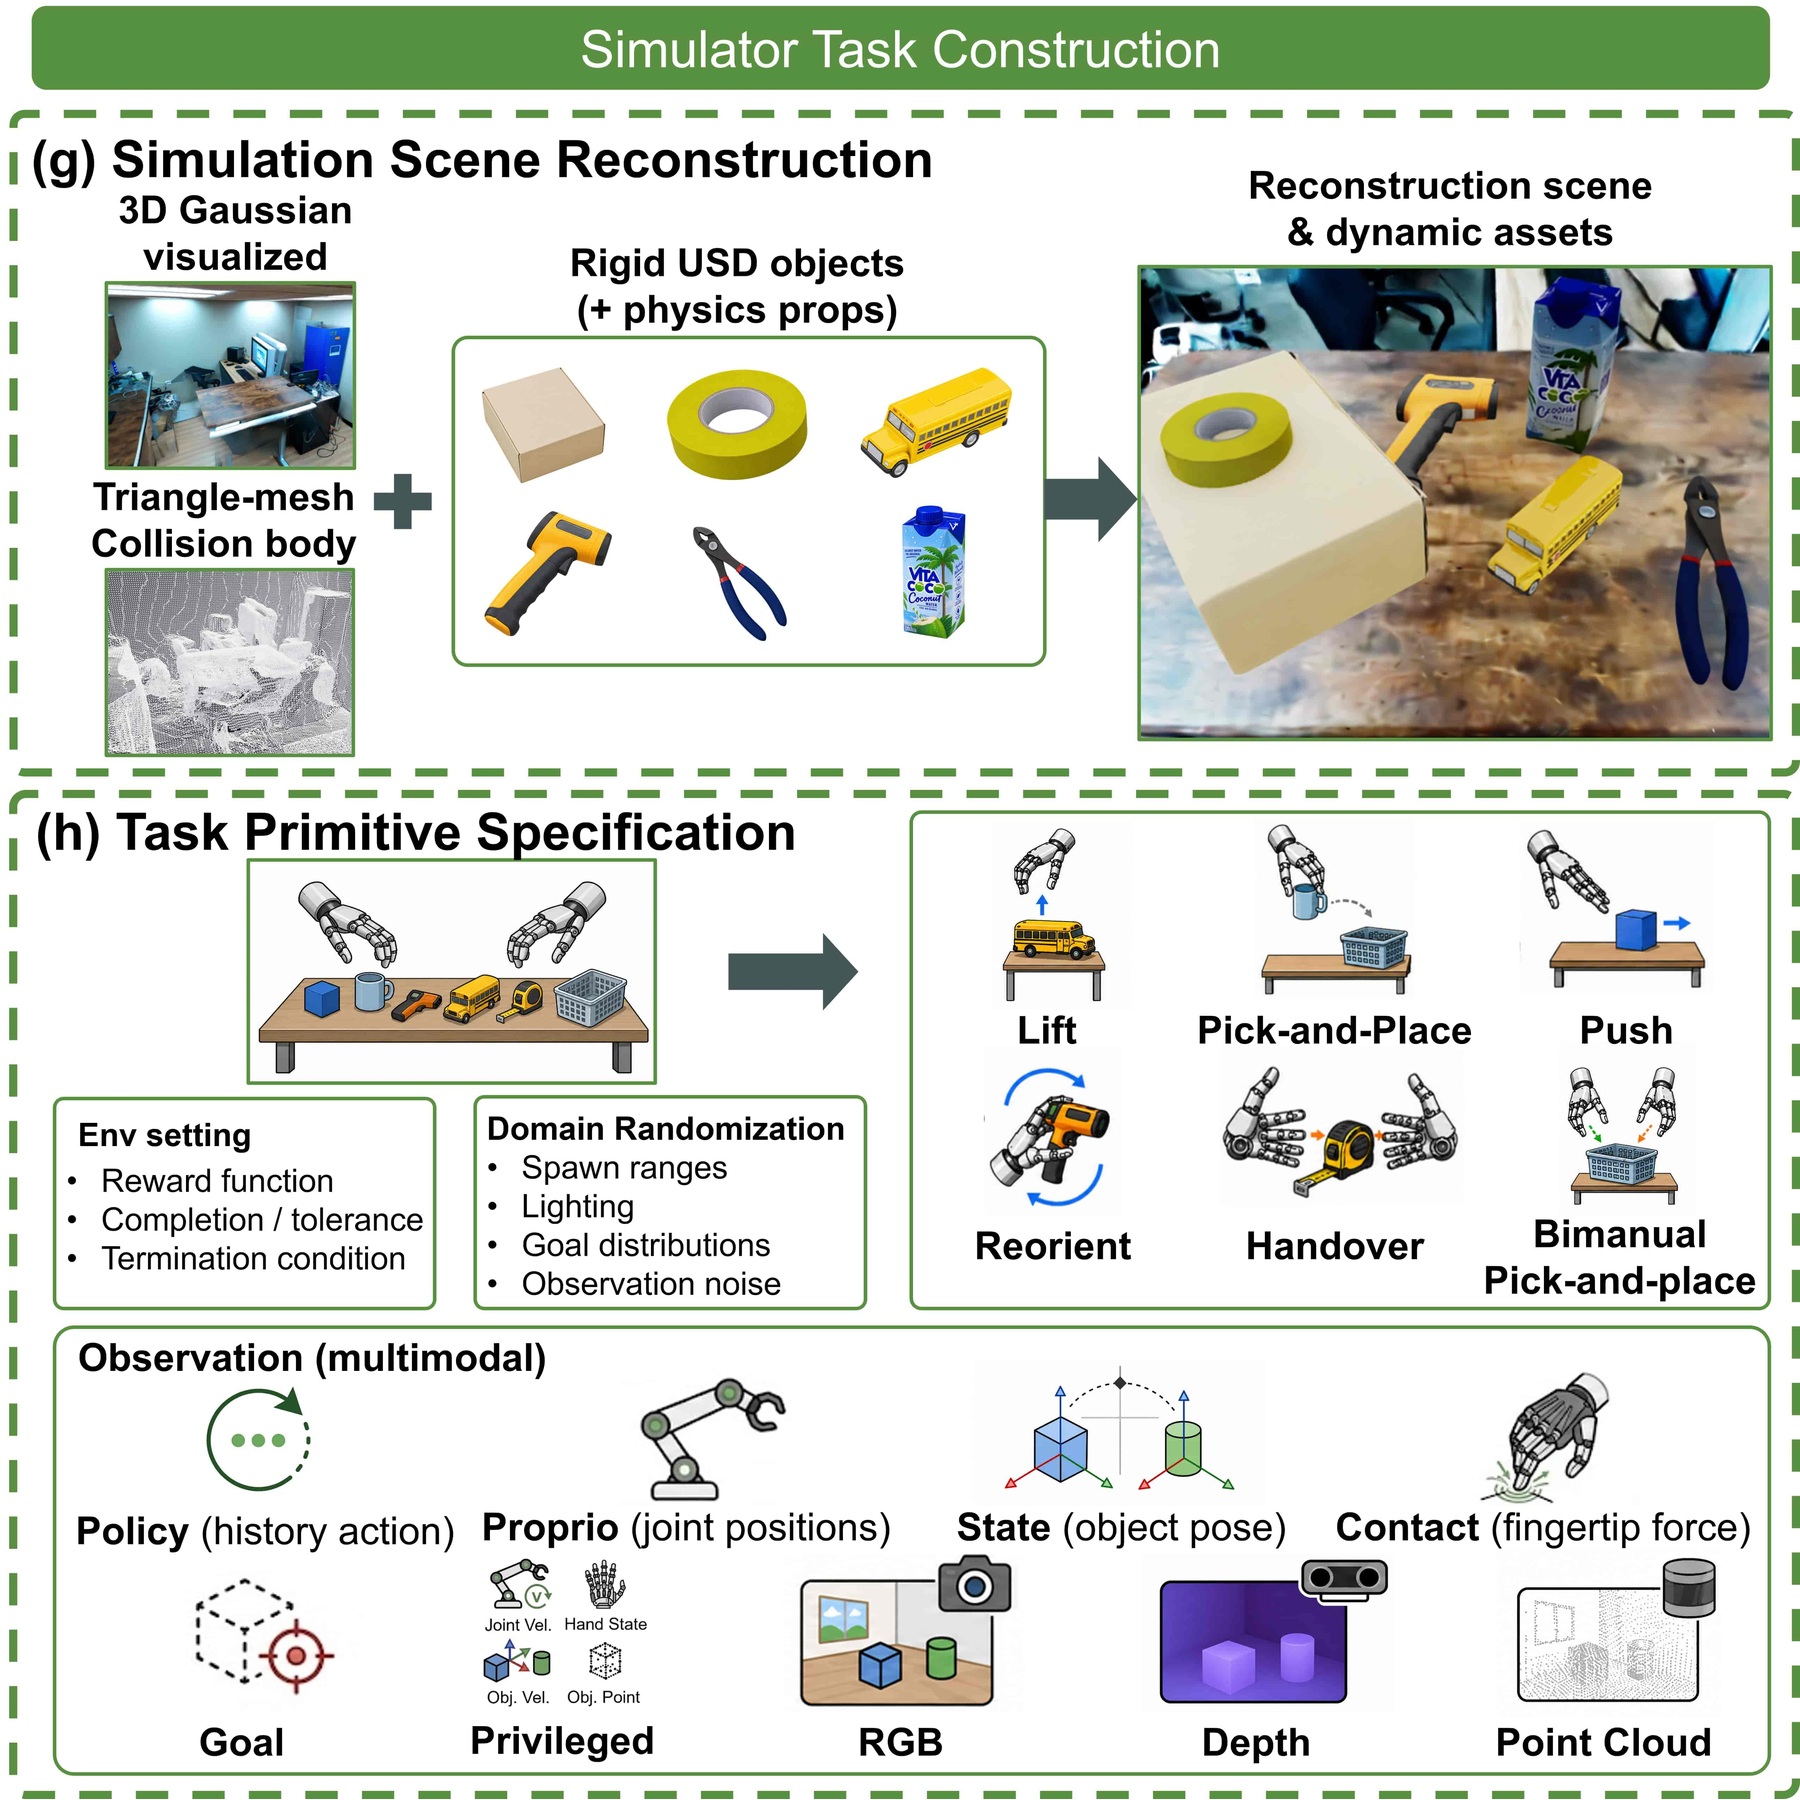
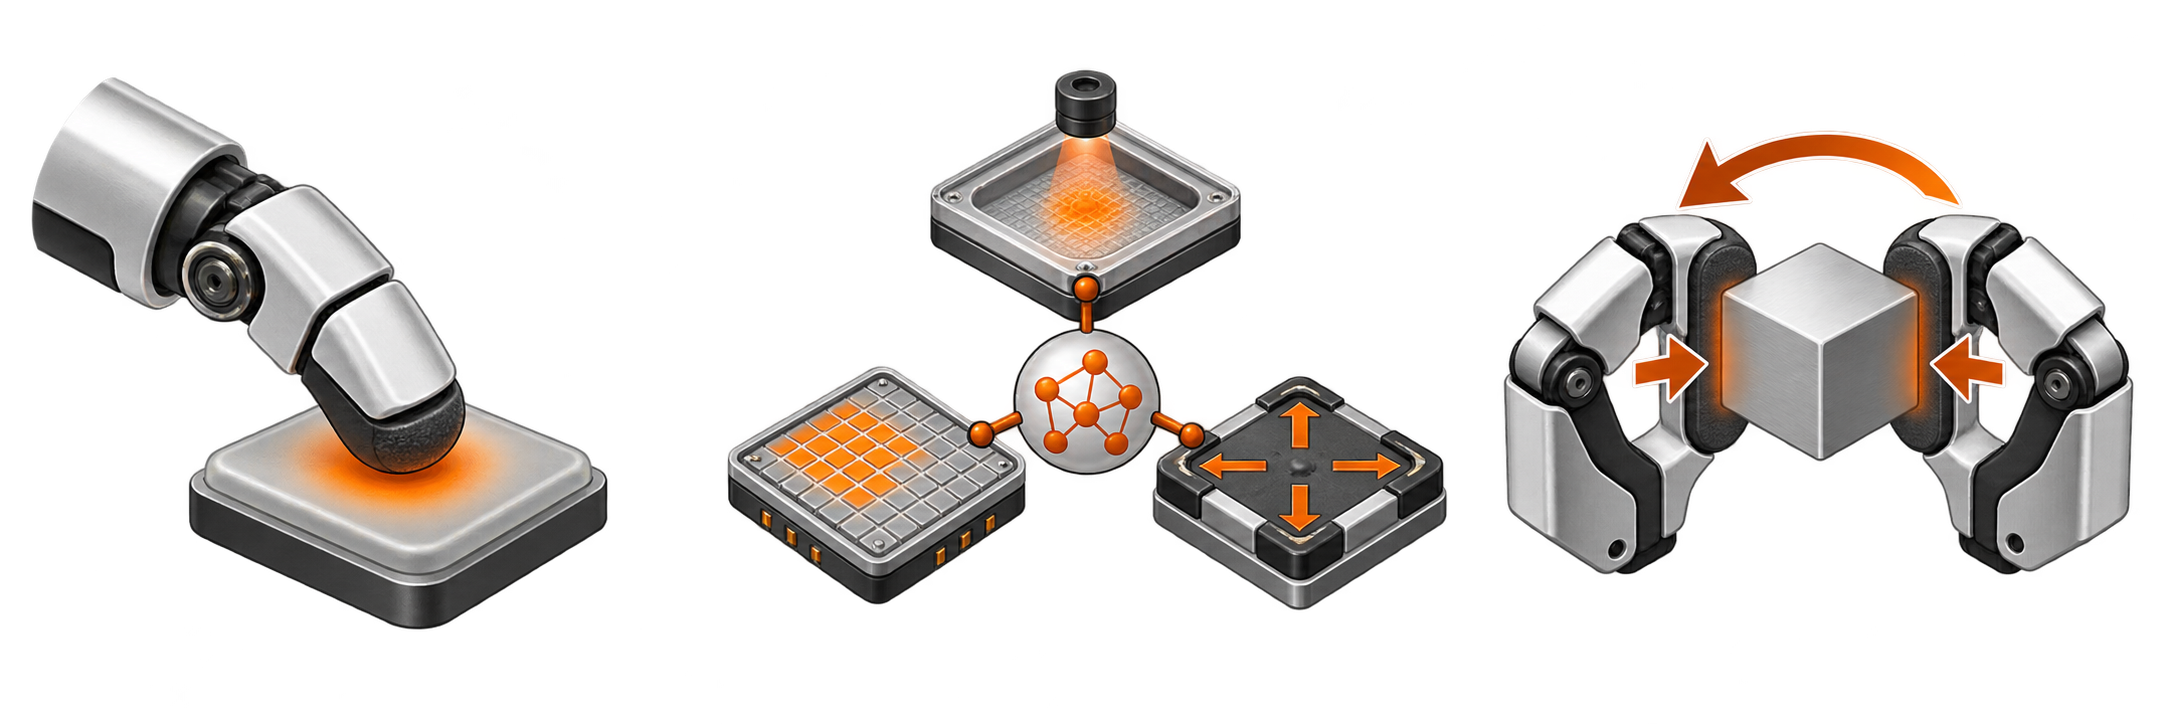
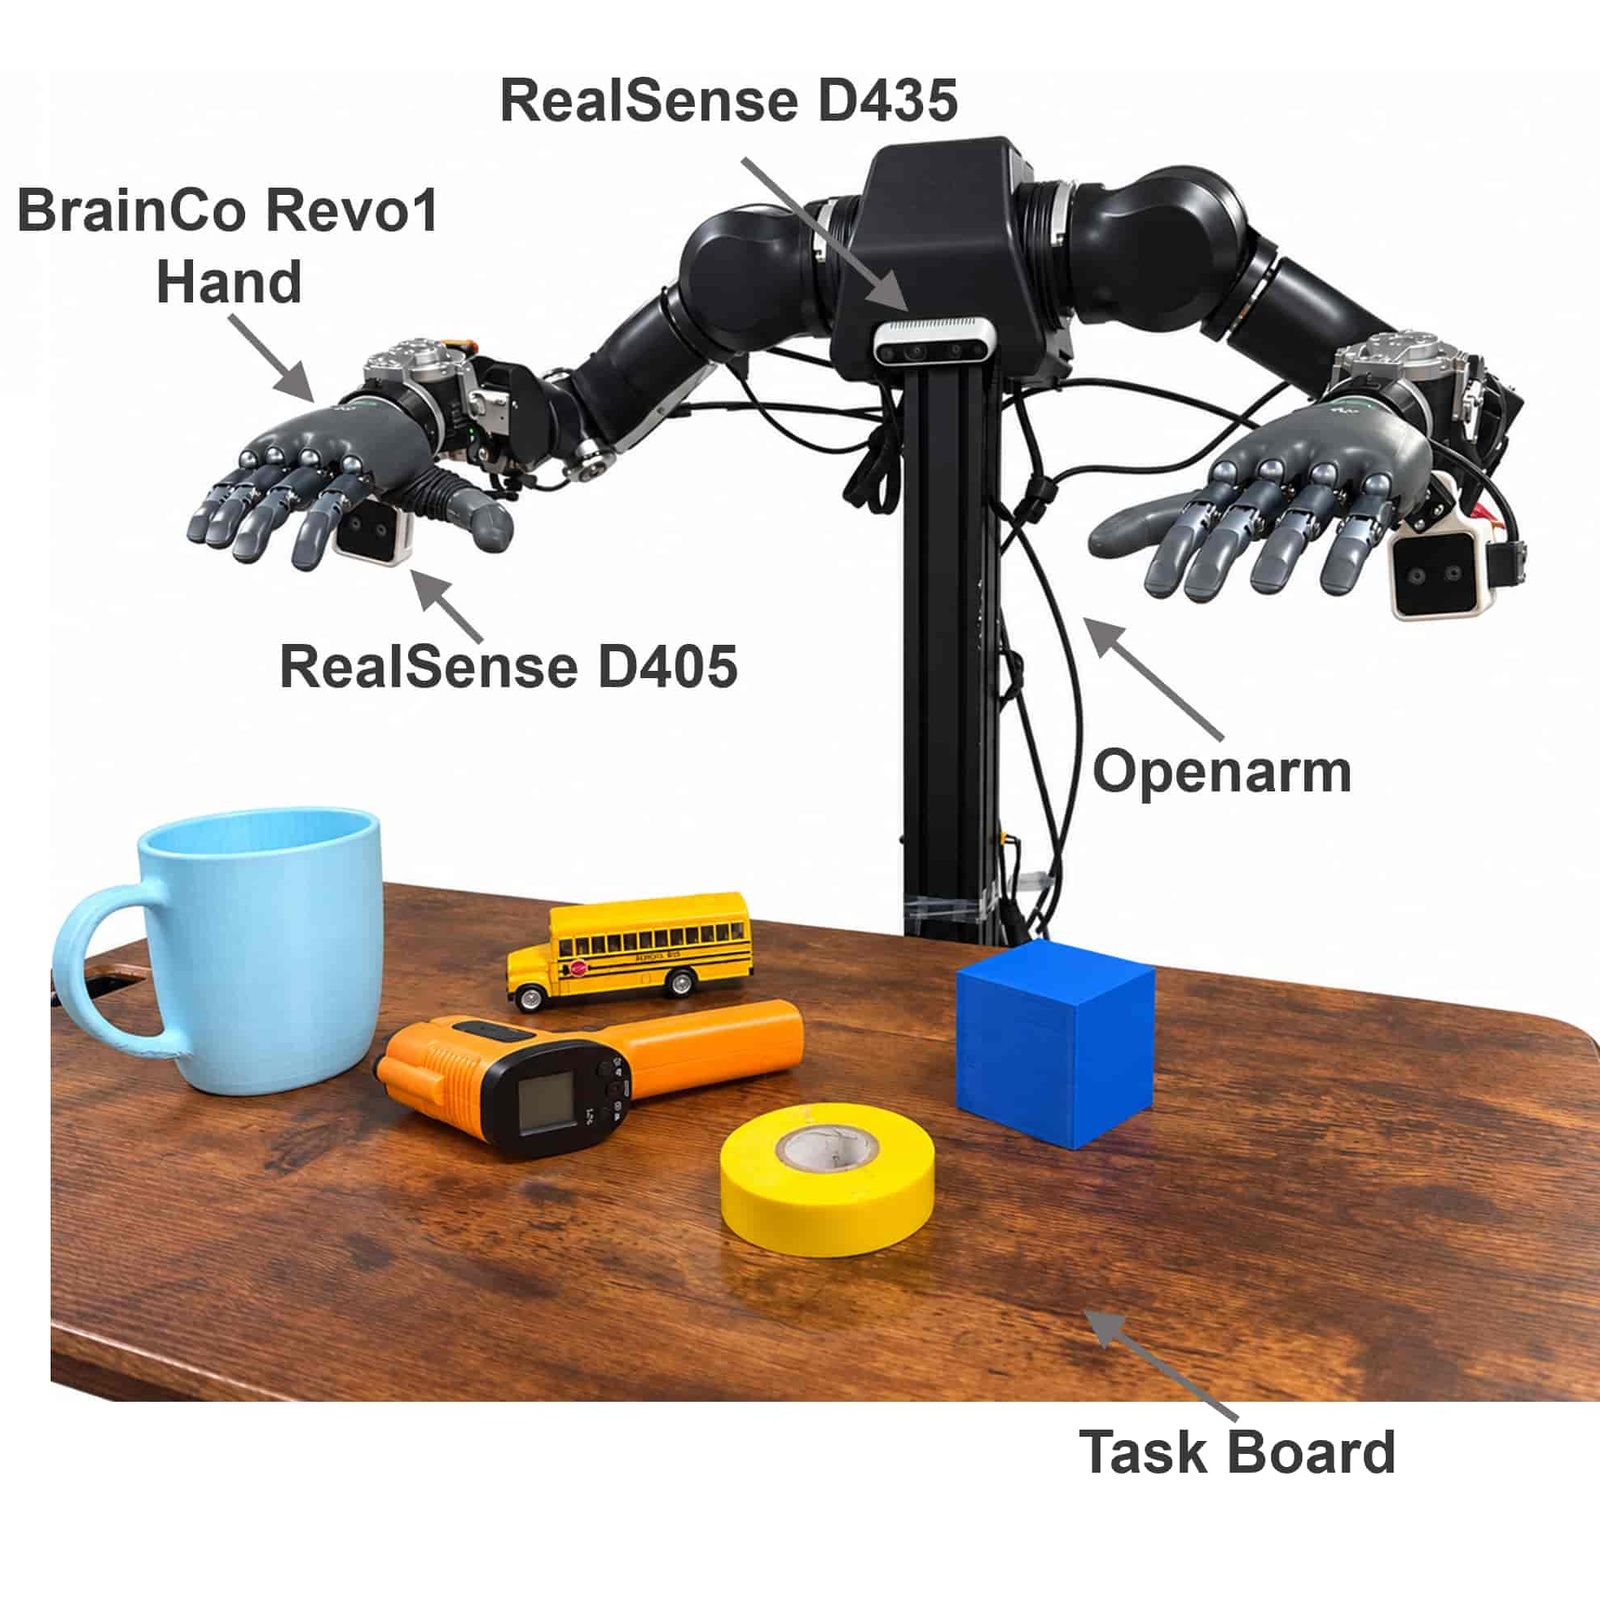
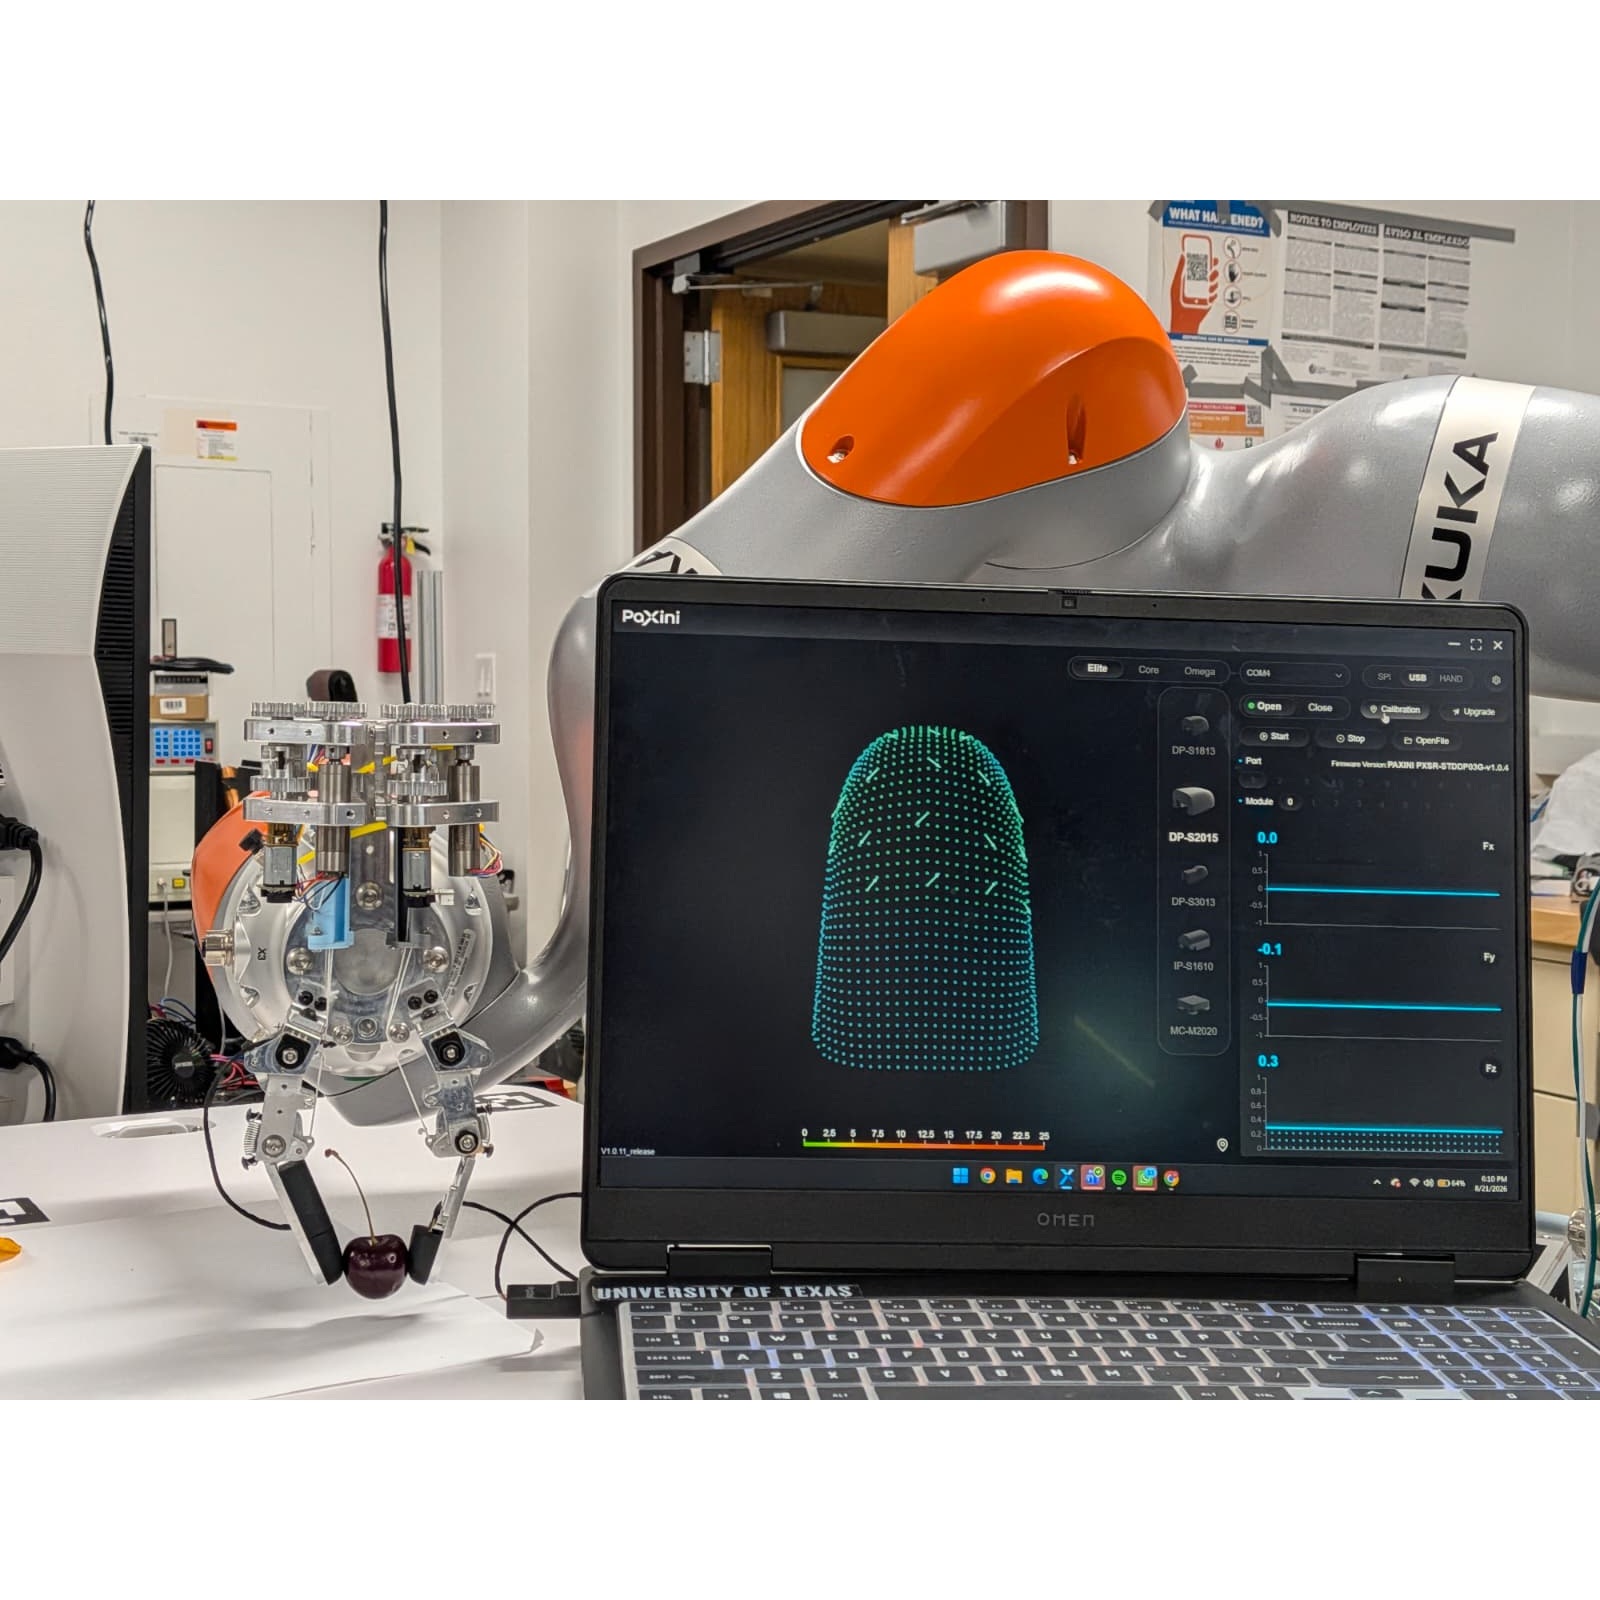
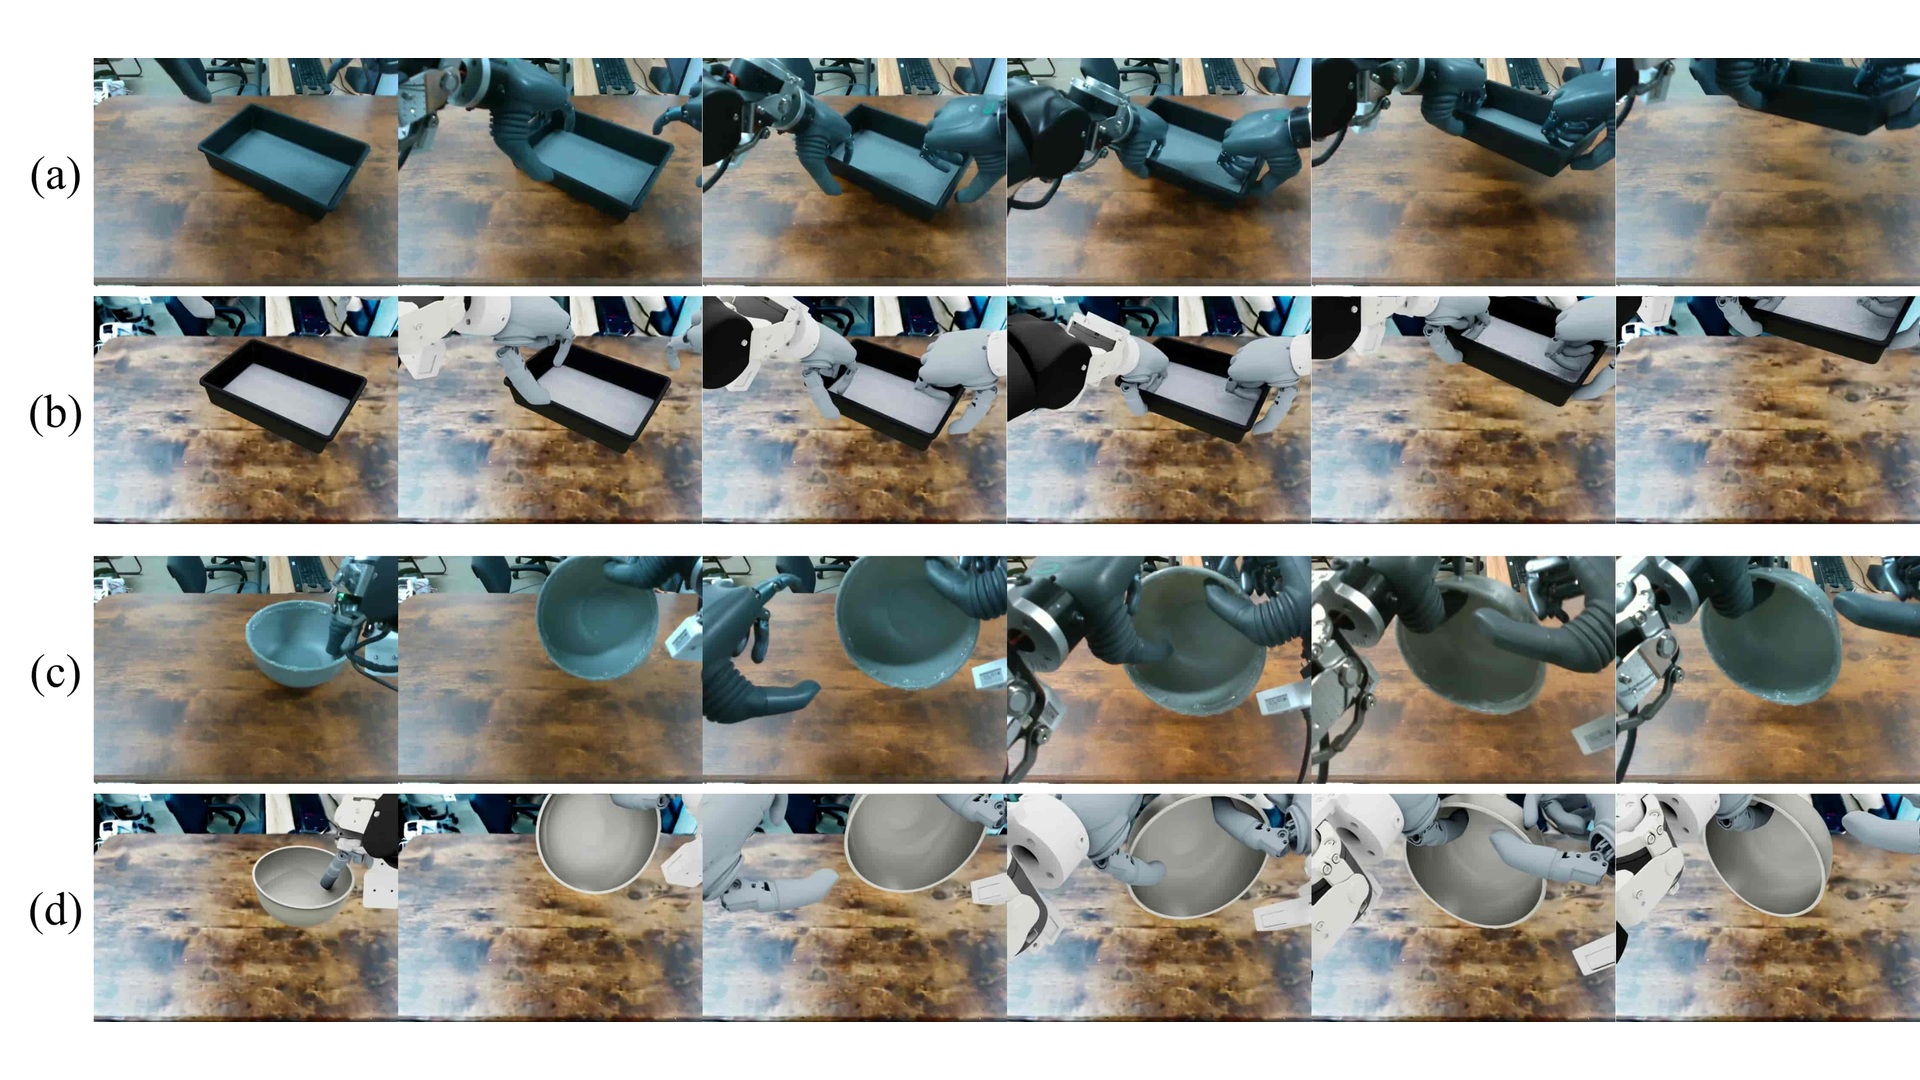
- Intelligent Mechatronics: Data-efficient learning, tactile sensing, and actuation design for dexterous robot manipulation.
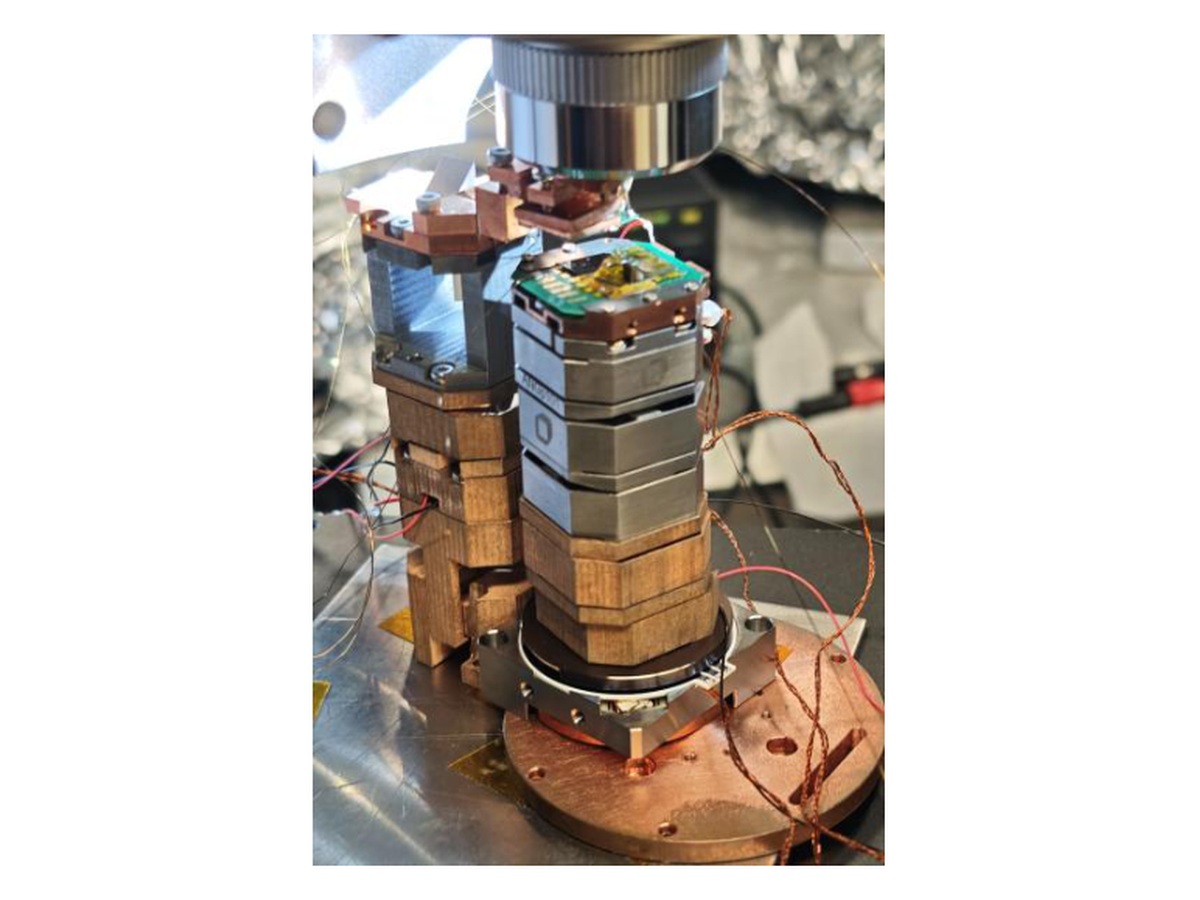
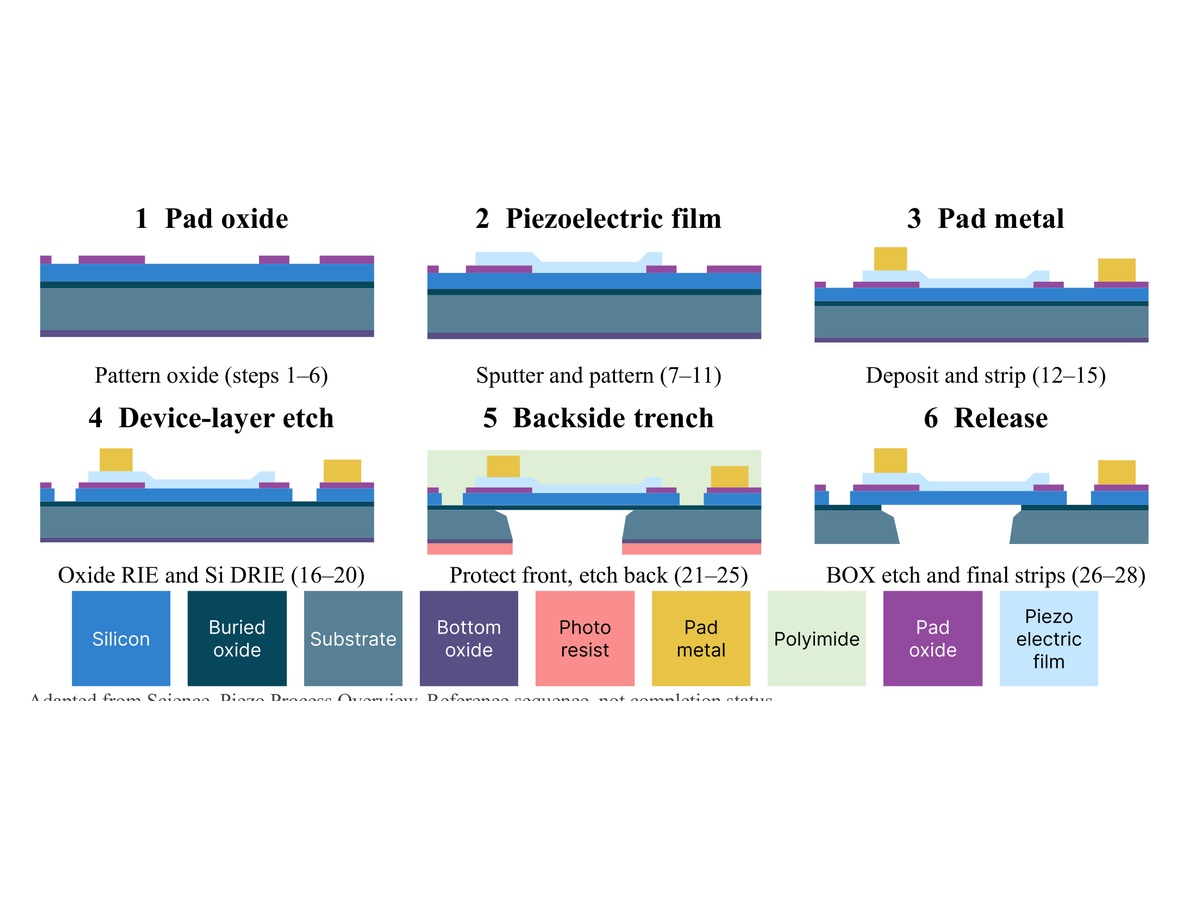
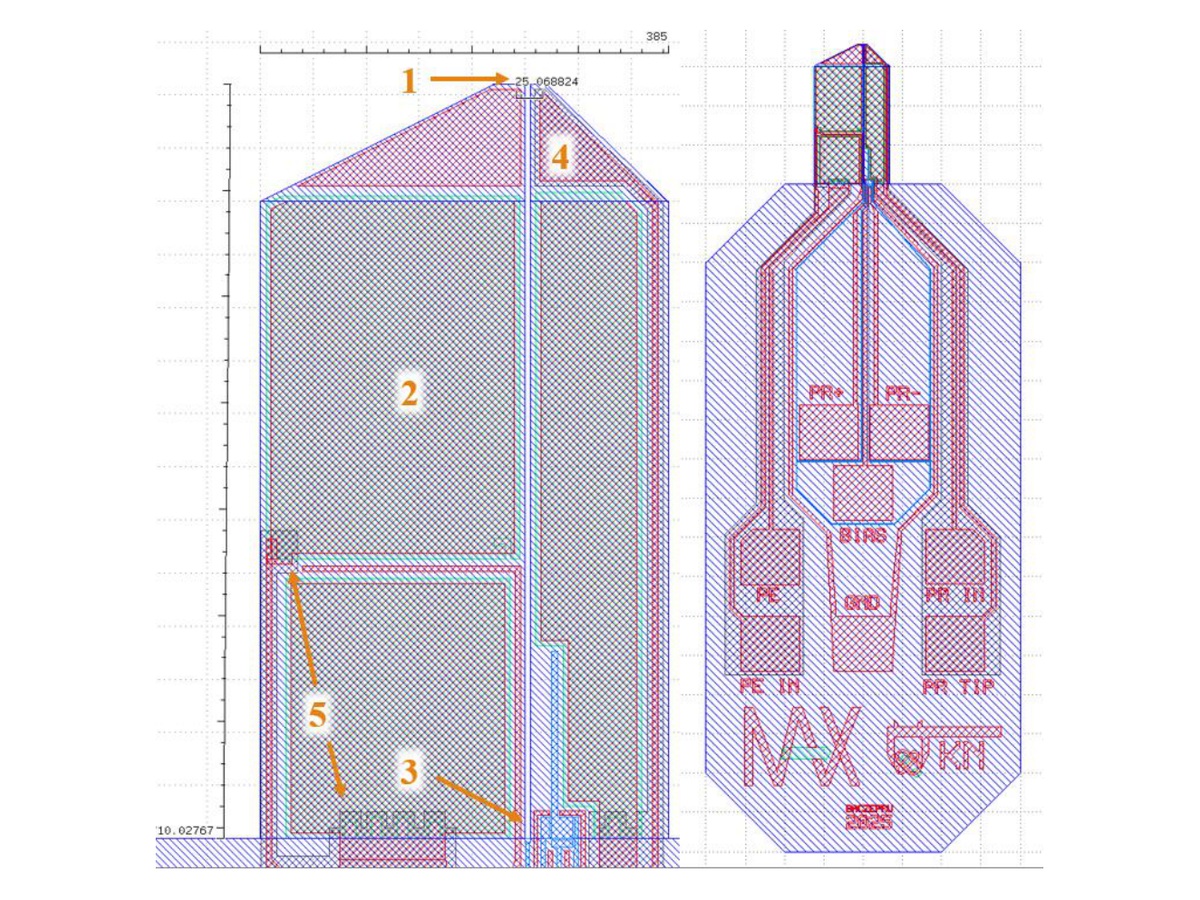
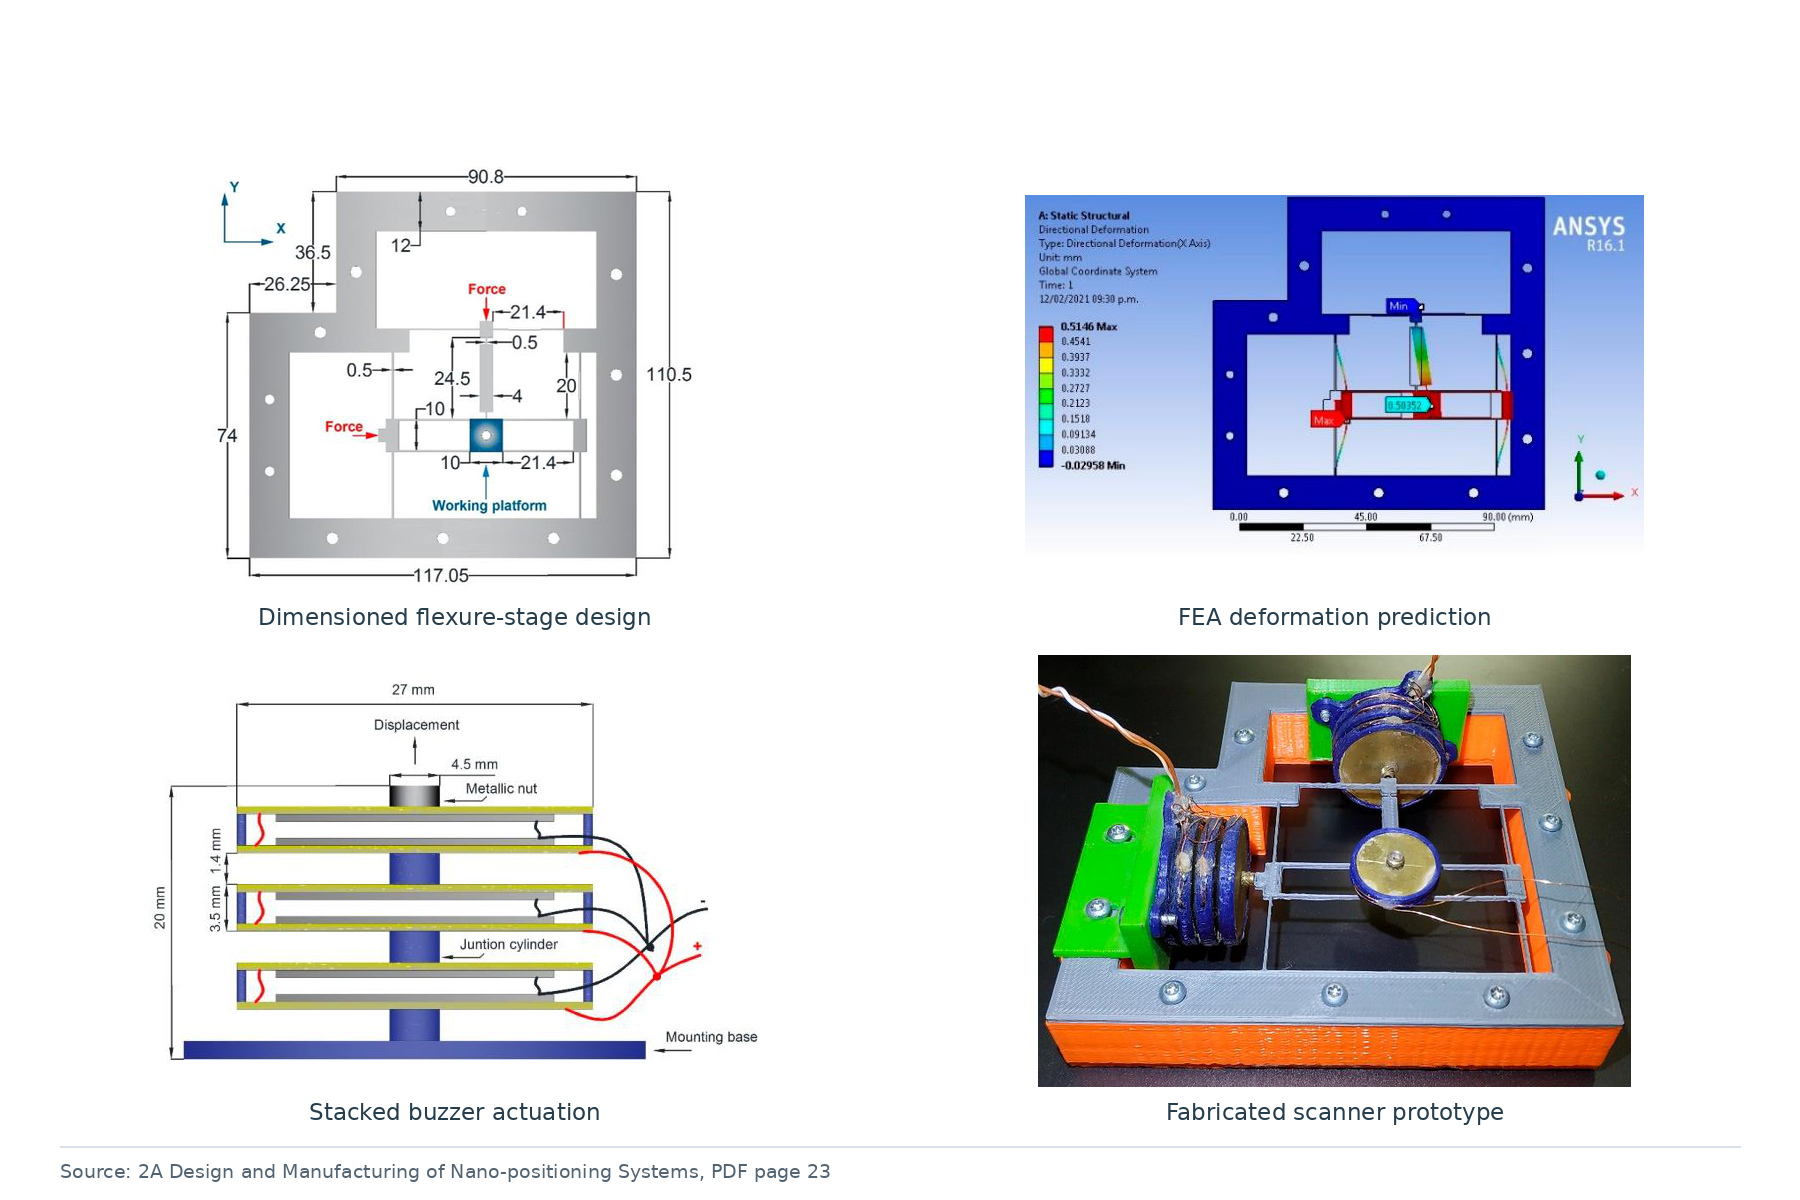
Prior research. Our foundation spans high-throughput and cryogenic microscopy, molecular nanoprinting, ingestible sensing and drug delivery, smart needles, predictive maintenance, vibration suppression, motor control, piezoelectric positioning, flexure design, digital twins, symbolic regression, MEMS transducers, and magnetic robot navigation.
Key Techniques and Applications

Mechatronics

Intelligence

Nanorobotics

Instrumentation

Medication

Automation
Interaction Control Across Length Scales
We connect nanoscale contact in atomic force microscopy, micro- and mesoscale interactions in capsule robots, and human-scale contact in robotic manipulation. Across these systems, reduced-order and surrogate models combine physics with data-driven learning, on-demand sensor fusion resolves task-relevant uncertainty, and optimization allocates effort across multiple actuators within physical and resource limits.

Precision Mechatronics
Nanoscale contact · Atomic force microscopy

Biomechatronics
Micro- and mesoscale systems · Capsule robots

Intelligent Mechatronics
Human-scale tasks · Robot manipulation
Research Image Gallery
Explore the research areas: Precision Mechatronics · Biomechatronics · Intelligent Mechatronics
© MINIMAX Lab, Walker Department of Mechanical Engineering, The University of Texas at Austin. All rights reserved.